Related Experiment Video
Updated: Aug 2, 2025


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Event-Triggered Sliding Mode Neural Network Controller Design for Heterogeneous Multi-Agent Systems
Xinhai Shen1, Jinfeng Gao1, Peter X Liu2
1School of Information Science and Engineering, Zhejiang Sci-Tech University, Hangzhou 310018, China.

Abstract:
A class of heterogeneous second-order multi-agent consensus problems is studied, in which an event-triggered method is used to improve the feasibility of the control protocol. The sliding mode control method is used to achieve the robustness of the system. A special type of general radial basis function neural network is applied to estimate the uncertainties. The event-triggered mechanism is introduced to reduce the update frequency of the controller and the communication frequency among the agents. Zeno behavior is avoided by ensuring a lower bound between two adjacent trigger instants. Finally, the simulation results are provided to demonstrate that the time evolution of consensus errors eventually approaches zero. The consensus of multi-agent systems is achieved.

Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
Masking and Demasking Agents
There are many masking agents, such as cyanide, fluoride, triethanolamine, thiourea, and 2,3-bis(sulfanyl)propan-1-ol (formerly 2,3-dimercapto-1-propanol), with the masking agent chosen based on...
 01:21
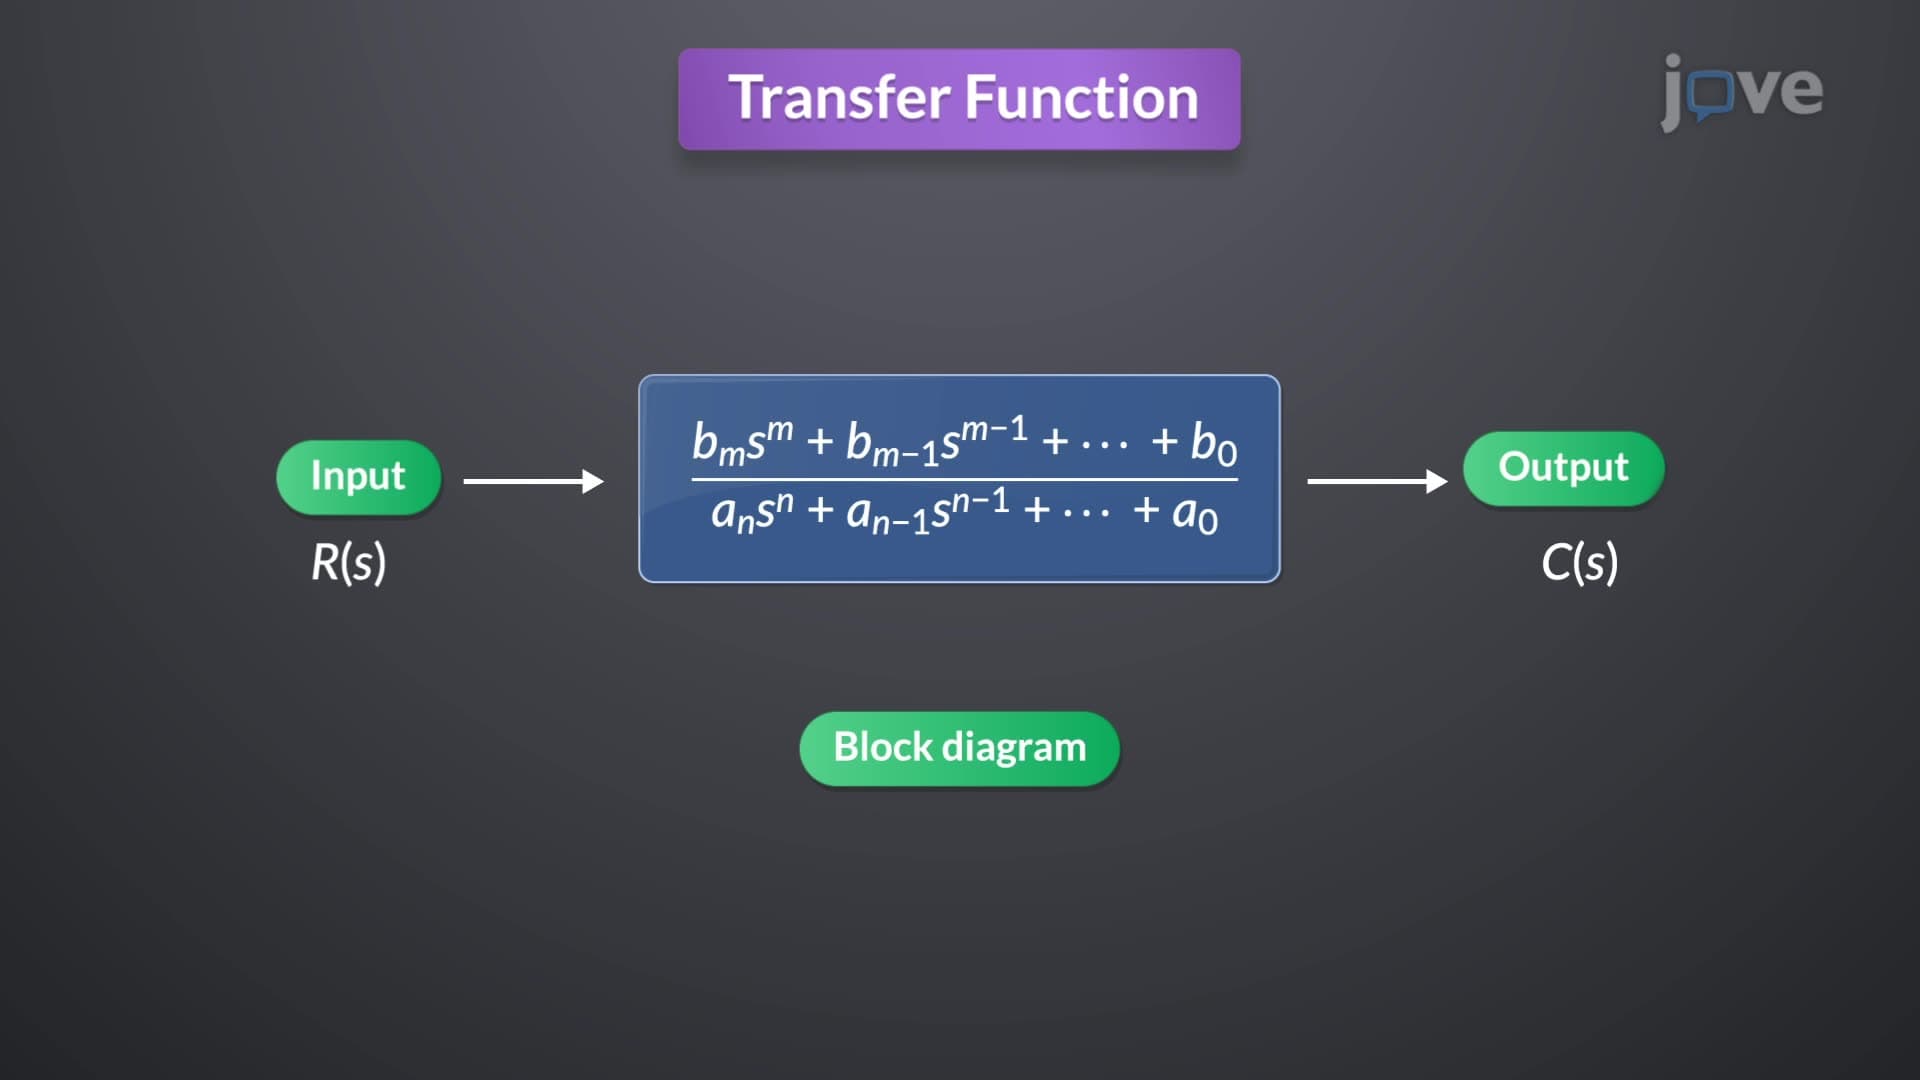
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...