Related Experiment Video
Updated: Aug 2, 2025
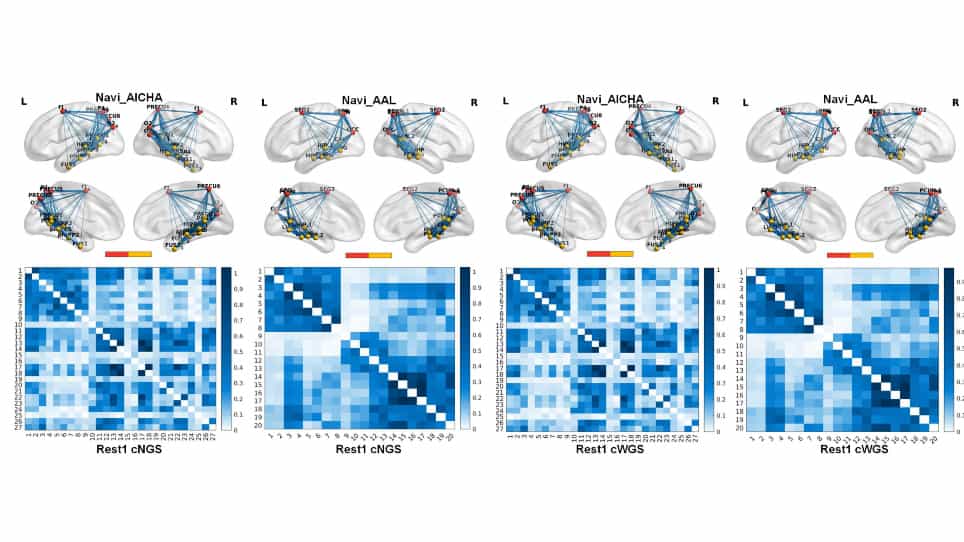

Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Navigation with Polytopes: A Toolbox for Optimal Path Planning with Polytope Maps and B-spline Curves
Ngoc Thinh Nguyen1, Pranav Tej Gangavarapu1, Niklas Fin Kompe1
1Institute for Robotics and Cognitive Systems, University of Lübeck, 23562 Lübeck, Germany.

Abstract:
To deal with the problem of optimal path planning in 2D space, this paper introduces a new toolbox named "Navigation with Polytopes" and explains the algorithms behind it. The toolbox allows one to create a polytopic map from a standard grid map, search for an optimal corridor, and plan a safe B-spline reference path used for mobile robot navigation. Specifically, the B-spline path is converted into its equivalent Bézier representation via a novel calculation method in order to reduce the conservativeness of the constrained path planning problem. The conversion can handle the differences between the curve intervals and allows for efficient computation. Furthermore, two different constraint formulations used for enforcing a B-spline path to stay within the sequence of connected polytopes are proposed, one with a guaranteed solution. The toolbox was extensively validated through simulations and experiments.

Related Concept Videos
 01:24
Introduction to Vertical Curves
 01:19
Introduction to Horizontal Curves
 01:25
Design Example: Traverse Angle Computations
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:12
Adjusting a Traverse