Related Experiment Video
Updated: Aug 2, 2025

Investigating Pain-Related Avoidance Behavior using a Robotic Arm-Reaching Paradigm
Published on: October 3, 2020
Path Planning for Obstacle Avoidance of Robot Arm Based on Improved Potential Field Method
Xinkai Xia1,2, Tao Li3, Shengbo Sang1,4
1Shanxi Key Laboratory of Micro Nano Sensor & Artificial Intelligence Perception, College of Information and Computer, Taiyuan University of Technology, Taiyuan 030024, China.

Abstract:
In medical and surgical scenarios, the trajectory planning of a collaborative robot arm is a difficult problem. The artificial potential field (APF) algorithm is a classic method for robot trajectory planning, which has the characteristics of good real-time performance and low computing consumption. There are many variants of the APF algorithm, among which the most widely used variants is the velocity potential field (VPF) algorithm. However, the traditional VPF algorithm has inherent defects and problems, such as easily falling into local minimum, being unable to reach the target, poor dynamic obstacle avoidance ability, and safety and efficiency problems. Therefore, this work presents the improved velocity potential field (IVPF) algorithm, which considers direction factors, obstacle velocity factor, and tangential velocity. When encountering dynamic obstacles, the IVPF algorithm can avoid obstacles better to ensure the safety of both the human and robot arm. The IVPF algorithm also does not easily fall into a local problem when encountering different obstacles. The experiments informed the RRT* algorithm, VPF algorithm, and IVPF algorithm for comparison. Compared with the informed RRT* and VPF algorithm, the result of experiments indicate that the performances of the IVPF algorithm have significant improvements when dealing with different obstacles. The main aim of this paper is to provide a safe and efficient path planning algorithm for the robot arm in the medical field. The proposed algorithm can ensure the safety of both the human and the robot arm when the medical and surgical robot arm is working, and enables the robot arm to cope with emergencies and perform tasks better. The application of the proposed algorithm could make the collaborative robots work in a flexible and safe condition, which could open up new opportunities for the future development of medical and surgical scenarios.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
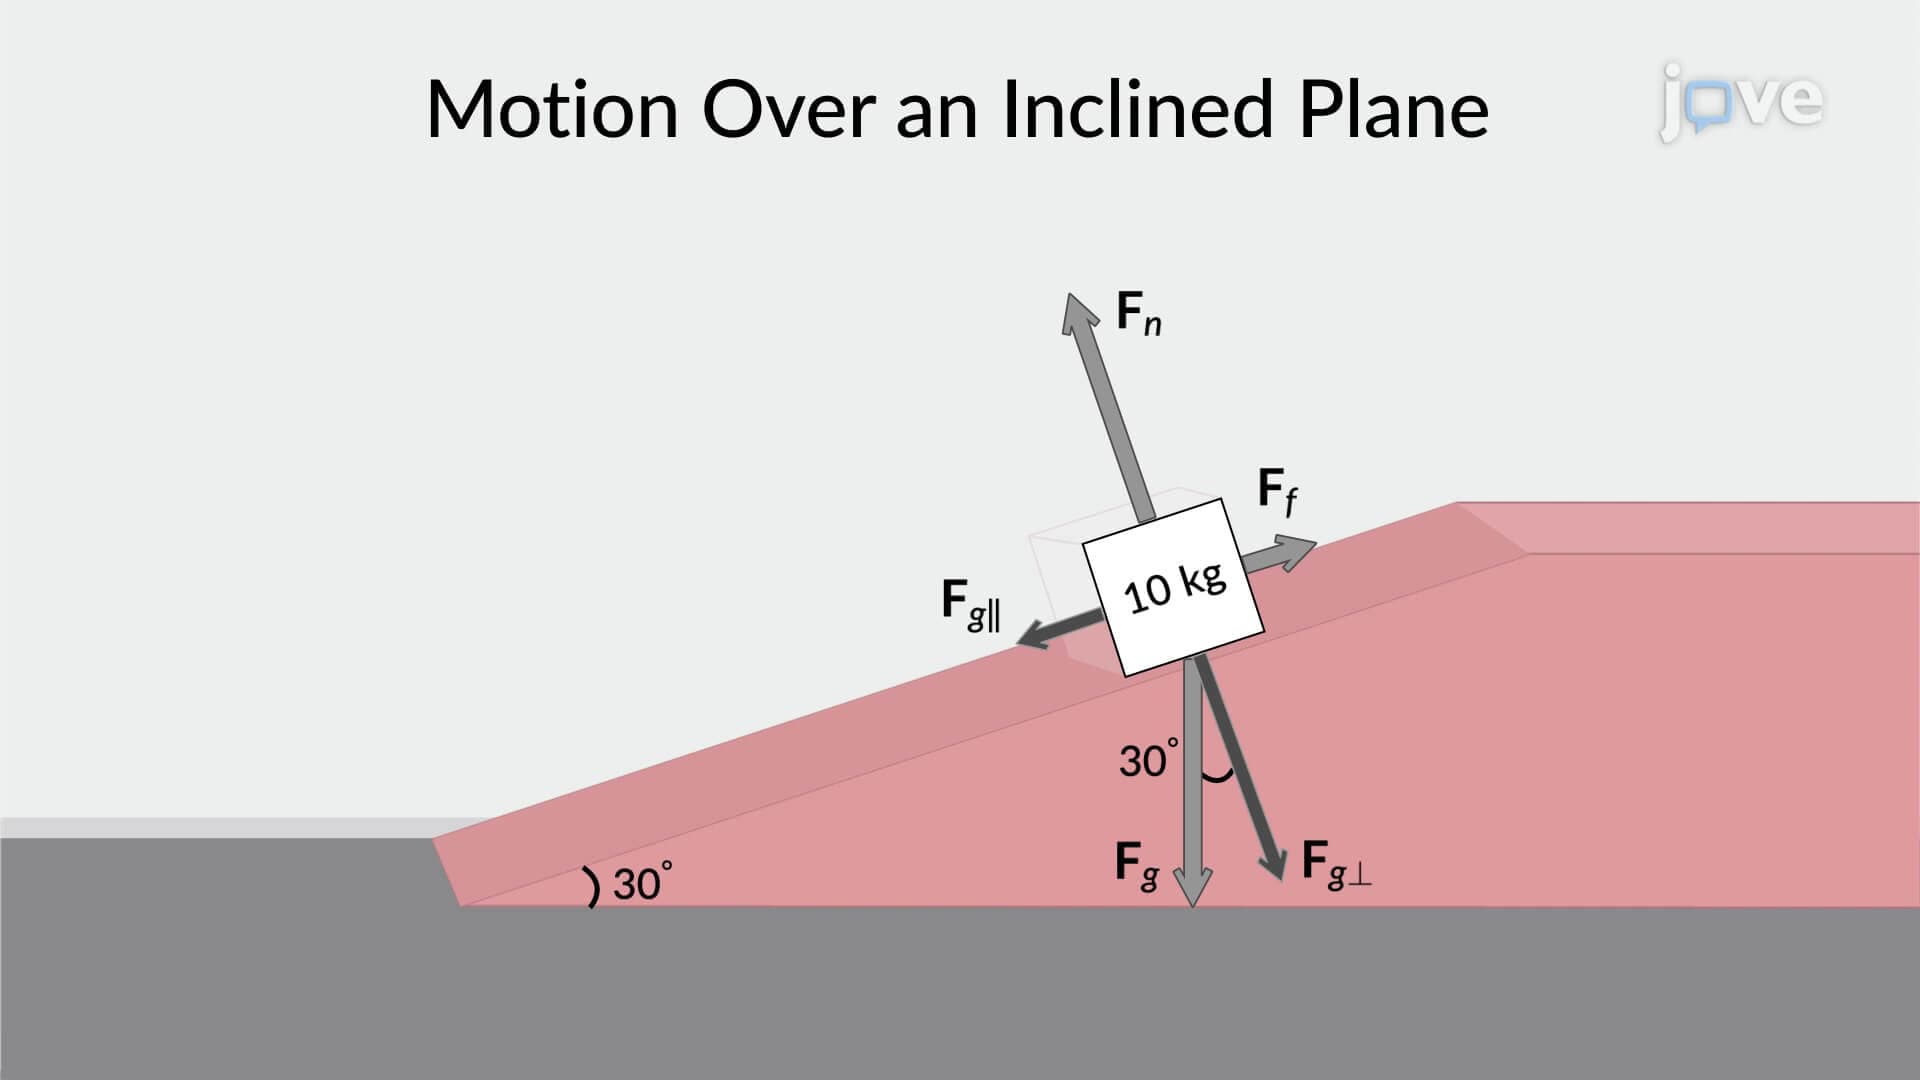
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
 01:12
Determining Electric Field From Electric Potential
In general, regardless of whether the electric field is uniform, it points in the direction of decreasing potential because the force on a positive...
 01:13
Finding Electric Potential From Electric Field