Related Experiment Video
Updated: Aug 2, 2025

A Tactile Automated Passive-Finger Stimulator TAPS
Published on: June 3, 2009
Biomechanics of the finger pad in response to torsion
Sophie du Bois de Dunilac1, David Córdova Bulens1, Philippe Lefèvre2
1School of Electrical and Electronic Engineering, University College Dublin, Belfield, Dublin 4, Ireland.

Abstract:
Surface skin deformation of the finger pad during partial slippage at finger-object interfaces elicits firing of the tactile sensory afferents. A torque around the contact normal is often present during object manipulation, which can cause partial rotational slippage. Until now, studies of surface skin deformation have used stimuli sliding rectilinearly and tangentially to the skin. Here, we study surface skin dynamics under pure torsion of the right index finger of seven adult participants (four males). A custom robotic platform stimulated the finger pad with a flat clean glass surface, controlling the normal forces and rotation speeds applied while monitoring the contact interface using optical imaging. We tested normal forces between 0.5 N and 10 N at a fixed angular velocity of 20° s-1 and angular velocities between 5° s-1 and 100° s-1 at a fixed normal force of 2 N. We observe the characteristic pattern by which partial slips develop, starting at the periphery of the contact and propagating towards its centre, and the resulting surface strains. The 20-fold range of normal forces and angular velocities used highlights the effect of those parameters on the resulting torque and skin strains. Increasing normal force increases the contact area, the generated torque, strains and the twist angle required to reach full slip. On the other hand, increasing angular velocity causes more loss of contact at the periphery and higher strain rates (although it has no impact on resulting strains after the full rotation). We also discuss the surprisingly large inter-individual variability in skin biomechanics, notably observed in the twist angle the stimulus needs to rotate before reaching full slip.
Related Concept Videos
 01:17
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:09
Torsional Pendulum
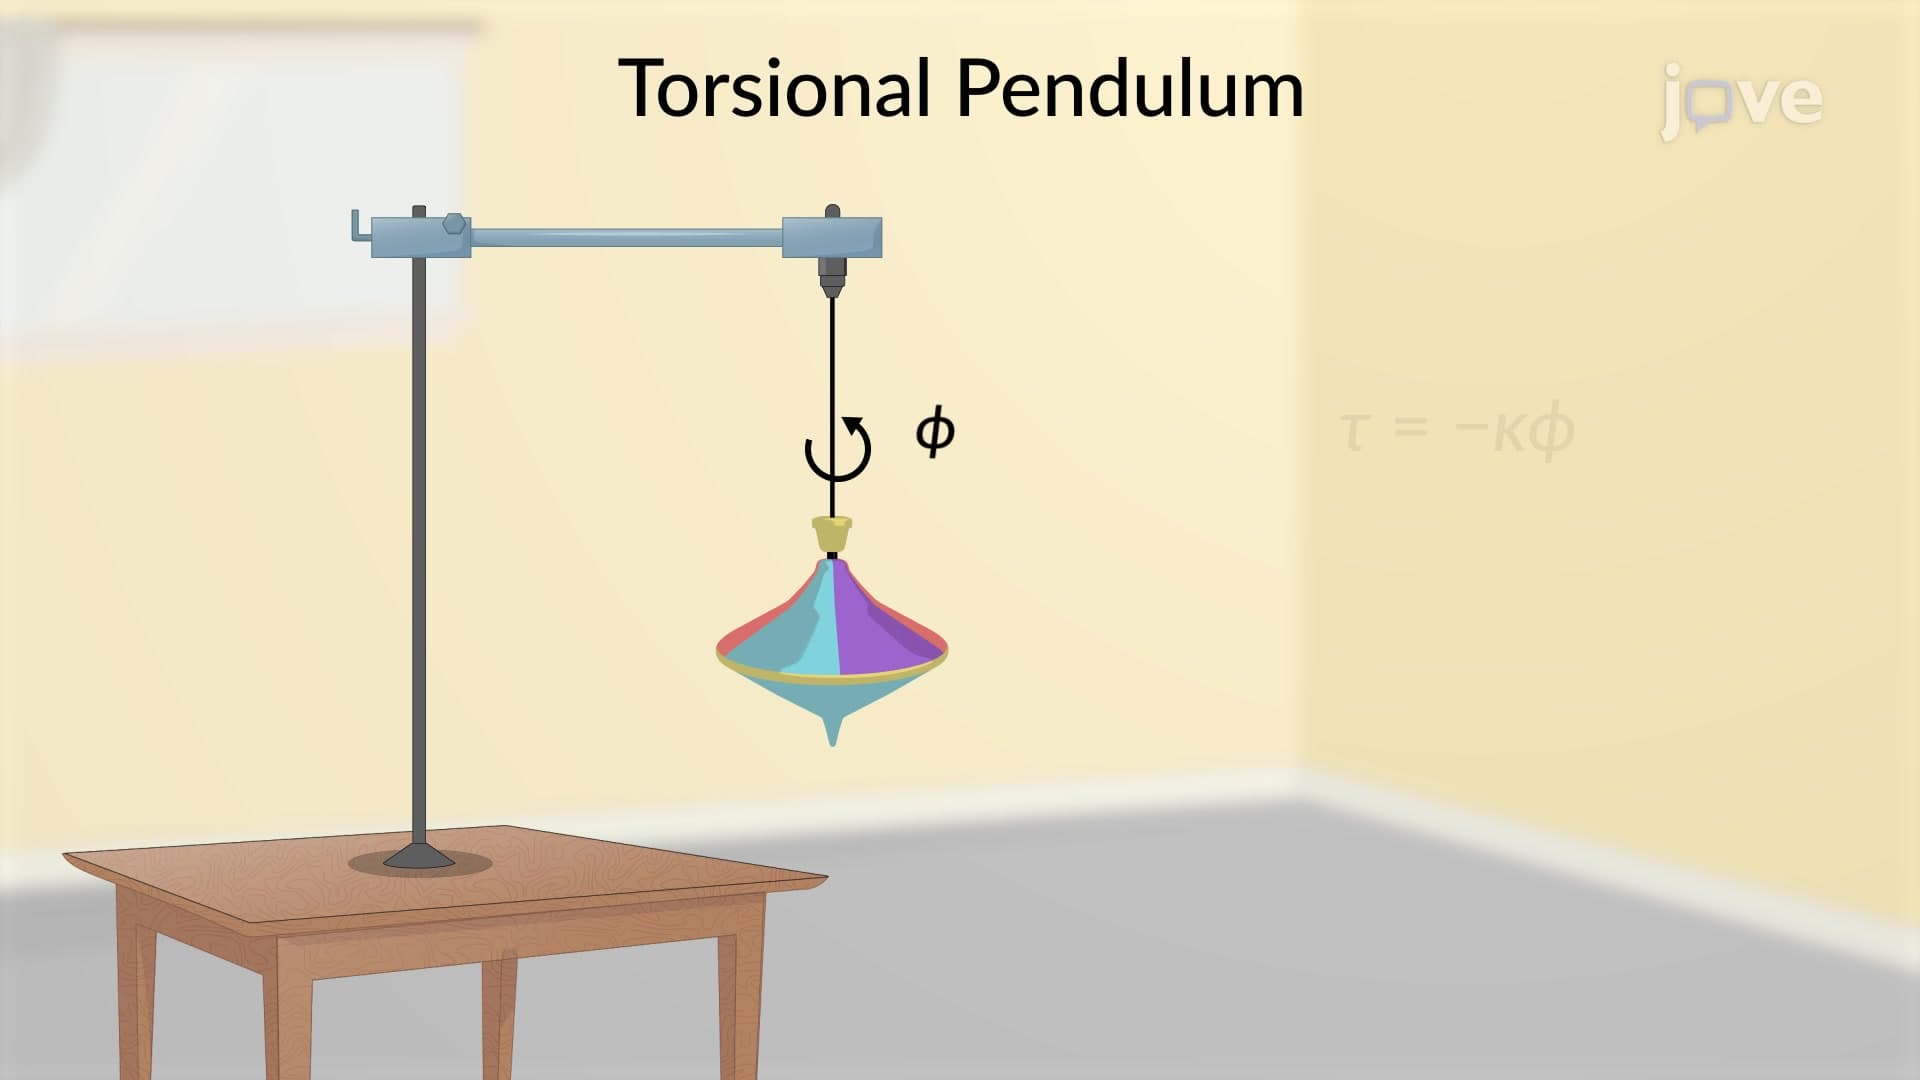
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:13
Cell-matrix's Response to Mechanical Forces
Anchoring junctions mechanically attach a cell to the...
 01:19
Net Torque Calculations
 01:10
Torque
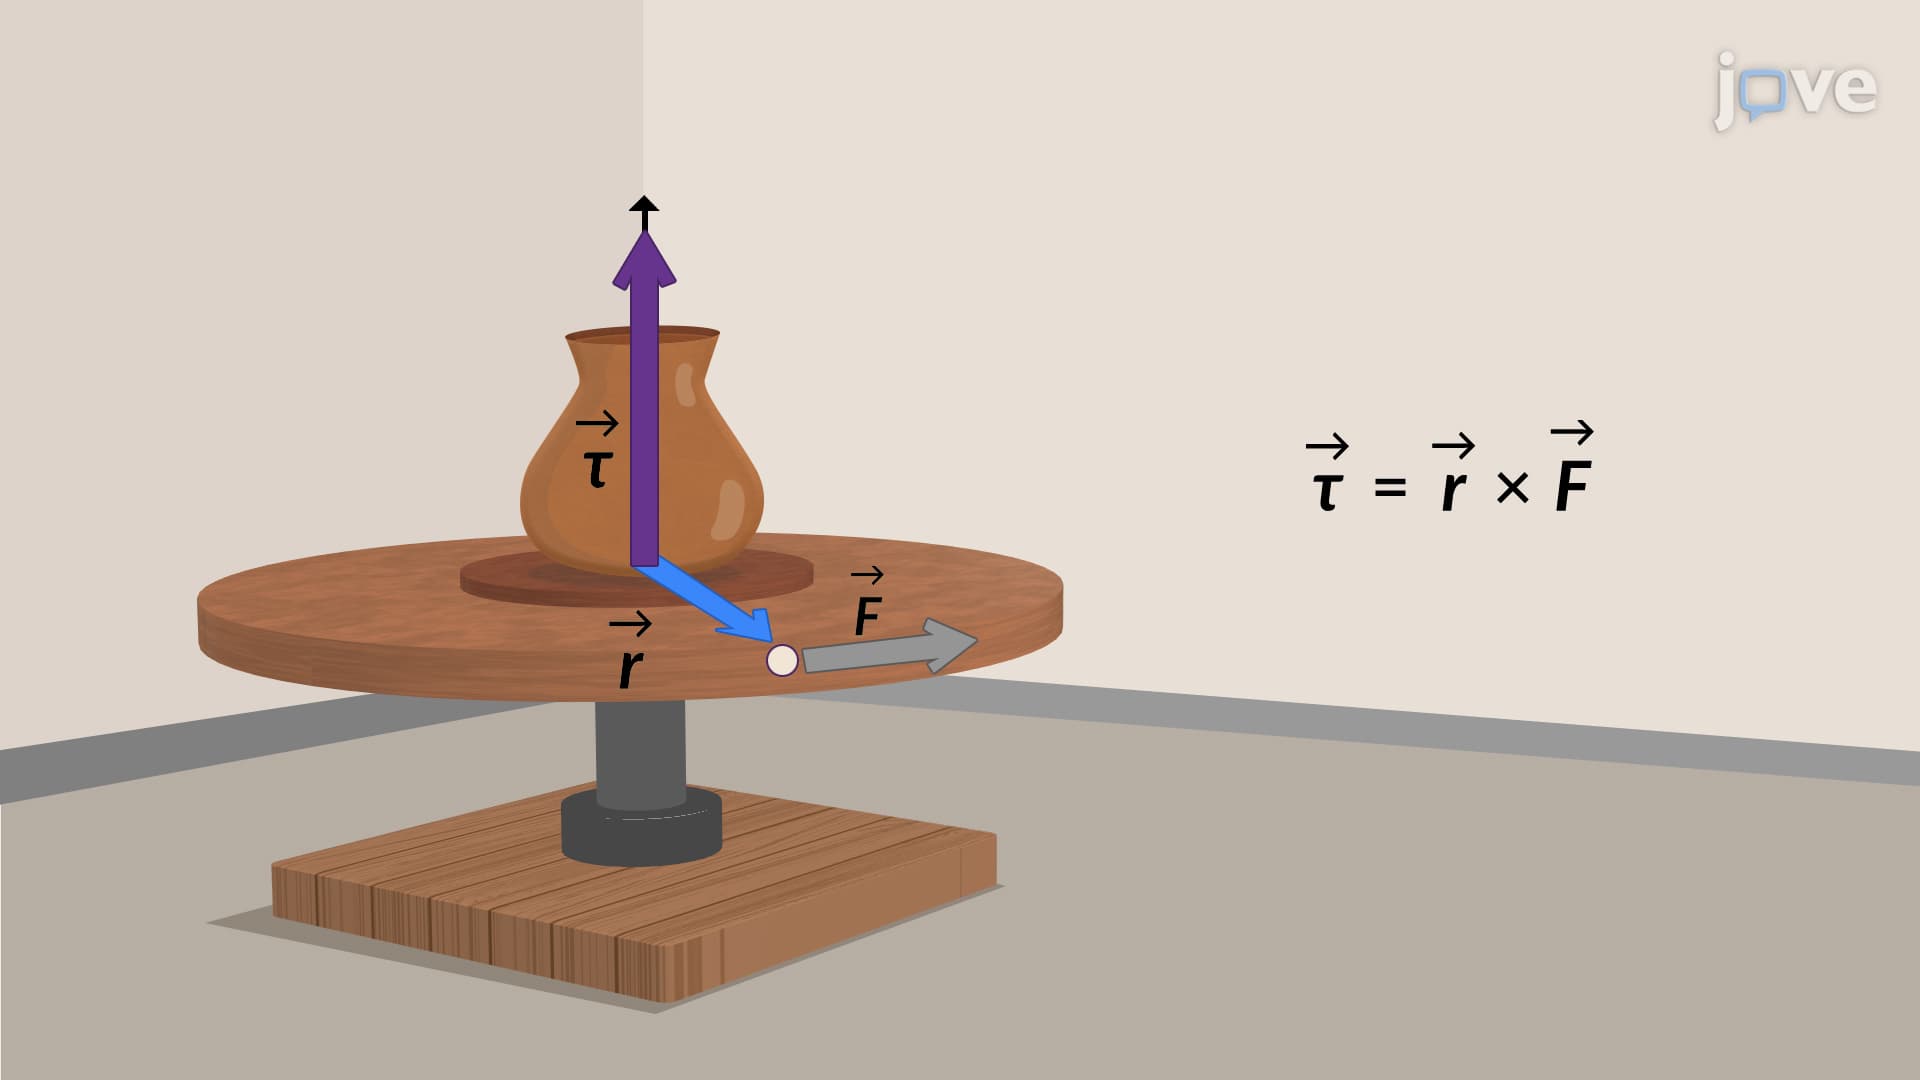
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:20
Bending and Torsional Moments
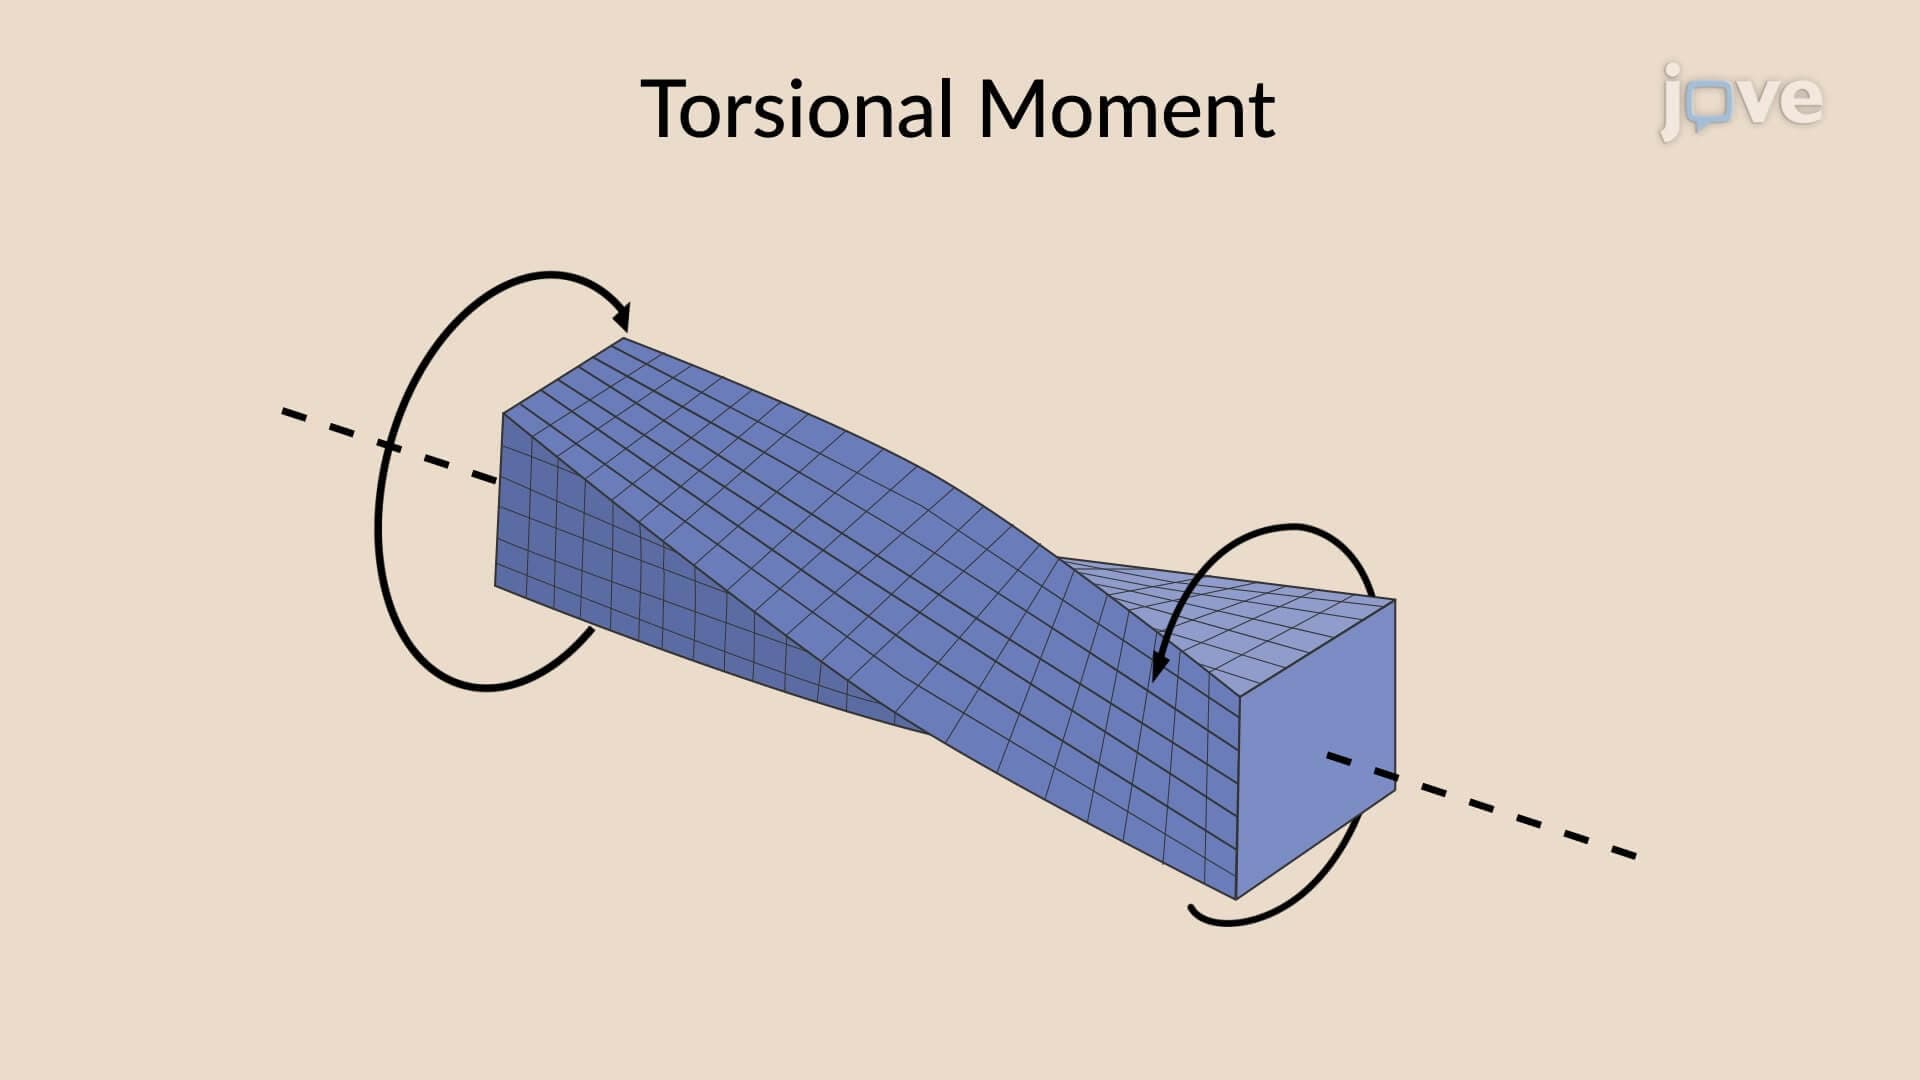
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...