Related Experiment Video
Updated: Aug 2, 2025


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
MateJam: Multi-Material Teeth-Clutching Layer Jamming Actuation for Soft Haptic Glove

Abstract:
Most existing force feedback gloves use rigid exoskeleton with large structural dimensions, making it challenging to meet the future demand of virtual reality (VR) applications for large-scale end users. There is an urgent need to develop soft and ultrathin gloves similar to daily gloves. Different from the idea of regulating the friction between layers, here we propose a multi-material teeth-clutching layer jamming (MateJam) actuator, which can achieve distinctive bending stiffness in free and constrained space. The actuator consists of multi-material layers whose modulus span three orders of magnitude, including flexible substrate layer, limiting layer, rigid micro-teeth clutching structure layer, sliding film boundary layer, and sealed shell layer. In free space, the flexible substrate, and the rigid micro-teeth array structure form flexible hinges, ensuring low resistance. In constrained space, the engagement degree of the rigid micro-teeth array is controlled by vacuum pressure to continuously adjust the output resistance. Reliable switching between free and constrained space is ensured by introducing the sliding film boundary layer and the optimized design of the micro-teeth cross-sectional shape. The force output ratio between free and constrained space reaches over 20 times (0.45N vs. 11.95N). The thickness of the actuator is as low as 3.8mm (clutched state), and the weight of the glove is 44.03g. The ultrathin formfactor and the low cost fabrication process makes the MateJam glove a promising solution for VR applications in home entertainment and social interactions.

Related Concept Videos
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:17
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:14
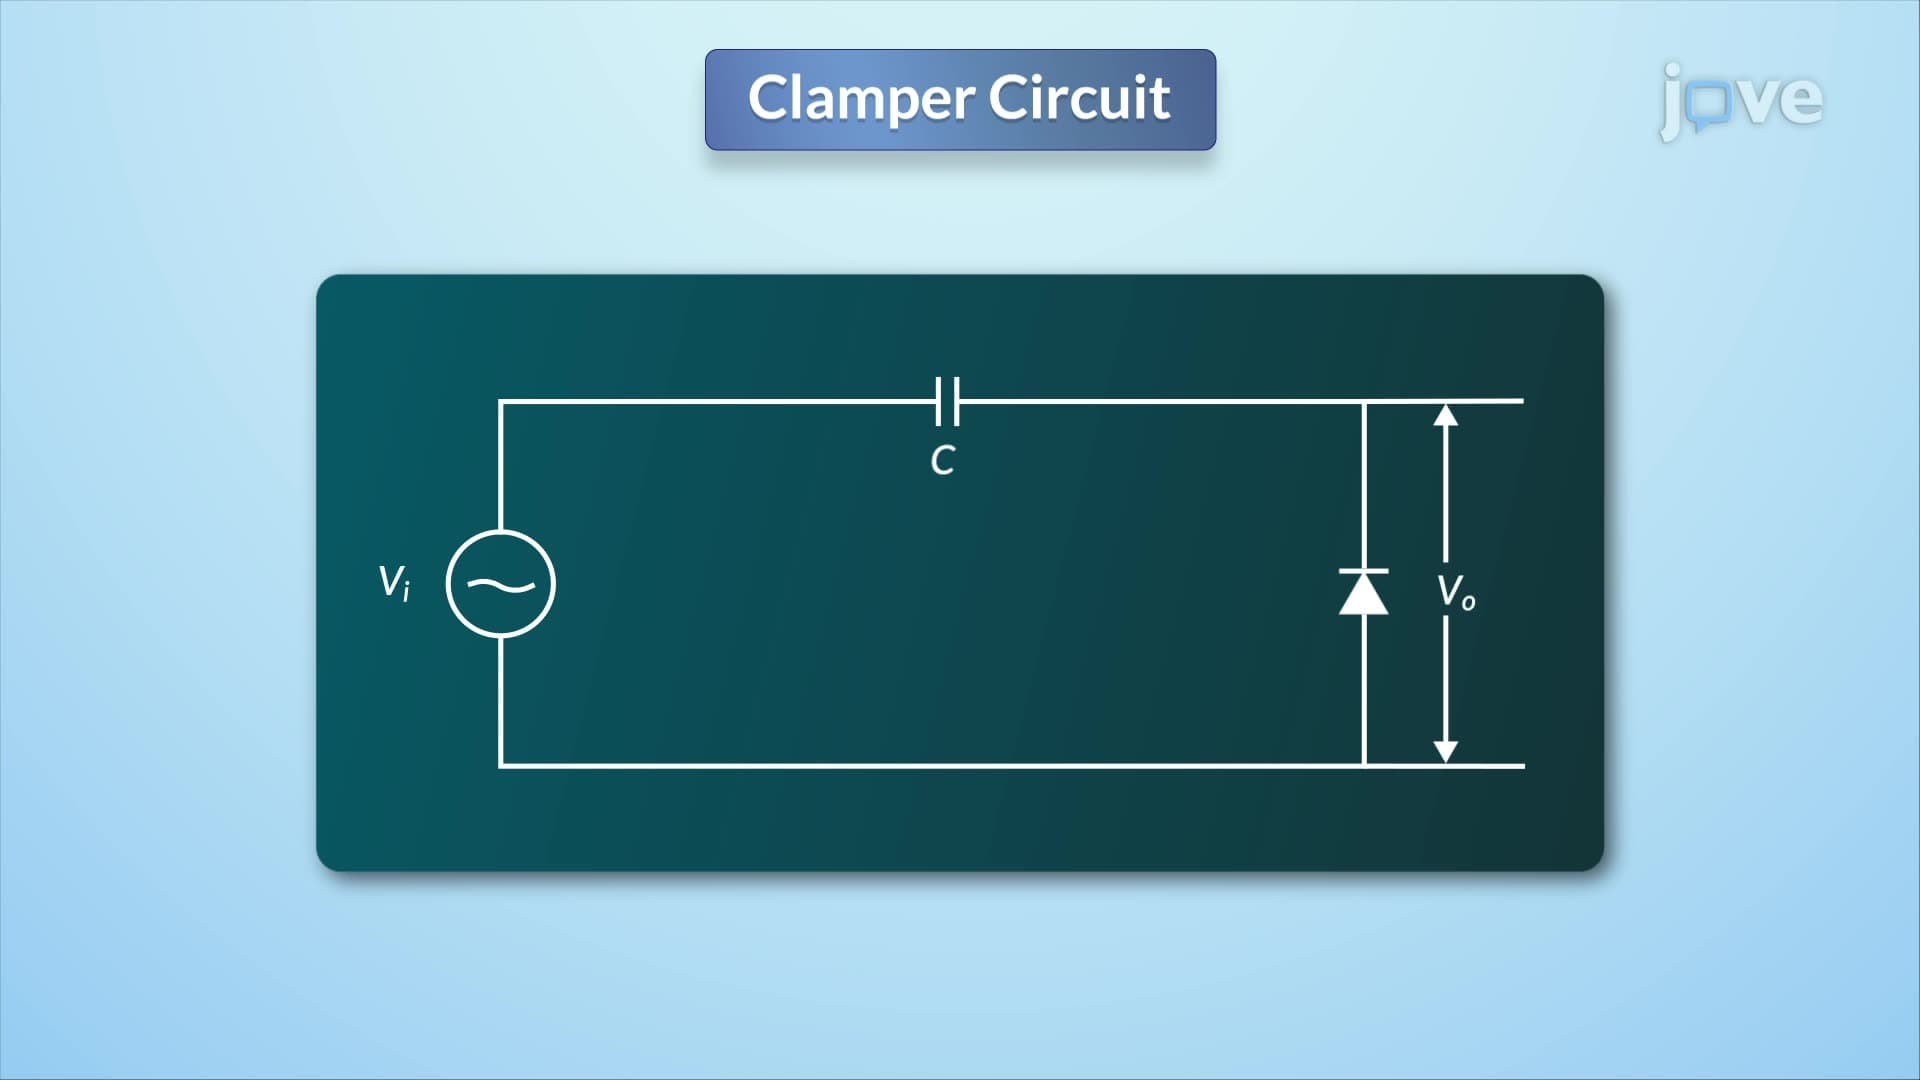
Clamper Circuit
Within this circuit, the diode's orientation prompts the capacitor to charge up to the level of the most negative peak of the input signal. Upon reaching this state, the diode ceases to...
 01:26
Kinetic Friction
 01:07
Frictional Force
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...