Related Experiment Video
Updated: Aug 1, 2025
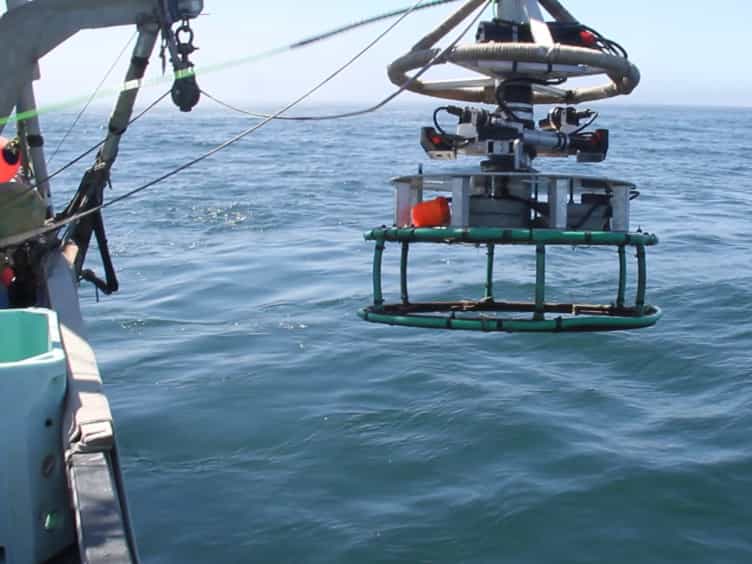

Development of New Methods for Quantifying Fish Density Using Underwater Stereo-video Tools
Published on: November 20, 2017
Real-Time Stereo-Based Ocean Surface Mapping for Robotic Floating Platforms: Concept and Methodology
Or Greenberg1, Boaz Ben-Moshe1
1Kinematics and Computational Geometry lab., School of Computer Science, Ariel University, Ariel 4070000, Israel.

Abstract:
Consider the case of a small, unmanned boat that is performing an autonomous mission. Naturally, such a platform might need to approximate the ocean surface of its surroundings in real-time. Much like obstacle mapping in autonomous (off-road) rovers, an approximation of the ocean surface in a vessel's surroundings in real-time can be used for improved control and optimized route planning. Unfortunately, such an approximation seems to require either expensive and heavy sensors or external logistics that are mostly not available for small or low-cost vessels. In this paper, we present a real-time method for detecting and tracking ocean waves around a floating object that is based on stereo vision sensors. Based on a large set of experiments, we conclude that the presented method allows reliable, real-time, and cost-effective ocean surface mapping suitable for small autonomous boats.
More Related Videos
 06:36
A Field Primer for Monitoring Benthic Ecosystems Using Structure-From-Motion Photogrammetry
Published on: April 15, 2021
 13:35
Reefshape: A System for the Efficient Collection and Automated Processing of Time-Series Underwater Photogrammetry Data for Benthic Habitat Monitoring
Published on: June 13, 2025
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:30
Types of Global Positioning System Surveys
 01:29
Topographic Surveying and Contours
 01:25
Methods of Obtaining Topography
 01:18
Uniform Depth Channel Flow: Problem Solving
 00:59
Buoyancy