Related Experiment Video
Updated: Jul 31, 2025
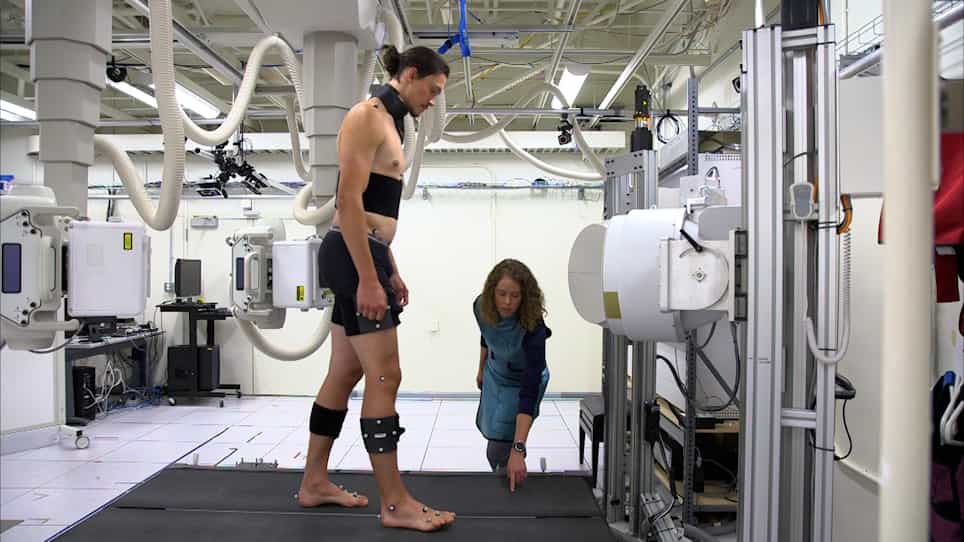

In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
A novel algorithm to efficiently calculate the impingement-free range of motion of irregularly-shaped total hip
Tao Feng1, Hao Tang2, Xiaogang Zhang1
1Tribology Research Institute, School of Mechanical Engineering, Southwest Jiaotong University, Chengdu, China.

Abstract:
There is great difficulty in quickly calculating the impingement-free range of motion (IFROM) of hip components with complex shapes after total hip arthroplasty. We have established a new algorithm to investigate the effect of different shapes of hip components on the IFROM and impingement-free safe zone (IFSZ). Then find the best combination of hip prosthesis and the optimal mounting position of the elevated-rim liner under different radiographic anteversion (RA) and radiographic inclination (RI) of the cup. We found the larger the opening angle of the beveled-rim liner and the smaller the cross-sectional area of the stem neck with an inverted teardrop cross-sectional shape, the greater the IFROM of the hip component. The beveled-rim liner in combination with the stem neck with an inverted teardrop-shaped cross-section could provide the greatest IFSZ (excluding the flat-rim liner). The optimal orientation of the elevated-rim liner was the posterior-inferior side (RI ≤ 37°), posterior-superior side (RI ≥ 45°), and posterior side (37° ≤ RI ≤ 45°). Our novel algorithm provides a solution to analyze the IFROM of any hip prosthesis with any complex shape. The shape and size of the cross-section of the stem neck, the orientation of the elevated rim, and the shape and opening angle of the liner are all critical factors for the quantitative calculation of the IFROM and mounting safe zone of the prosthesis. Stem necks with inverted teardrop cross-section and beveled-rim liner improved the IFSZ. The optimal direction of the elevated rim is not constant but varies with RI and RA.
More Related Videos
 09:31
Individualized Stem-positioning in Calcar-guided Short-stem Total Hip Arthroplasty
Published on: February 27, 2018
 09:51
The Transition to an Anterior-Based Muscle Sparing Approach Improves Early Postoperative Function but is Associated with a Learning Curve
Published on: September 7, 2022