Related Experiment Video
Updated: Jul 31, 2025
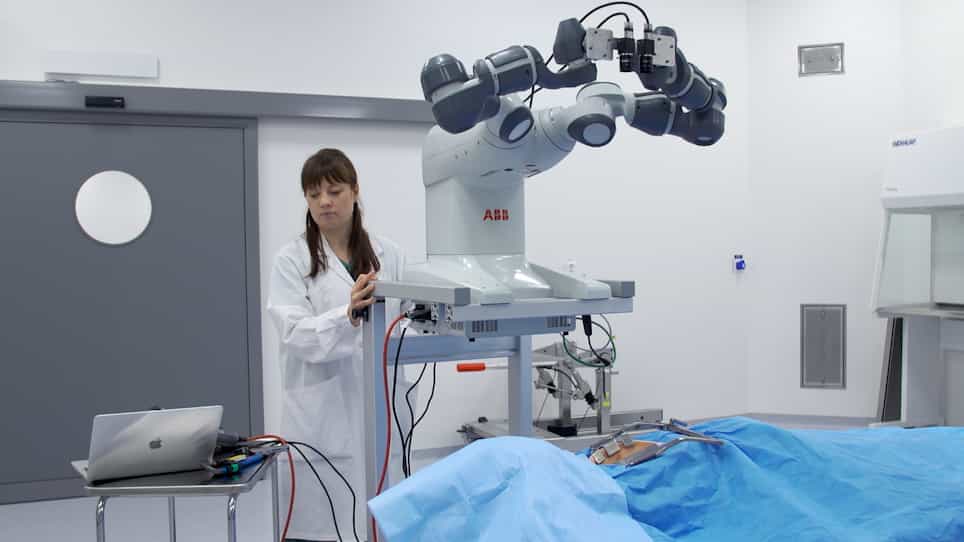
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Real-time depth completion based on LiDAR-stereo for autonomous driving
Ming Wei1,2, Ming Zhu1, Yaoyuan Zhang1,2
1Changchun Institute of Optics, Fine Mechanics and Physics, Chinese Academy of Sciences, Changchun, China.

Abstract:
The integration of multiple sensors is a crucial and emerging trend in the development of autonomous driving technology. The depth image obtained by stereo matching of the binocular camera is easily influenced by environment and distance. The point cloud of LiDAR has strong penetrability. However, it is much sparser than binocular images. LiDAR-stereo fusion can neutralize the advantages of the two sensors and maximize the acquisition of reliable three-dimensional information to improve the safety of automatic driving. Cross-sensor fusion is a key issue in the development of autonomous driving technology. This study proposed a real-time LiDAR-stereo depth completion network without 3D convolution to fuse point clouds and binocular images using injection guidance. At the same time, a kernel-connected spatial propagation network was utilized to refine the depth. The output of dense 3D information is more accurate for autonomous driving. Experimental results on the KITTI dataset showed that our method used real-time techniques effectively. Further, we demonstrated our solution's ability to address sensor defects and challenging environmental conditions using the p-KITTI dataset.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:12
Differential Leveling
 01:18
Distance Measurements by Taping
 01:18
Uniform Depth Channel Flow: Problem Solving
 02:16
Light Acquisition
 01:30
Types of Global Positioning System Surveys