Related Experiment Video
Updated: Jul 31, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Neuroadaptive Fault-Tolerant Control Embedded With Diversified Activating Functions With Application to Auto-Driving

Abstract:
This article presents a neuroadaptive fault-tolerant control method for path tracking of multiinput multioutput (MIMO) systems in the presence of modeling uncertainties and external disturbances. In dealing with modeling uncertainties, neural networks (NNs) with diversified activation/basis functions are considered, with which we establish a set of control algorithms that are robust against uncertainties, adaptive to unknown parameters, and tolerant to actuation faults. This is the first work that explicitly takes into account the neural weights uncertainties and activating function uncertainties in multiple layered neural networks in control design. In addition, we apply the developed control algorithms to unmanned ground vehicles (UGVs) with actuator failures. With the aid of Lyapunov stability theory, it is shown that the proposed control is able to drive the vehicle along the desired path with high precision and all the internal signals are uniformly ultimately bounded (UUB) and continuous. Both theoretical analysis and numerical simulation confirm the effectiveness of the designed strategy.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 11:12
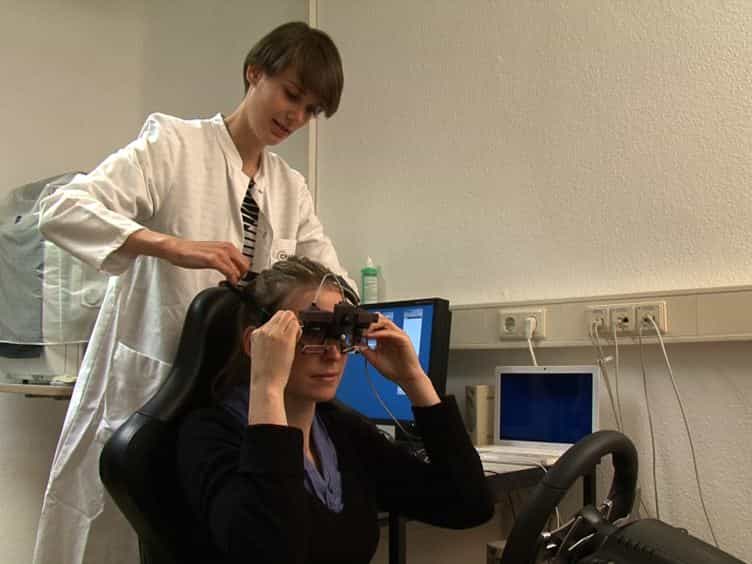
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...