Related Experiment Video
Updated: Jul 30, 2025
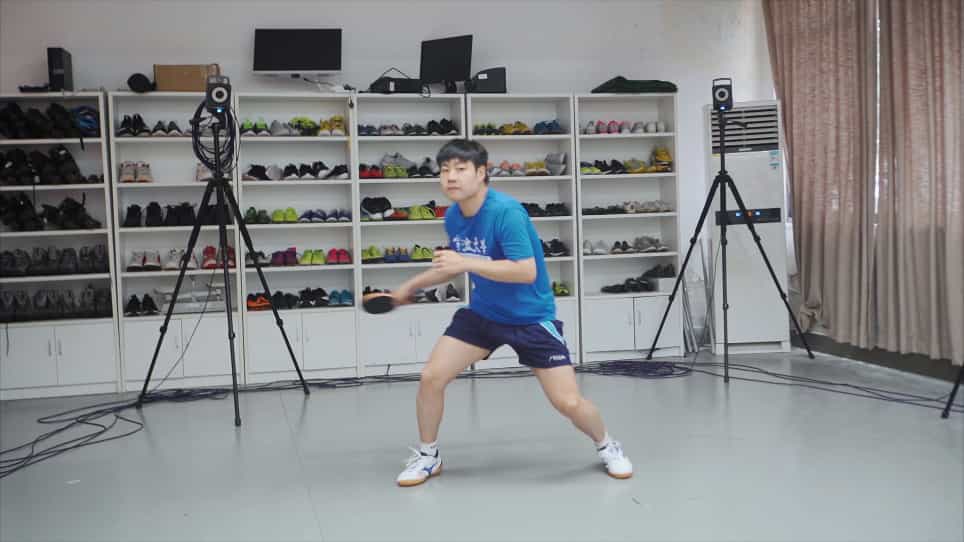
Comparison of Kinetic Characteristics of Footwork during Stroke in Table Tennis: Cross-Step and Chasse Step
Published on: June 16, 2021
Biomechanics of Topspin Forehand Loop in Table Tennis: An Application of OpenSim Musculoskeletal Modelling
Ruizhe Zhu1, Xiaoyi Yang1, Luis C Chong1
1Faculty of Sports Science, Ningbo University, Ningbo 315211, China.

Abstract:
Topspin is one of the most attacking strokes in table tennis, and topspin forehand loop is an effective way to score. The aim of this study was to investigate the kinematics of the lower extremities in topspin forehand loop between different levels via OpenSim Musculoskeletal Modelling. Ten elite athletes (NL1) and ten medium athletes (NL2) performed the topspin forehand loop without muscle and joint injuries. An eight-camera Vicon motion capture system was used to measure the kinematics data. During the topspin forehand loop, the forward phase (FP) and the entire phase (EP) of the NL1 were significantly shorter than that of the NL2. In the sagittal plane, NL1 significantly had greater hip and ankle flexion and extension at range of motion (ROM) but less hip flexion and knee flexion at FP and less ankle flexion at BP than NL2. In the frontal plane, NL1 displayed less ROM in the hip joint and significantly less hip abduction ROM at the backward phase (BP). In the transverse plane, NL1 had a significantly greater ROM in the hip joint and displayed significantly less hip ROM at the BP. The level differences presented in this study could help table tennis athletes to improve performance and coaches to develop technical training.
Related Concept Videos
 01:11
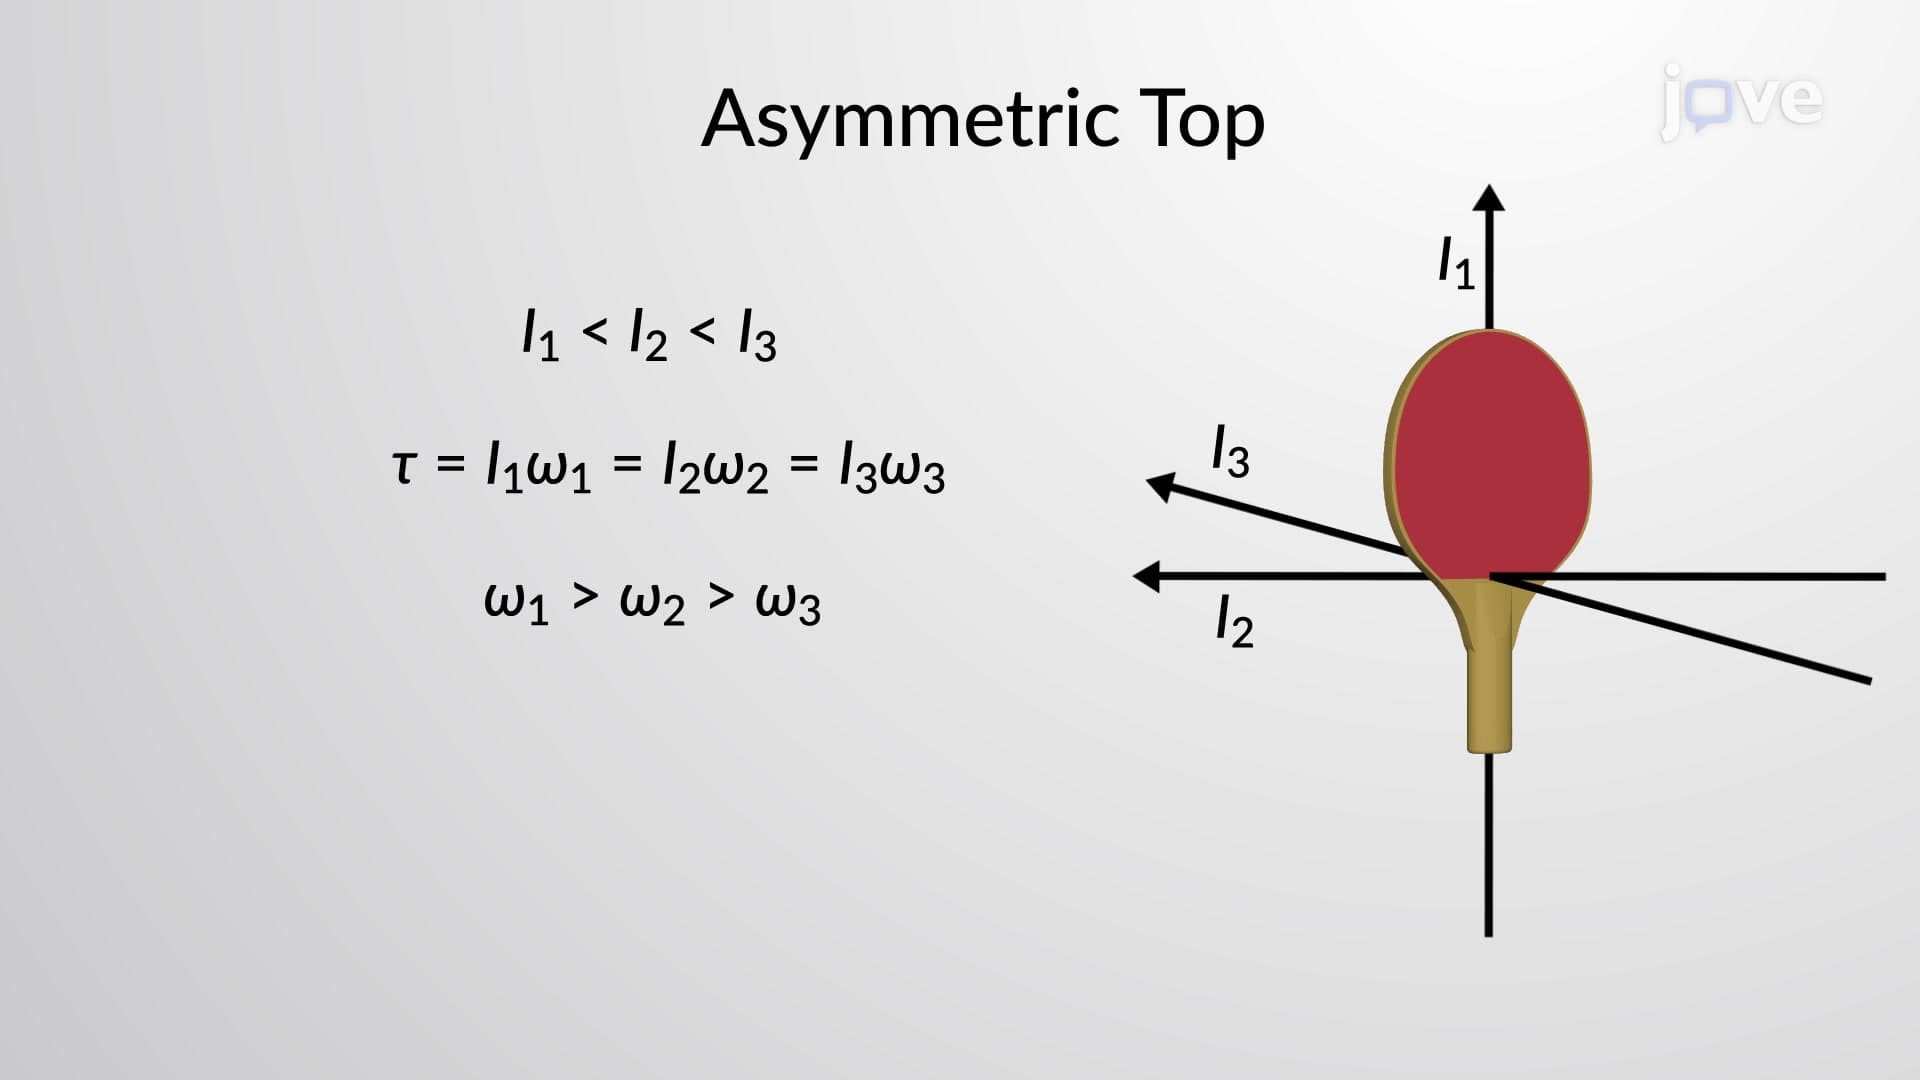
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:30
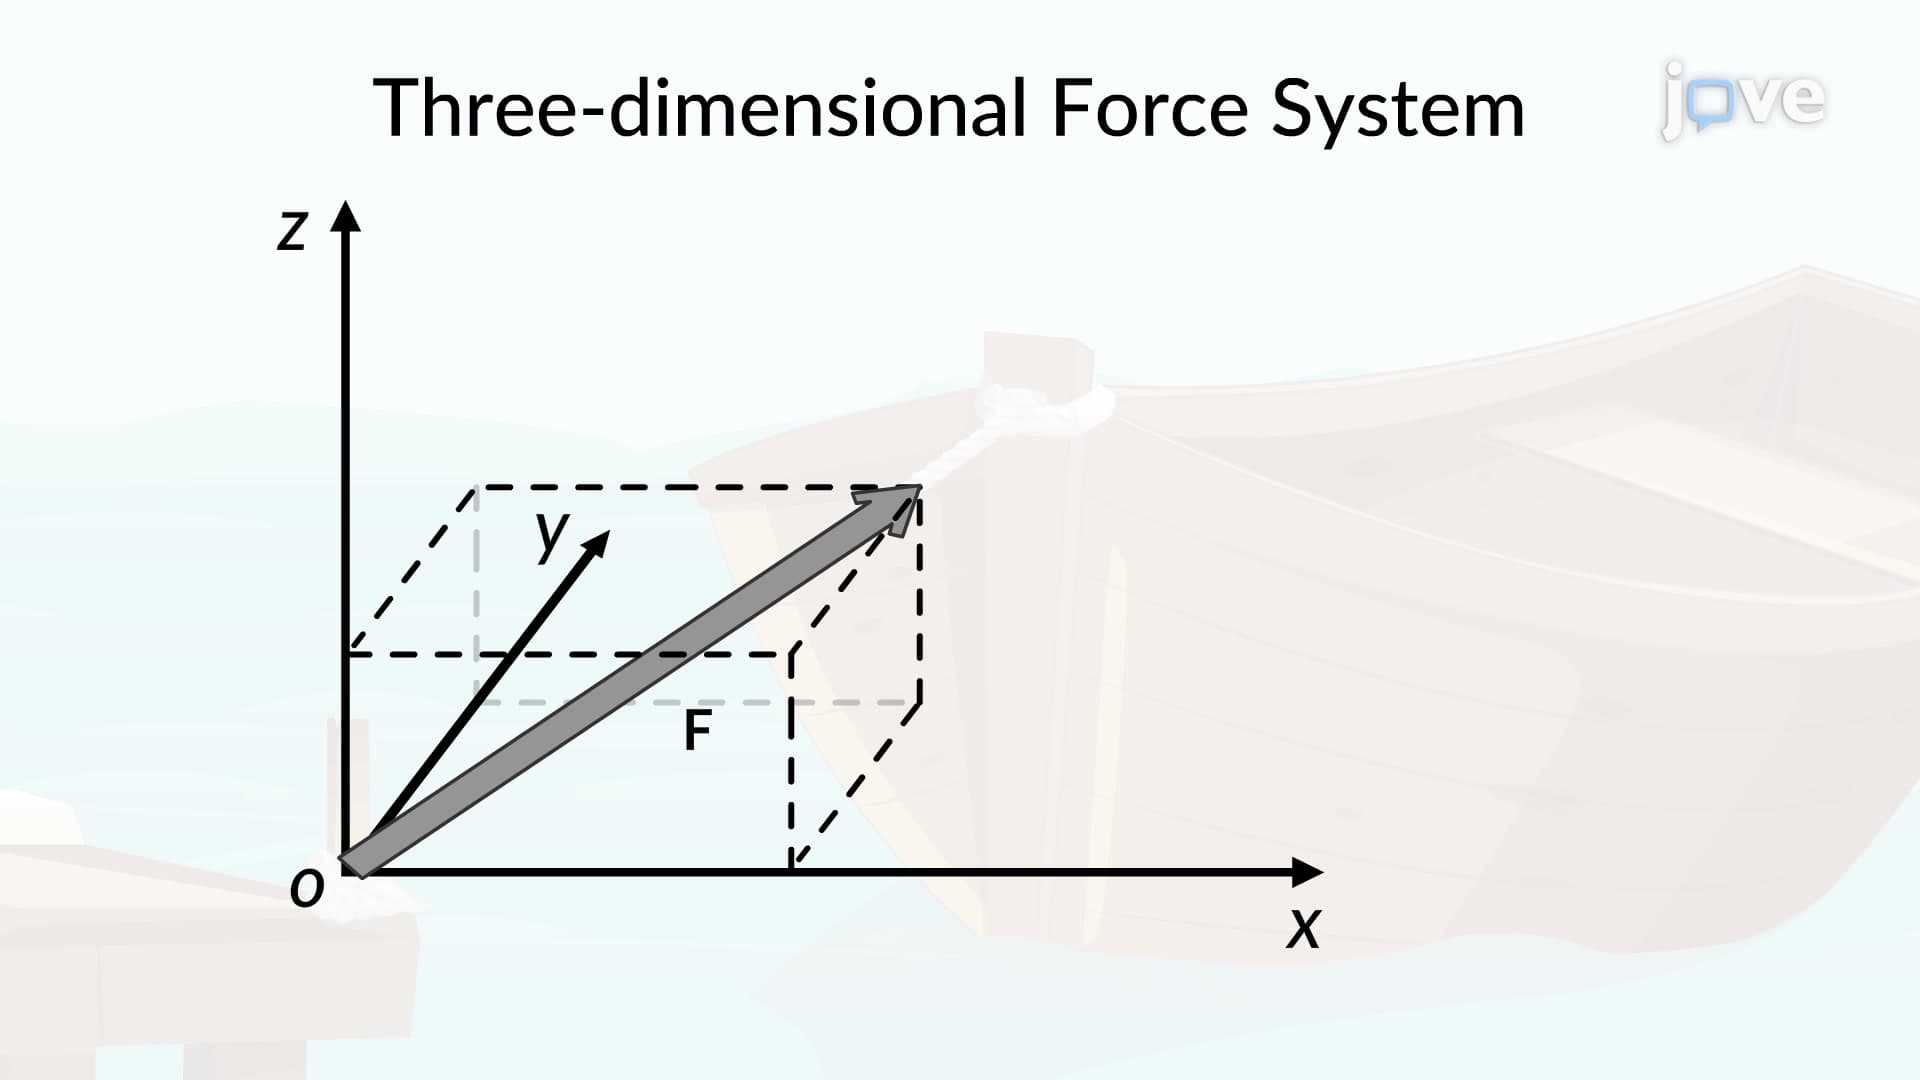
Three-Dimensional Force System
 00:49
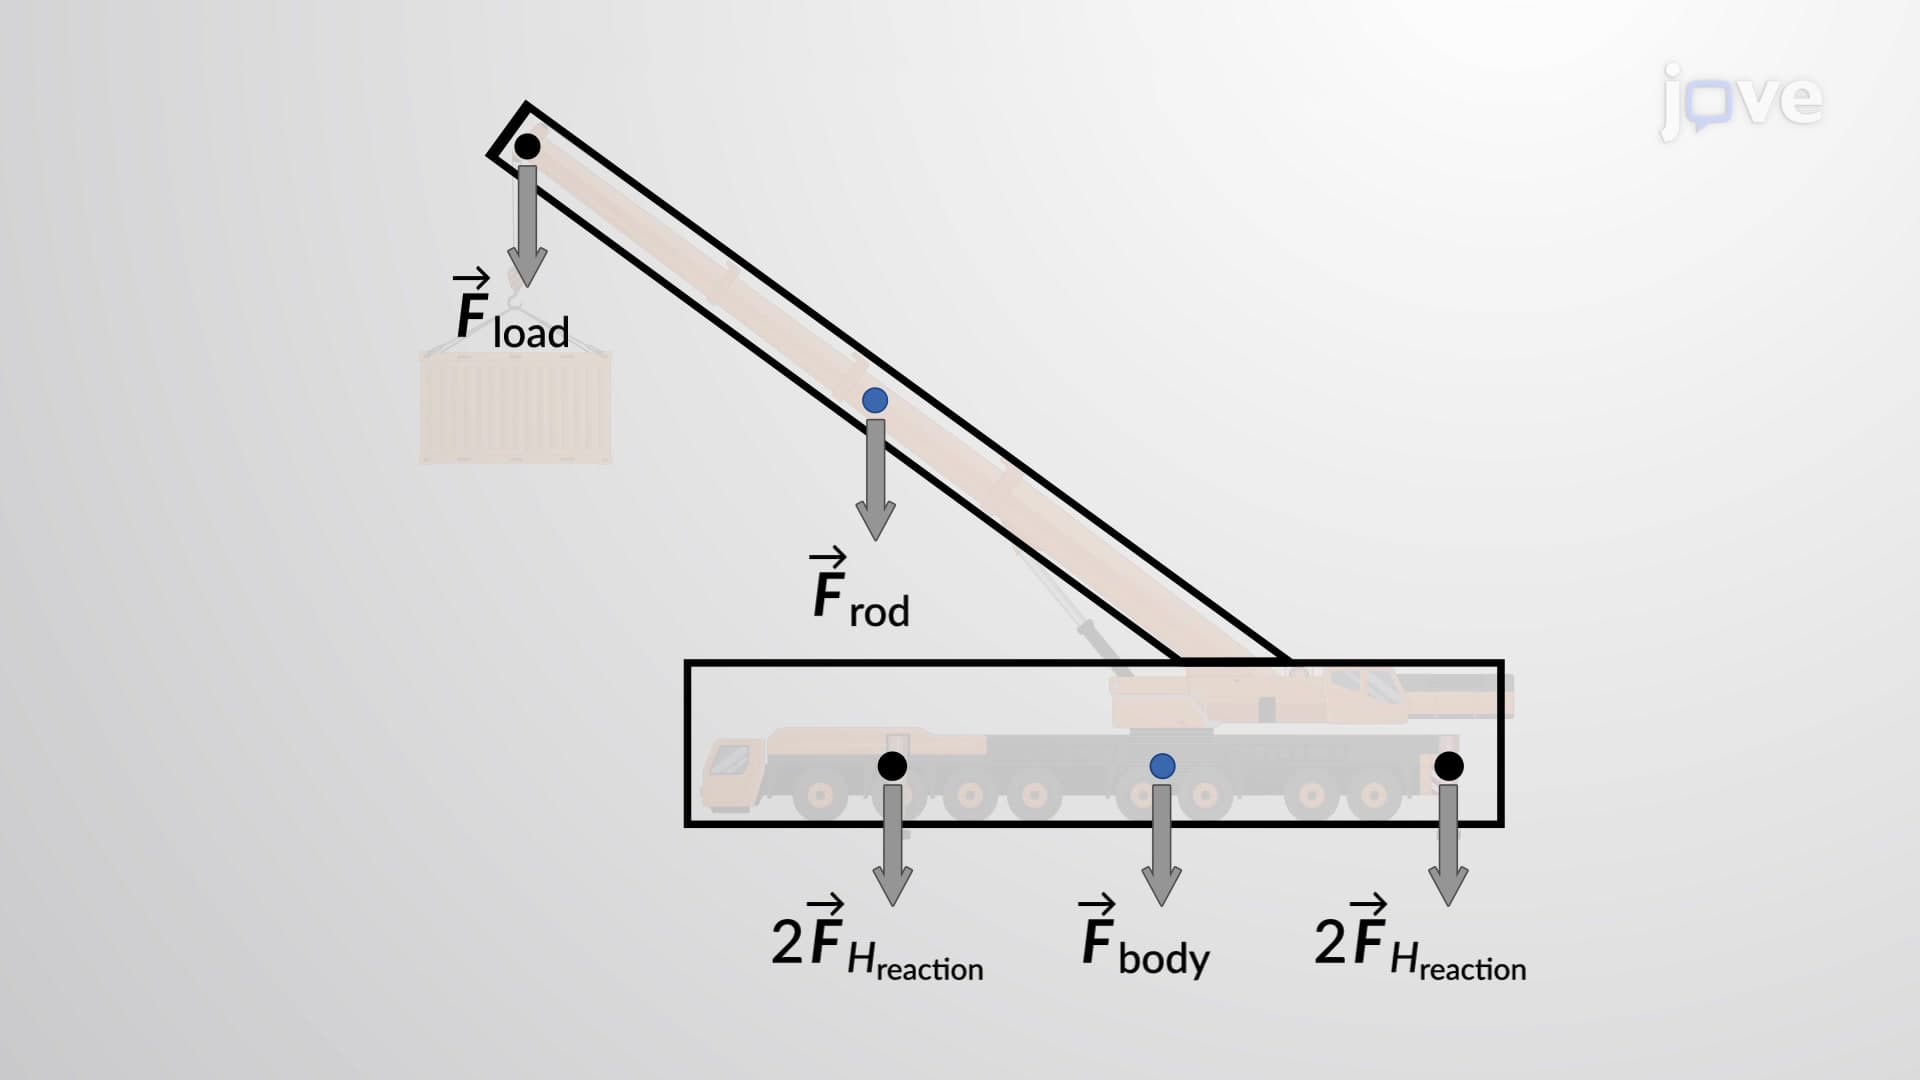
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:05
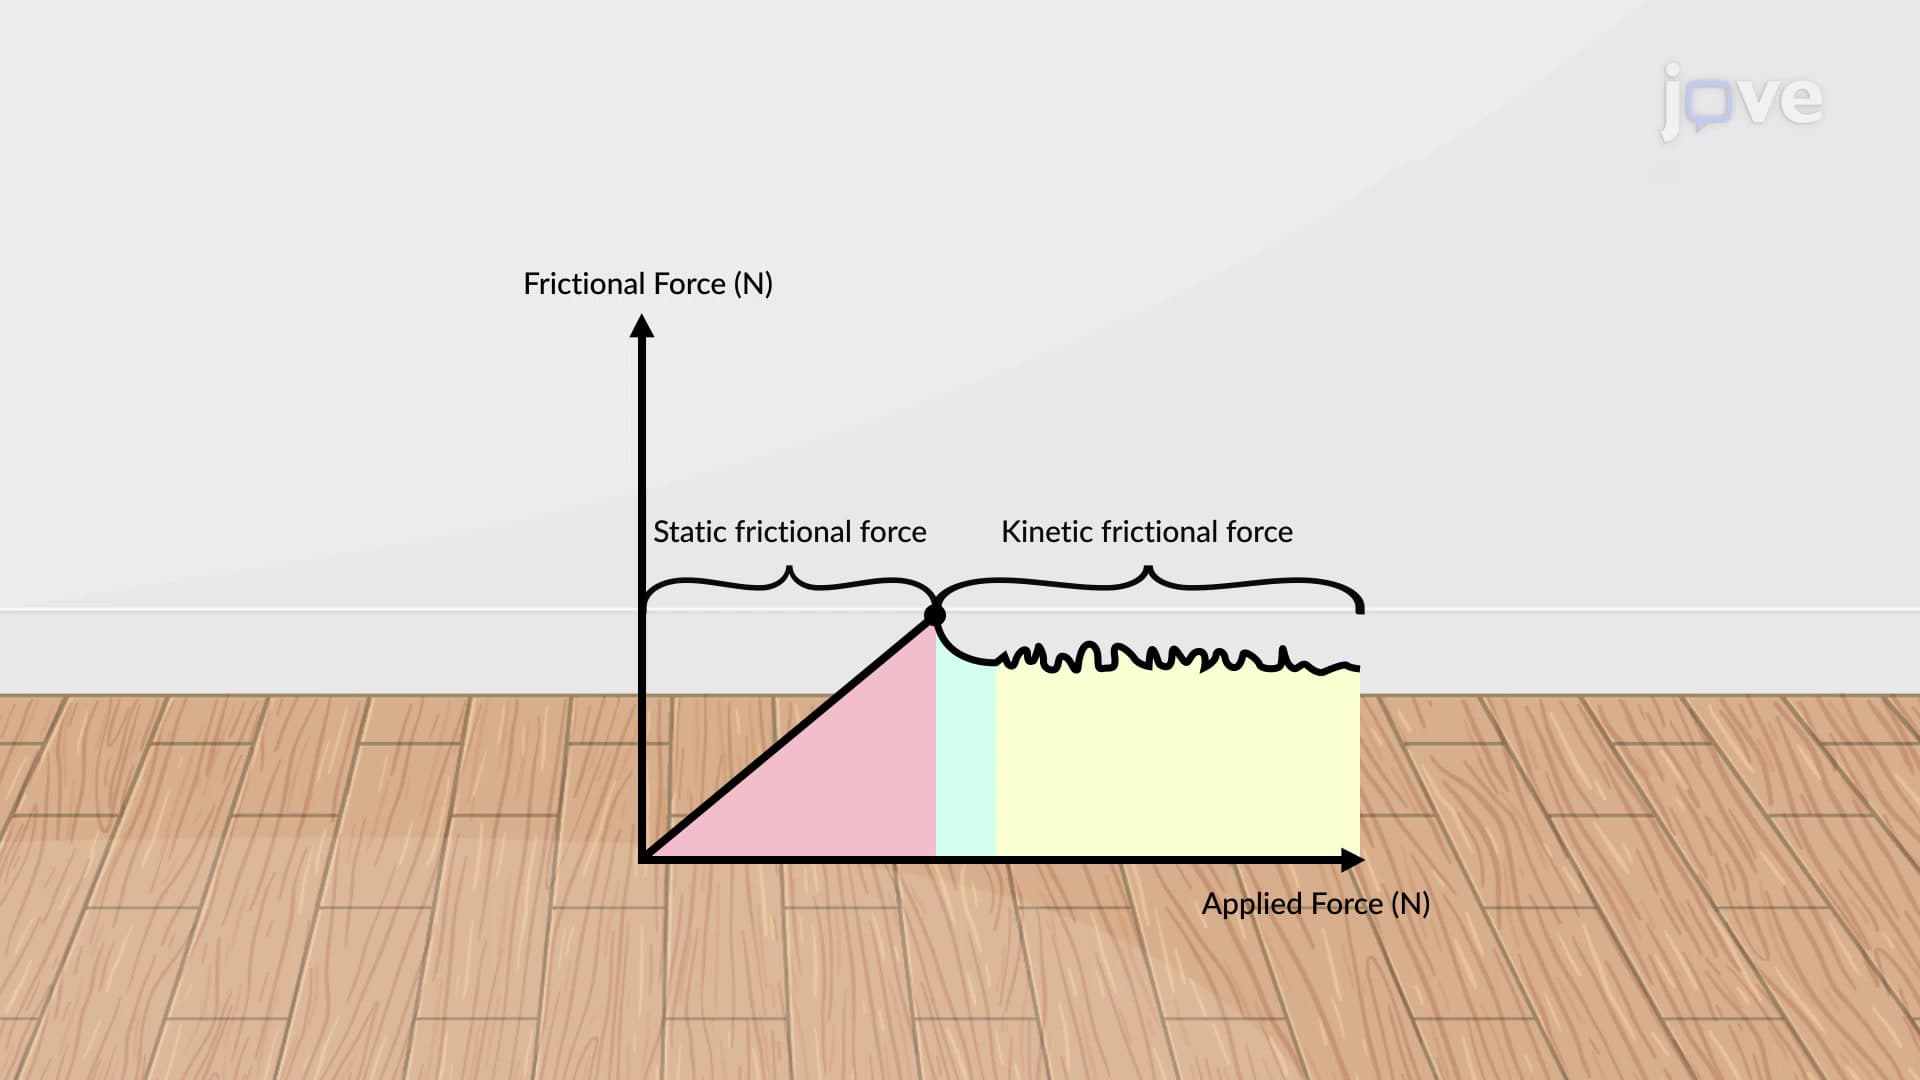
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...