Related Experiment Video
Updated: Jul 30, 2025


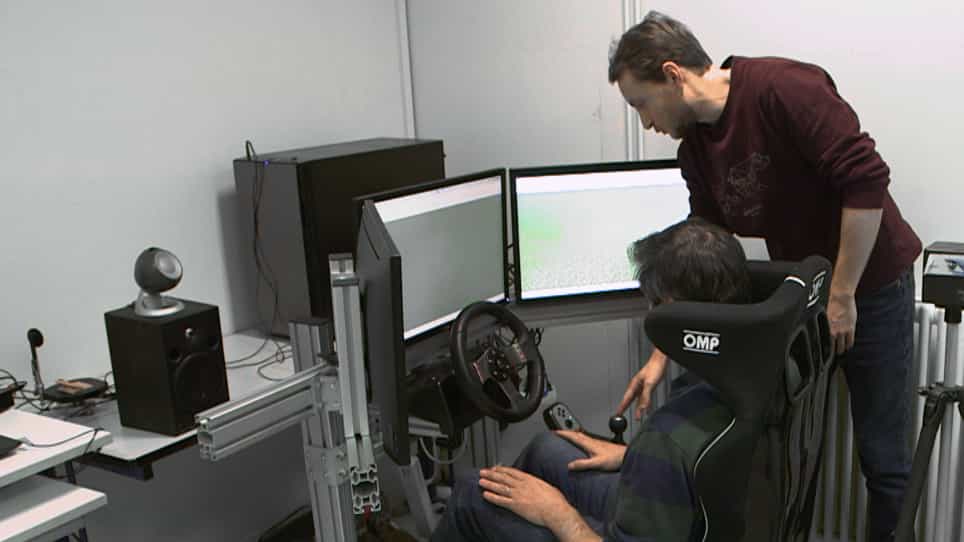
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Detecting and Tracking Unsafe Lane Departure Events for Predicting Driver Safety in Challenging Naturalistic Driving
Luis Riera1, Koray Ozcan2, Jennifer Merickel3
1Department of Mechanical Engineering, Iowa State University, Ames, IA 50011, USA.

Abstract:
Our goal is to improve driver safety predictions in at-risk medical or aging populations from naturalistic driving video data. To meet this goal, we developed a novel model capable of detecting and tracking unsafe lane departure events (e.g., changes and incursions), which may occur more frequently in at-risk driver populations. The model detects and tracks roadway lane markings in challenging, low-resolution driving videos using a semantic lane detection pre-processor (Mask R-CNN) utilizing the driver's forward lane region, demarking the convex hull that represents the driver's lane. The hull centroid is tracked over time, improving lane tracking over approaches which detect lane markers from single video frames. The lane time series was denoised using a Fix-lag Kalman filter. Preliminary results show promise for robust lane departure event detection. Overall recall for detecting lane departure events was 81.82%. The F1 score was 75% (precision 69.23%) and 70.59% (precision 62.07%) for left and right lane departures, respectively. Future investigations include exploring (1) horizontal offset as a means to detect lead vehicle proximity, even when image perspectives are known to have a chirp effect and (2) Long Short Term Memory (LSTM) models to detect peaks instead of a peak detection algorithm.

Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:10
Detection of Black Holes
Their closest cousins are neutron stars, which are composed almost entirely of neutrons packed against each other, making them extremely dense. A neutron star has the same mass as the Sun but its diameter is only a few kilometers. Therefore, the escape velocity from their surface is close to the speed of light.
Not until the 1960s, when the first neutron...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...