Related Experiment Video
Updated: Jul 30, 2025


Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
Feasibility of an Intelligent Algorithm Based on an Assist-as-Needed Controller for a Robot-Aided Gait Trainer
Caroline Laszlo1, Daniele Munari2, Serena Maggioni2
1Sensory-Motor Systems (SMS) Lab, ETH Zurich, 8006 Zurich, Switzerland.

Abstract:
Most robotic gait assisted devices are designed to provide constant assistance during the training without taking into account each patient's functional ability. The Lokomat offers an assist-as-needed control via the integrated exercise "Adaptive Gait Support" (AGS), which adapts the robotic support based on the patient's abilities. The aims of this study were to examine the feasibility and characteristics of the AGS during long-term application. Ten patients suffering from neurological diseases underwent an 8-week Lokomat training with the AGS. They additionally performed conventional walking tests and a robotic force measurement. The difference between robotic support during adaptive and conventional training and the relationship between the robotic assessment and the conventional walking and force tests were examined. The results show that AGS is feasible during long-term application in a heterogeneous population. The support during AGS training in most of the gait phases was significantly lower than during conventional Lokomat training. A relationship between the robotic support level determined by the AGS and conventional walking tests was revealed. Moreover, combining the isometric force data and AGS data could divide patients into clusters, based on their ability to generate high forces and their level of motor control. AGS shows a high potential in assessing patients' walking ability, as well as in providing challenging training, e.g., by automatically adjusting the robotic support throughout the whole gait cycle and enabling training at lower robotic support.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 06:00
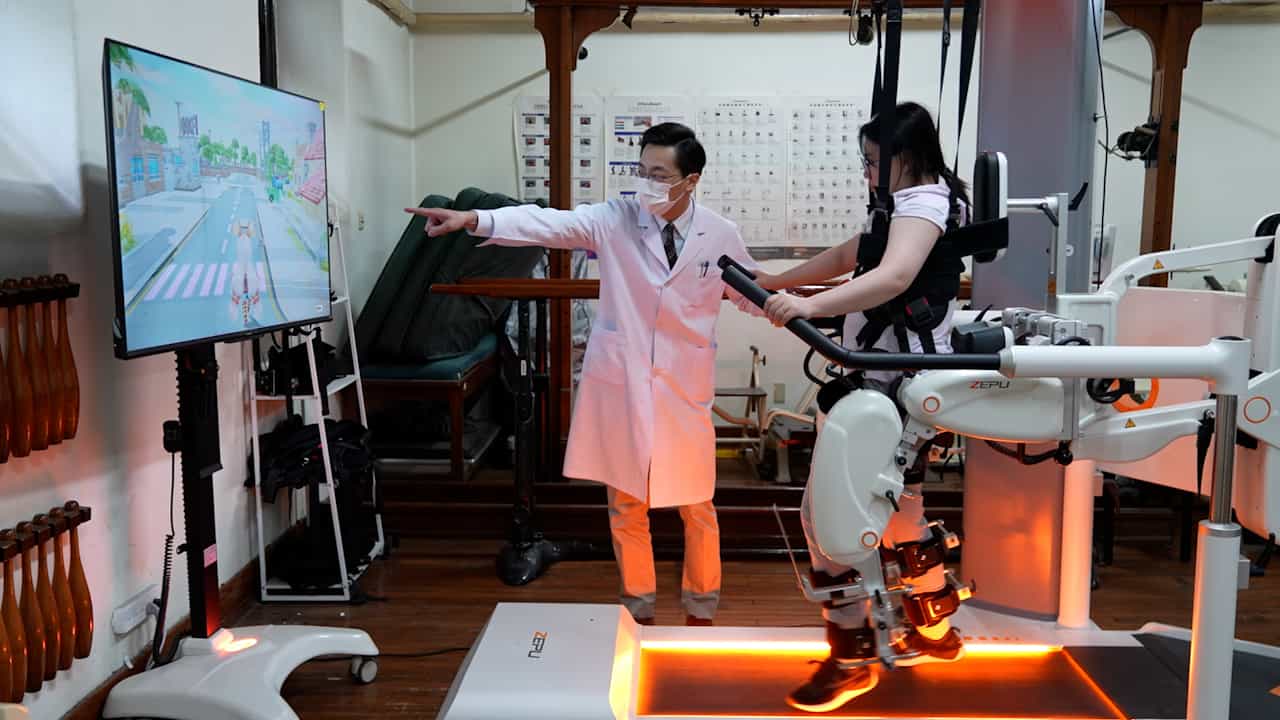
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025