Related Experiment Video
Updated: Jul 30, 2025
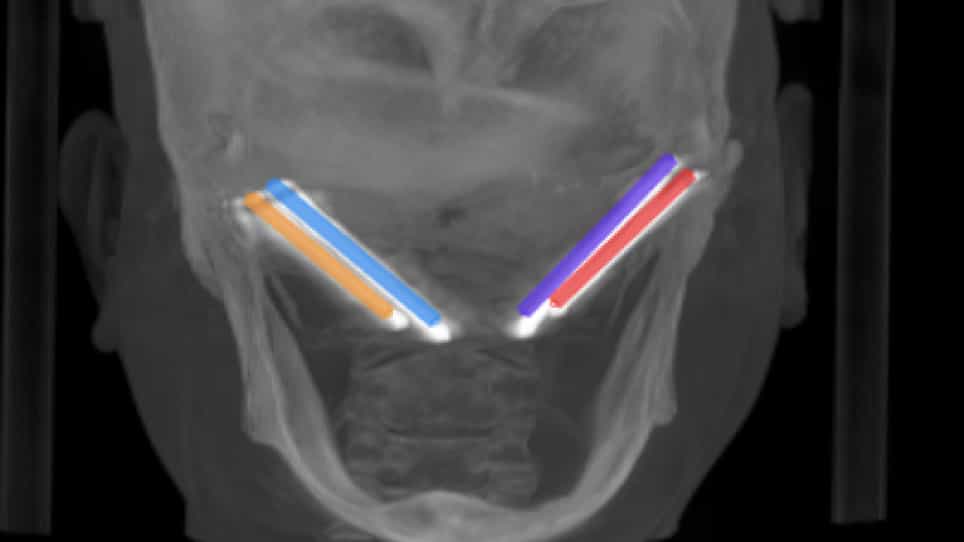
Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Accuracy of implant site preparation in robotic navigated dental implant surgery
Thu Ya Linn1, Eisner Salamanca1, Lwin Moe Aung1
1School of Dentistry, College of Oral Medicine, Taipei Medical University, Taipei, Taiwan.

Background:
Modern technological advancements have led to increase in the development of surgical robots in dentistry, resulting in excellent clinical treatment outcomes.
Purpose:
This study aimed to determine the accuracy of automatic robotic implant site preparation for different implant sizes by correlating planned and posttreatment positions, and to compare the performance of robotic and human freehand drilling.
Method:
Seventy-six drilling sites on partially edentulous models were used, with three different implant sizes (Ø = 3.5 × 10 mm, 4.0 × 10 mm, 5.0 × 10 mm). The robotic procedure was performed using software for calibration and step-by-step drilling processes. After robotic drilling, deviations in the implant position from the planned position were determined. The angulation, depth, and coronal and apical diameters on the sagittal plane of sockets created by human and robotic drilling were measured.
Results:
The deviation of the robotic system was 3.78° ± 1.97° (angulation), 0.58 ± 0.36 mm (entry point), and 0.99 ± 0.56 mm (apical point). Comparison of implant groups showed the largest deviation from the planned position for 5 mm implants. On the sagittal plane, there were no significant differences between robotic and human surgery except for the 5-mm implant angulation, indicating similar quality between human and robotic drilling. Based on standard implant measurements, robotic drilling exhibited comparable performance to freehand human drilling.
Conclusions:
A robotic surgical system can provide the greatest accuracy and reliability regarding the preoperative plan for small implant diameters. In addition, the accuracy of robotic drilling for anterior implant surgery can also be comparable to that of human drilling.