Related Experiment Video
Updated: Jul 29, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
The Topological State Derivative: An Optimal Control Perspective on Topology Optimisation
Phillip Baumann1, Idriss Mazari-Fouquer2, Kevin Sturm1
1TU Wien, Wiedner Hauptstr. 8-10, 1040 Vienna, Austria.

Abstract:
In this paper, we introduce the topological state derivative for general topological dilatations and explore its relation to standard optimal control theory. We show that for a class of partial differential equations, the shape-dependent state variable can be differentiated with respect to the topology, thus leading to a linearised system resembling those occurring in standard optimal control problems. However, a lot of care has to be taken when handling the regularity of the solutions of this linearised system. In fact, we should expect different notions of (very) weak solutions, depending on whether the main part of the operator or its lower order terms are being perturbed. We also study the relationship with the topological state derivative, usually obtained through classical topological expansions involving boundary layer correctors. A feature of the topological state derivative is that it can either be derived via Stampacchia-type regularity estimates or alternately with classical asymptotic expansions. It should be noted that our approach is flexible enough to cover more than the usual case of point perturbations of the domain. In particular, and in the line of (Delfour in SIAM J Control Optim 60(1):22-47, 2022; J Convex Anal 25(3):957-982, 2018), we deal with more general dilatations of shapes, thereby yielding topological derivatives with respect to curves, surfaces or hypersurfaces. To draw the connection to usual topological derivatives, which are typically expressed with an adjoint equation, we show how usual first-order topological derivatives of shape functionals can be easily computed using the topological state derivative.
More Related Videos
 11:53
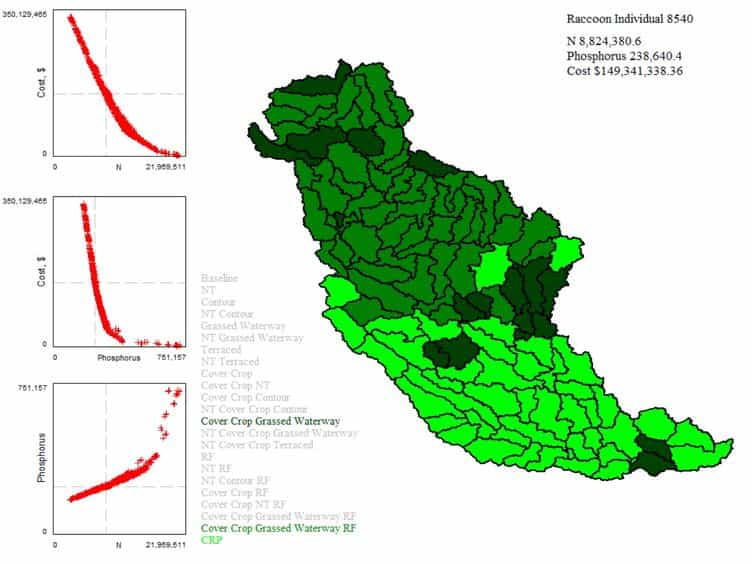
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
 06:24
Generic Protocol for Optimization of Heterologous Protein Production Using Automated Microbioreactor Technology
Published on: December 15, 2017
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
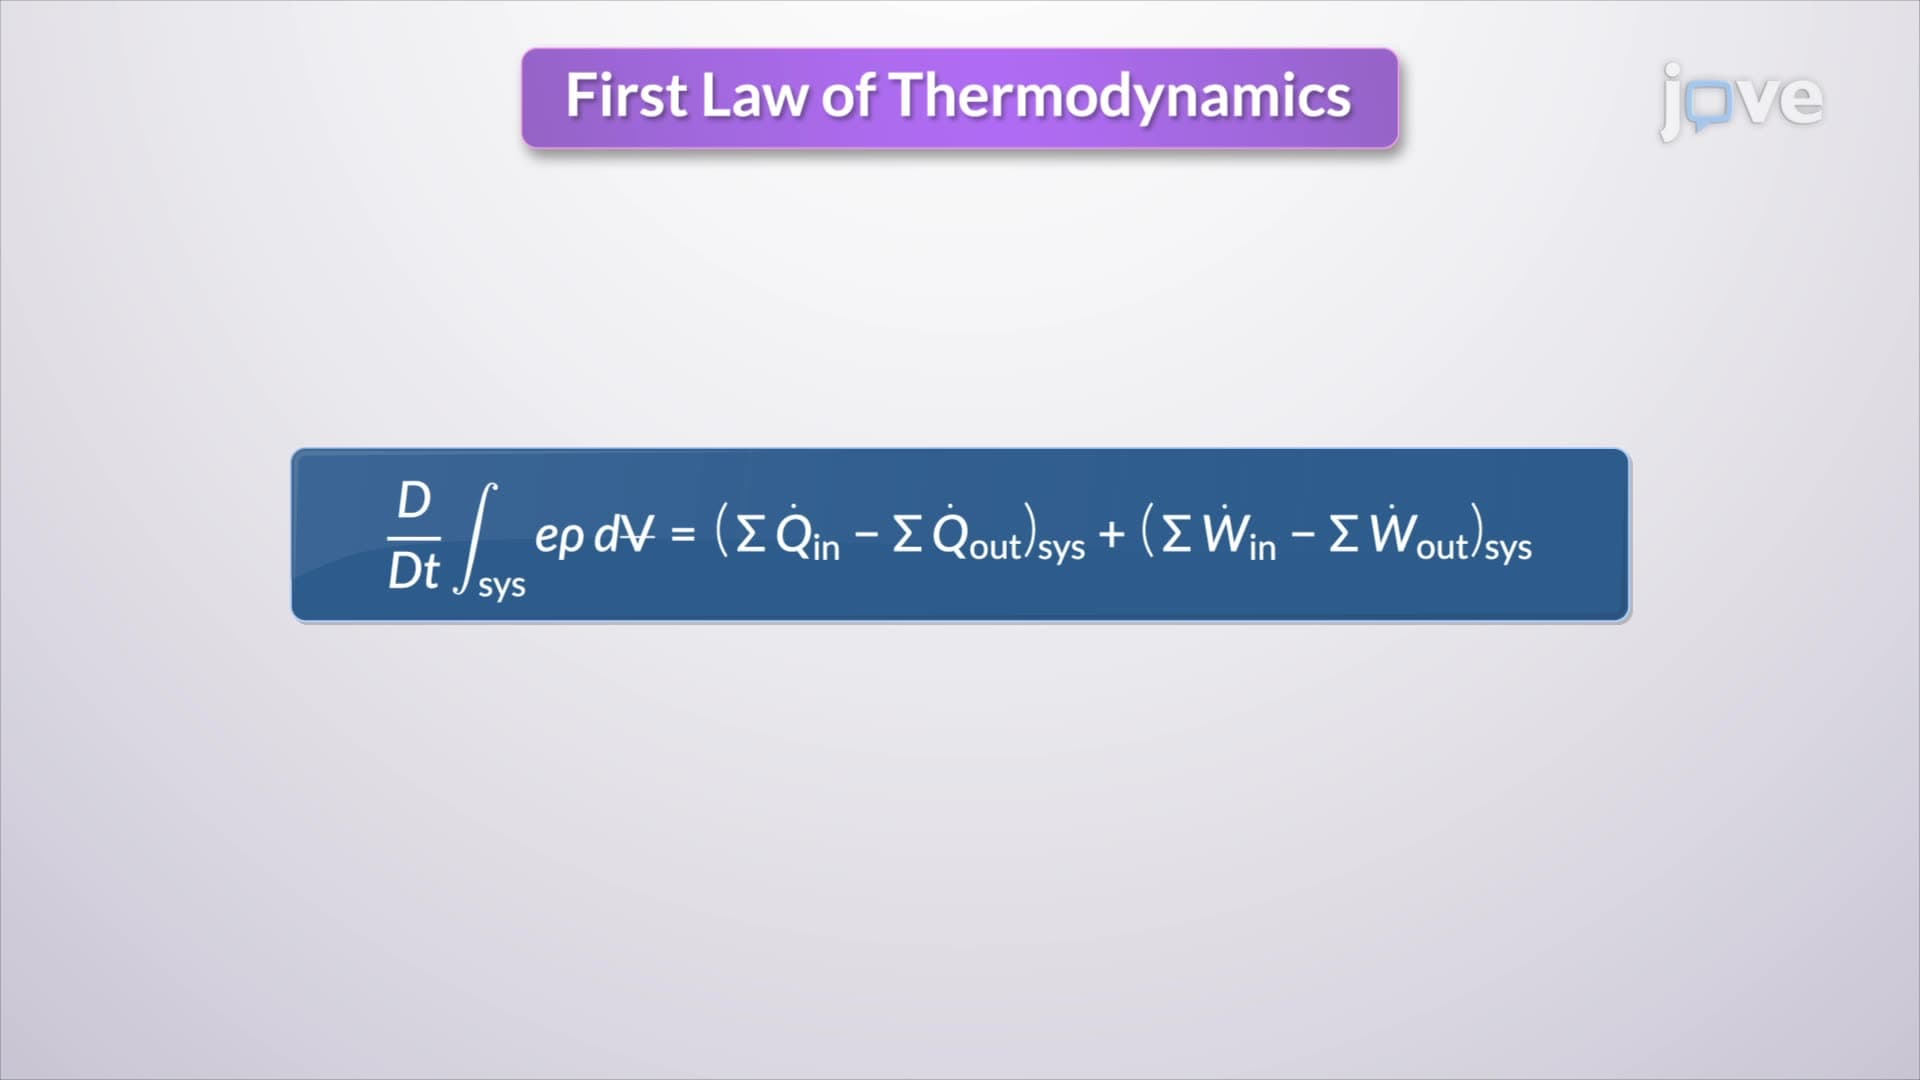
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:07
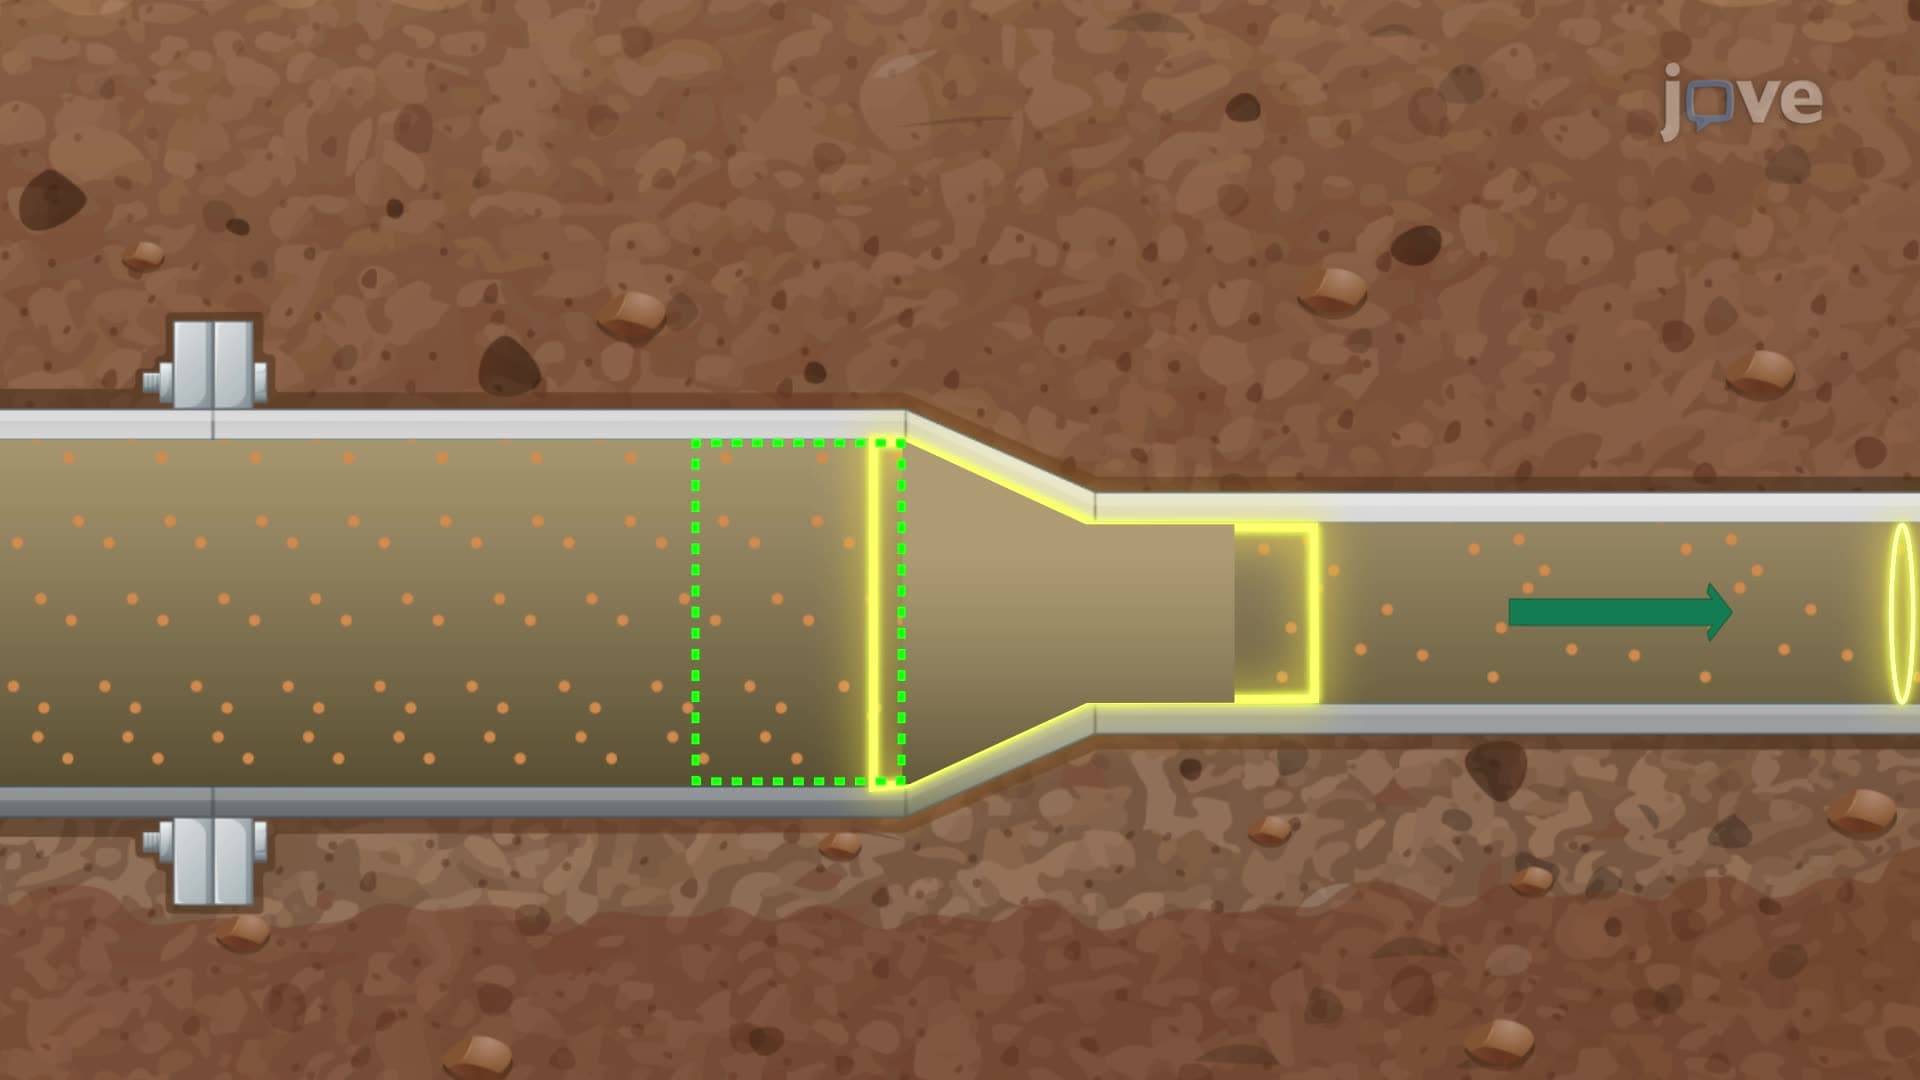
Conservation of Mass in Fixed, Nondeforming Control Volume
In the case of a sewer pipe, which can be modeled...