Multimaterial Embedded 3D Printing of Composite Reinforced Soft Actuators
Related Experiment Video
Updated: Jul 29, 2025
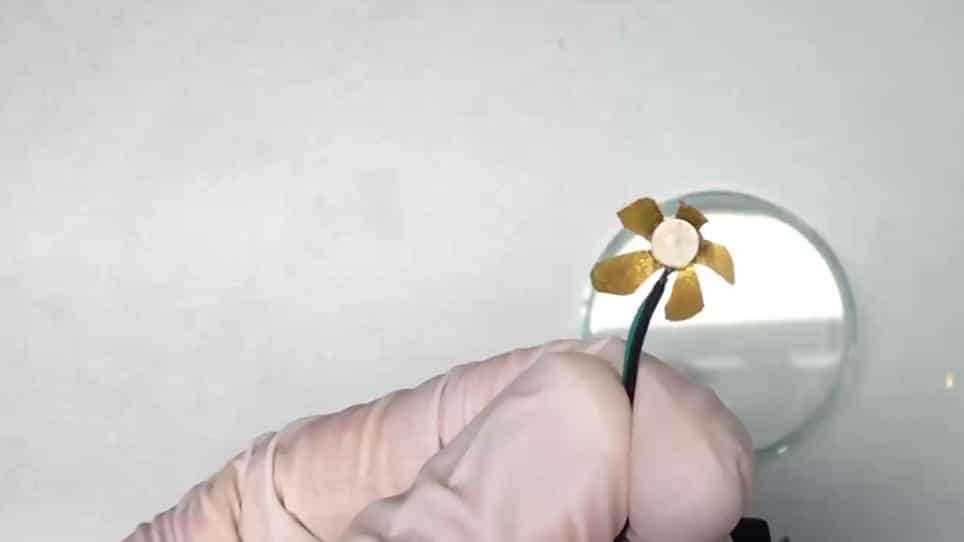
Fabrication of Carbon-Based Ionic Electromechanically Active Soft Actuators
Published on: April 25, 2020
Zhenhua Wang1,2, Boyu Zhang2,3, Qu He1,2
1Key Laboratory of Coastal Environment and Resources of Zhejiang Province, School of Engineering, Westlake University, Hangzhou, Zhejiang Province, China.

Abstract:
Soft pneumatic actuators (SPAs) have attracted enormous attention in the growing field of robotics. Among different SPAs, composite reinforced actuators (CRAs) are widely used because of their simple structure and high controllability. However, multistep molding, a time-consuming method, is still the predominant fabrication method. Here, we propose a multimaterial embedded printing method (ME3P) to fabricate CRAs. In comparison with other 3-dimensional printing methods, our method improves fabrication flexibility greatly. Via the design and fabrication of the reinforced composites' patterns and different geometries of the soft body, we demonstrate actuators with programmable responses (elongation, contraction, twisting, bending, and helical and omnidirectional bending). Finite element analysis is employed for the prediction of pneumatic responses and the inverse design of actuators based on specific actuation needs. Lastly, we use tube-crawling robots as a model system to demonstrate our ability to fabricate complex soft robots for practical applications. This work demonstrates the versatility of ME3P for the future manufacturing of CRA-based soft robots.