Related Experiment Video
Updated: Jul 29, 2025
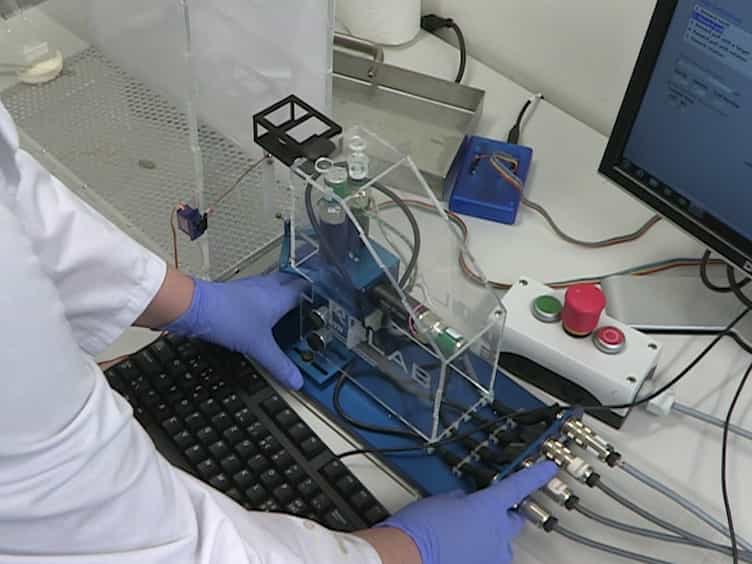

Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Utilizing Simulation to Evaluate Robotic Skill Acquisition and Learning Decay
Shinban Liu1,2, Kayla Watkins1,3, Caroline E Hall1
1Department of Surgery, Emory University.

Background:
We aim to evaluate how new robotic skills are acquired and retained by having participants train and retest using exercises on the robotic platform. We hypothesized that participants with a 3-month break from the robotic platform will have less learning decay and increased retention compared with those with a 6-month break.
Methods:
This was a prospective randomized trial in which participants voluntarily enrolled and completed an initial training phase to reach proficiency in 9 robot simulator exercises. They were then instructed to refrain from practicing until they retested either 3 or 6 months later. This study was completed at an academic medical center within the general surgery department. Participants were medical students, and junior-level residents with minimal experience in robotic surgery were enrolled. A total of 27 enrolled, and 13 participants completed the study due to attrition.
Results:
Overall, intragroup analysis revealed that participants performed better in their retest phase compared with their initial training in terms of attempts to reach proficiency, time for completion, penalty score, and overall score. Specifically, during the first attempt in the retesting phase, the 3-month group did not deviate far from their final attempt in the training phase, whereas the 6-month group experienced significantly worse time to complete and overall score in interrupted suturing {[-4 (-18 to 20) seconds vs. 109 (55 to 118) seconds, P =0.02] [-1.3 (-8 to 1.9) vs. -18.9 (-19.5 to (-15.0)], P =0.04} and 3-arm relay {[3 (-4 to 23) seconds vs. 43 (30 to 50) seconds, P =0.02] [0.4 (-4.6 to 3.1) vs. -24.8 (-30.6 to (-20.3)], P =0.01] exercises. In addition, the 6-month group had a significant increase in penalty score in retesting compared with the 3-month group, which performed similarly to their training phase [3.3 (2.7 to 3.3) vs. 0 (-0.8 to 1.7), P =0.03].
Conclusions:
This study identified statistically significant differences in learning decay, skills retention, and proficiency between 3-month and 6-month retesting intervals on a robotic simulation platform.
Related Concept Videos
 01:12
Observational Learning
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:30
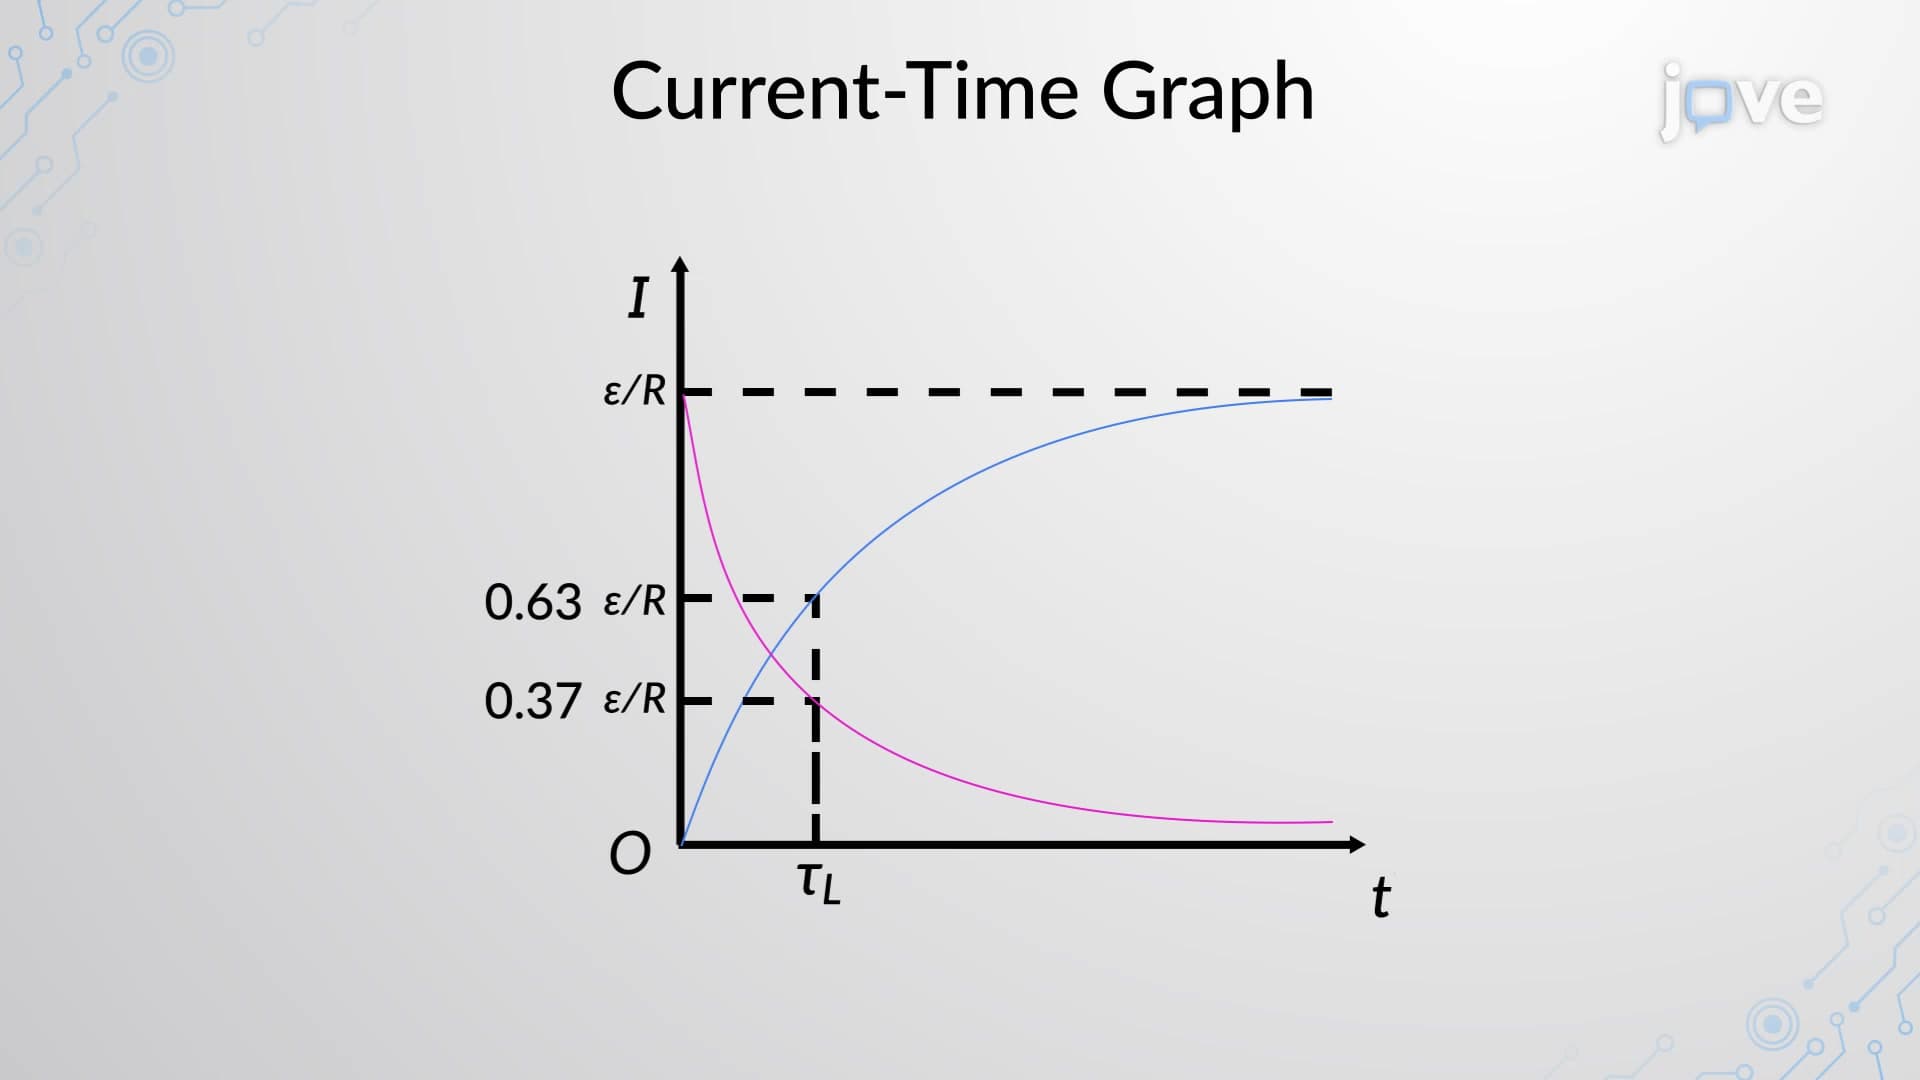
Current Growth And Decay In RL Circuits
 01:17
Rolling Resistance: Problem Solving
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...