Related Experiment Video
Updated: Jul 29, 2025
07:46

Setting Limits on Supersymmetry Using Simplified Models
Published on: November 15, 2013
8.6K
Erratum: Lyapunov Spectrum Scaling for Classical Many-Body Dynamics Close to Integrability [Phys. Rev. Lett. 128,
Physical Review Letters
|May 27, 2023

Abstract:
This corrects the article DOI: 10.1103/PhysRevLett.128.134102.
More Related Videos
 11:03
An Analog Macroscopic Technique for Studying Molecular Hydrodynamic Processes in Dense Gases and Liquids
Published on: December 4, 2017
8.6K
 07:31
Author Spotlight: Advancing Cell Membrane Biophysics - Exploring Interactions and Challenges Through Experimental and Computational Approaches
Published on: September 1, 2023
2.3K
Related Concept Videos
 01:21
Linear Approximation in Time Domain
109
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
109
 01:26
Linear Approximation in Frequency Domain
119
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
119
 01:22
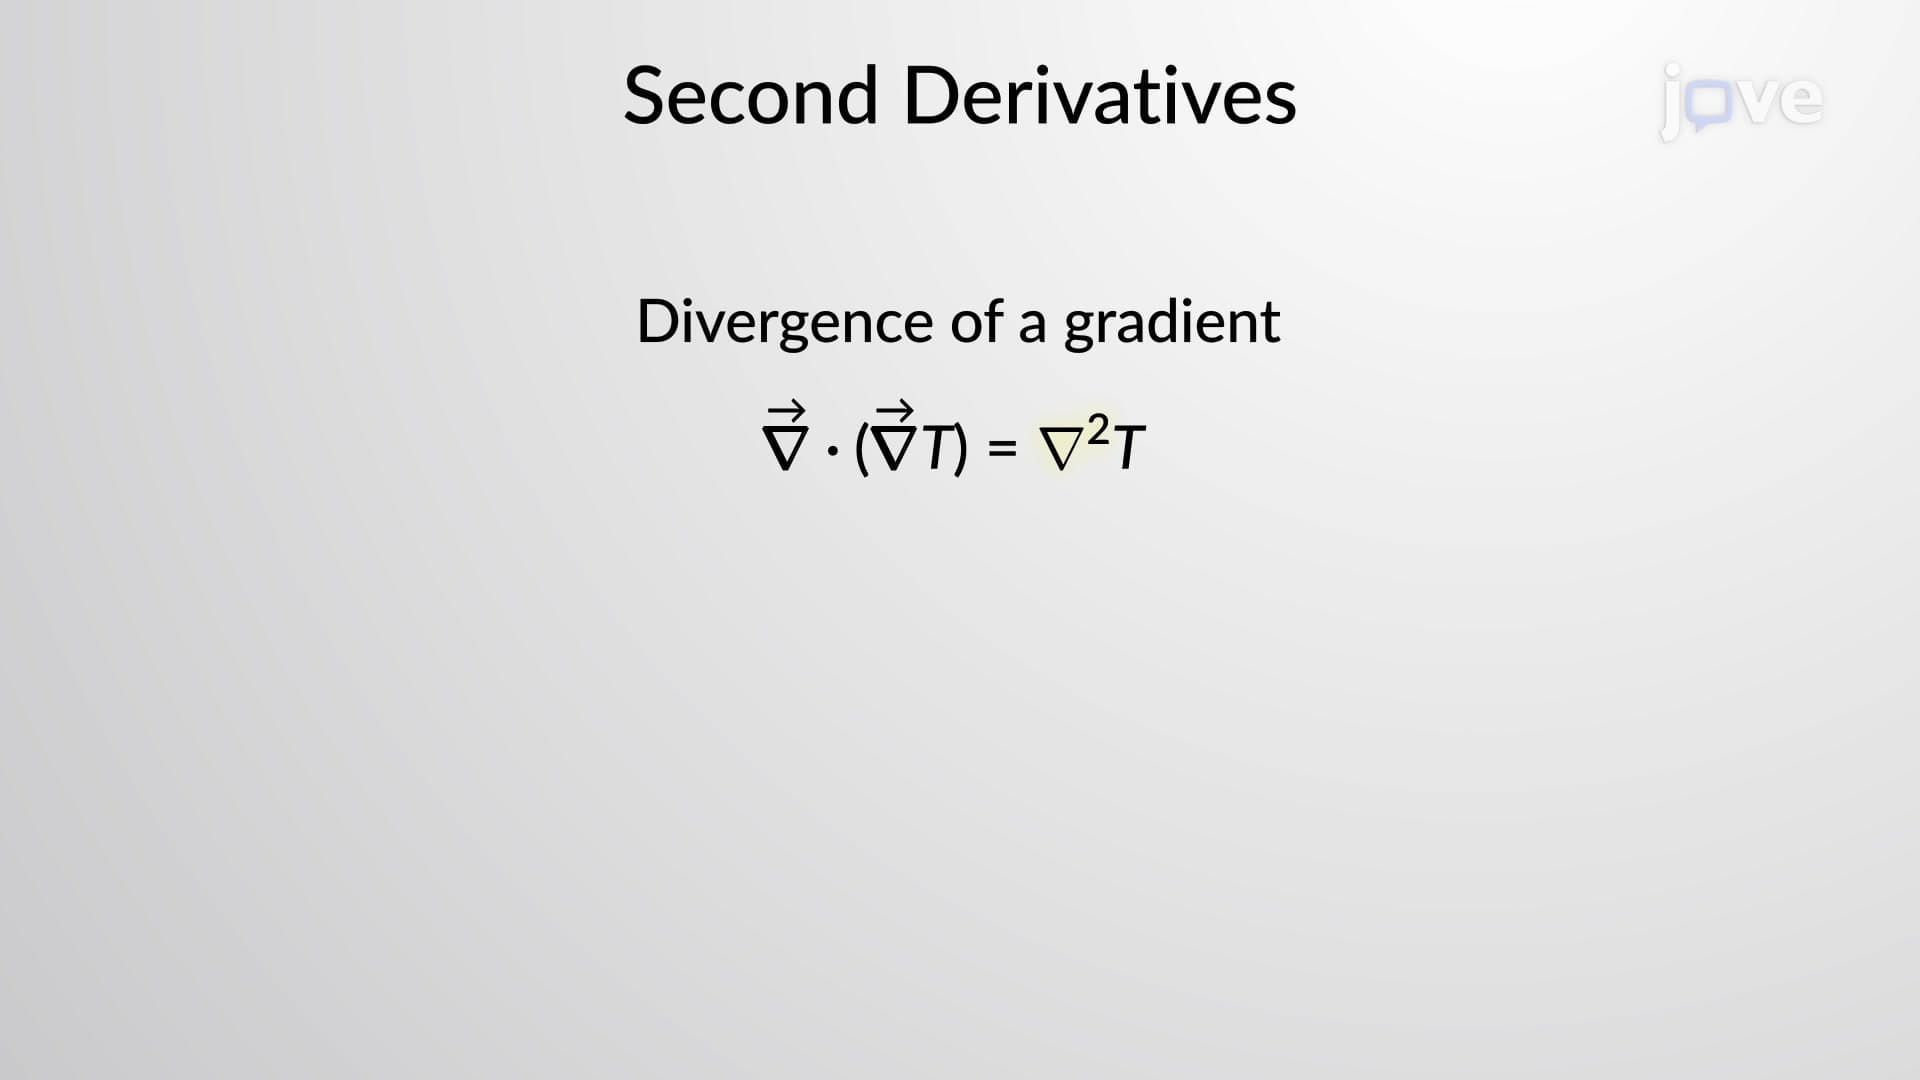
Second Derivatives and Laplace Operator
1.3K
The first order operators using the del operator include the gradient, divergence and curl. Certain combinations of first order operators on a scalar or vector function yield second order expressions. Second-order expressions play a very important role in mathematics and physics. Some second order expressions include the divergence and curl of a gradient function, the divergence and curl of a curl function, and the gradient of a divergence function.
Consider a scalar function. The curl of its...
Consider a scalar function. The curl of its...
1.3K
 01:20
Region of Convergence of Laplace Tarnsform
614
The Region of Convergence (ROC) is a fundamental concept in signal processing and system analysis, particularly associated with the Laplace transform. The ROC represents an area in the complex plane where the Laplace transform of a given signal converges, determining the transform's applicability and utility.
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This...
614
 01:23
Stability of Equilibrium Configuration
487
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
487
 01:18
Second Order systems II
138
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
138