Related Experiment Video
Updated: Jul 28, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Robust control of uncertain time-delay Markovian jump quaternion-valued neural networks subject to partially known
Jinlong Shu1, Baowei Wu1, Lianglin Xiong2
1School of Mathematics and Statistics, Shaanxi Normal University, Xi'an, 710119 China.

Abstract:
This paper addresses the issue of robust stochastic stabilization and control of uncertain time-delay Markovian jump quaternion-valued neural networks (MJQVNNs) subject to partially known transition probabilities. First, the direct quaternion method is proposed to analyse the MJQVNNs, which is different from some conventional methods in that the former is without any decomposition for systems. After that, in order to estimate the upper bound of the derivative of the constructed Lyapunov-Krasovskii functional (LKF) more accurately, the real-valued convex inequality is extended to quaternion domain. Then, by designed the mode-dependent state feedback controllers, the robust stochastic stabilization conditions of MJQVNNs are given for the admissible uncertainties, and reduce the influence of input disturbance on the controlled output to a specified performance level. Lastly, two numerical examples are given to illustrate the effectiveness of the proposed method.


Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:21
State Space to Transfer Function
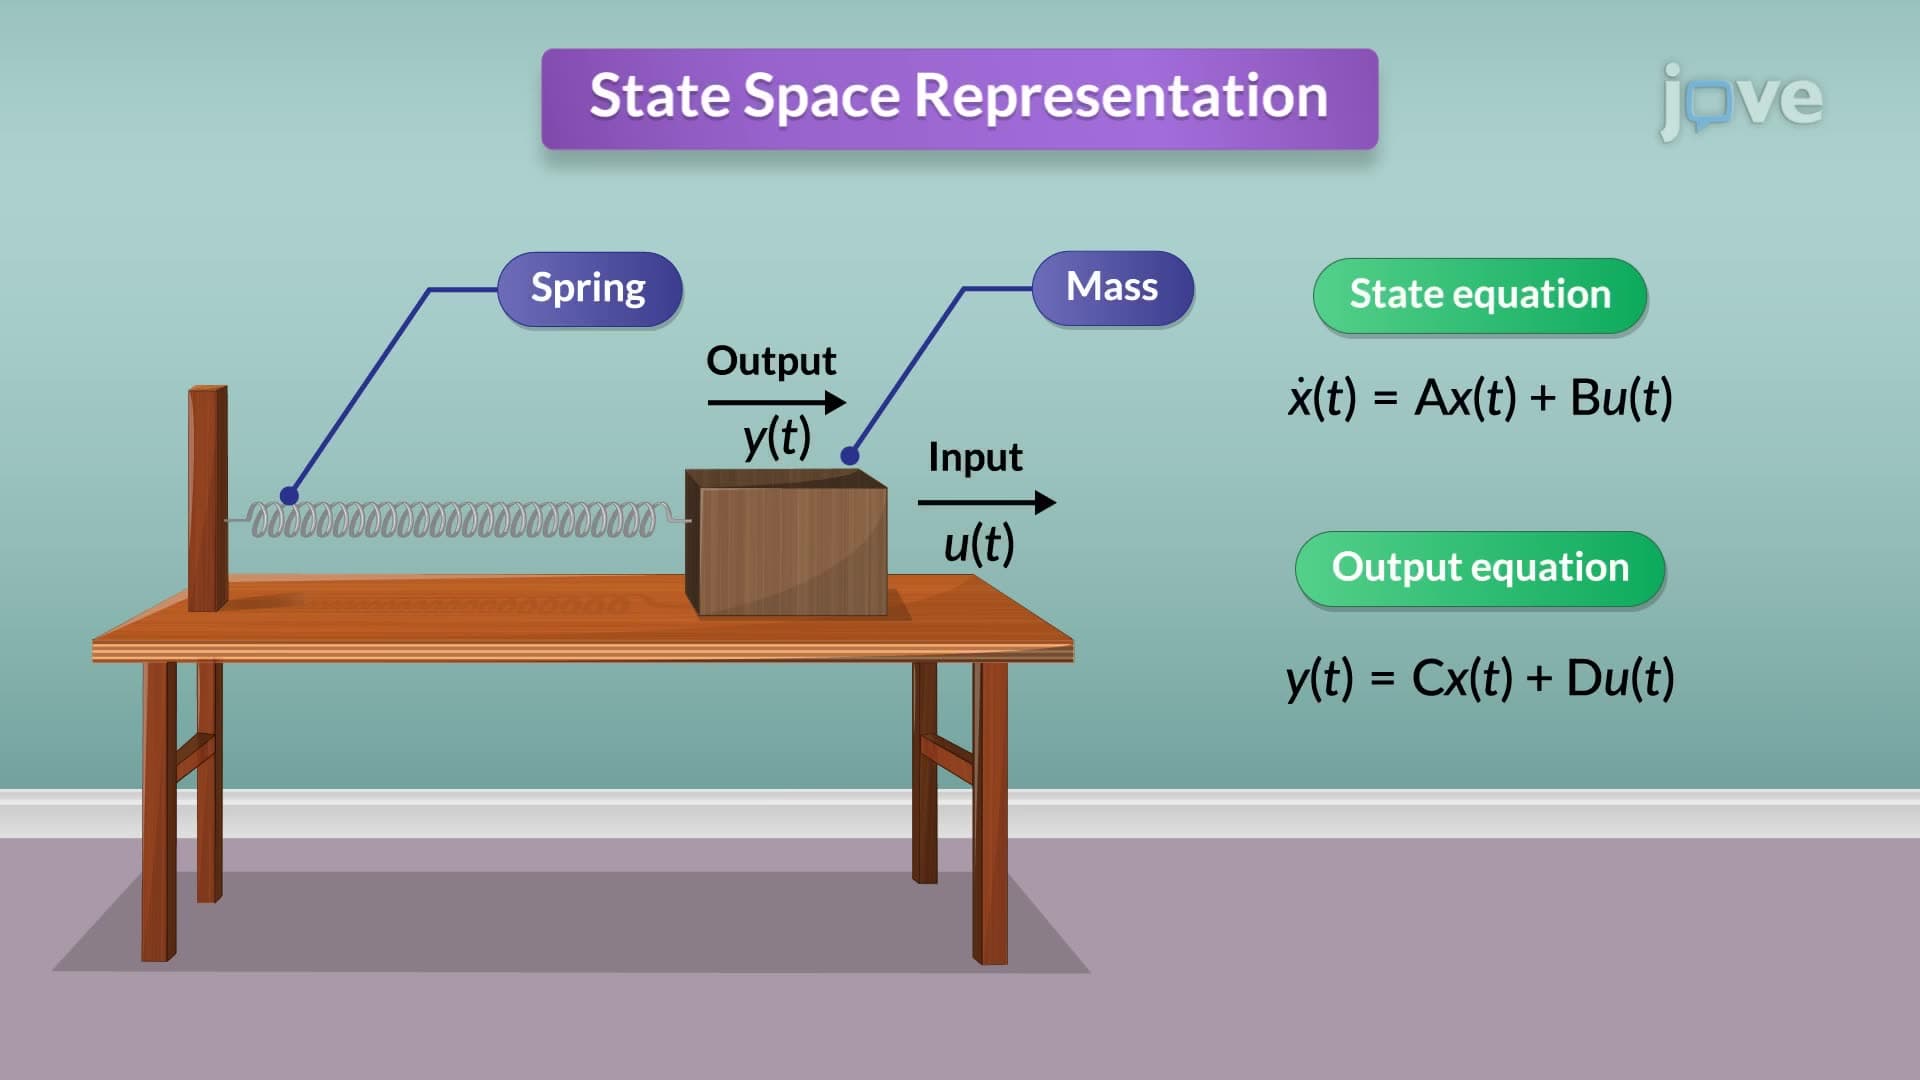
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...