Related Experiment Video
Updated: Jul 27, 2025
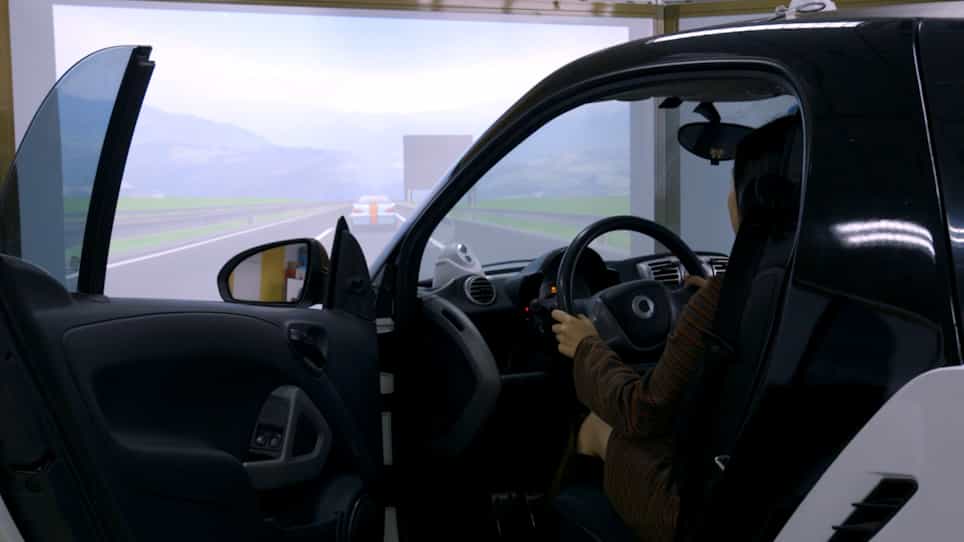
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Reliable and transparent in-vehicle agents lead to higher behavioral trust in conditionally automated driving systems
Skye Taylor1,2, Manhua Wang1, Myounghoon Jeon1
1Mind Music Machine Lab, Grado Department of Industrial and Systems Engineering, Virginia Tech, Blacksburg, VA, United States.

Abstract:
Trust is critical for human-automation collaboration, especially under safety-critical tasks such as driving. Providing explainable information on how the automation system reaches decisions and predictions can improve system transparency, which is believed to further facilitate driver trust and user evaluation of the automated vehicles. However, what the optimal level of transparency is and how the system communicates it to calibrate drivers' trust and improve their driving performance remain uncertain. Such uncertainty becomes even more unpredictable given that the system reliability remains dynamic due to current technological limitations. To address this issue in conditionally automated vehicles, a total of 30 participants were recruited in a driving simulator study and assigned to either a low or a high system reliability condition. They experienced two driving scenarios accompanied by two types of in-vehicle agents delivering information with different transparency types: "what"-then-wait (on-demand) and "what + why" (proactive). The on-demand agent provided some information about the upcoming event and delivered more information if prompted by the driver, whereas the proactive agent provided all information at once. Results indicated that the on-demand agent was more habitable, or naturalistic, to drivers and was perceived with faster system response speed compared to the proactive agent. Drivers under the high-reliability condition complied with the takeover request (TOR) more (if the agent was on-demand) and had shorter takeover times (in both agent conditions) compared to those under the low-reliability condition. These findings inspire how the automation system can deliver information to improve system transparency while adapting to system reliability and user evaluation, which further contributes to driver trust calibration and performance correction in future automated vehicles.
More Related Videos
 05:21
Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
 11:12
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Related Concept Videos
 01:25
Distribution Reliability and Automation
 02:16
Stereotype Content Model
 01:25
The Anchoring-and-Adjustment Heuristic
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:31
Confirmation Biases