Visual versus visual-inertial guidance in hawks pursuing terrestrial targets
Related Experiment Video
Updated: Jul 26, 2025
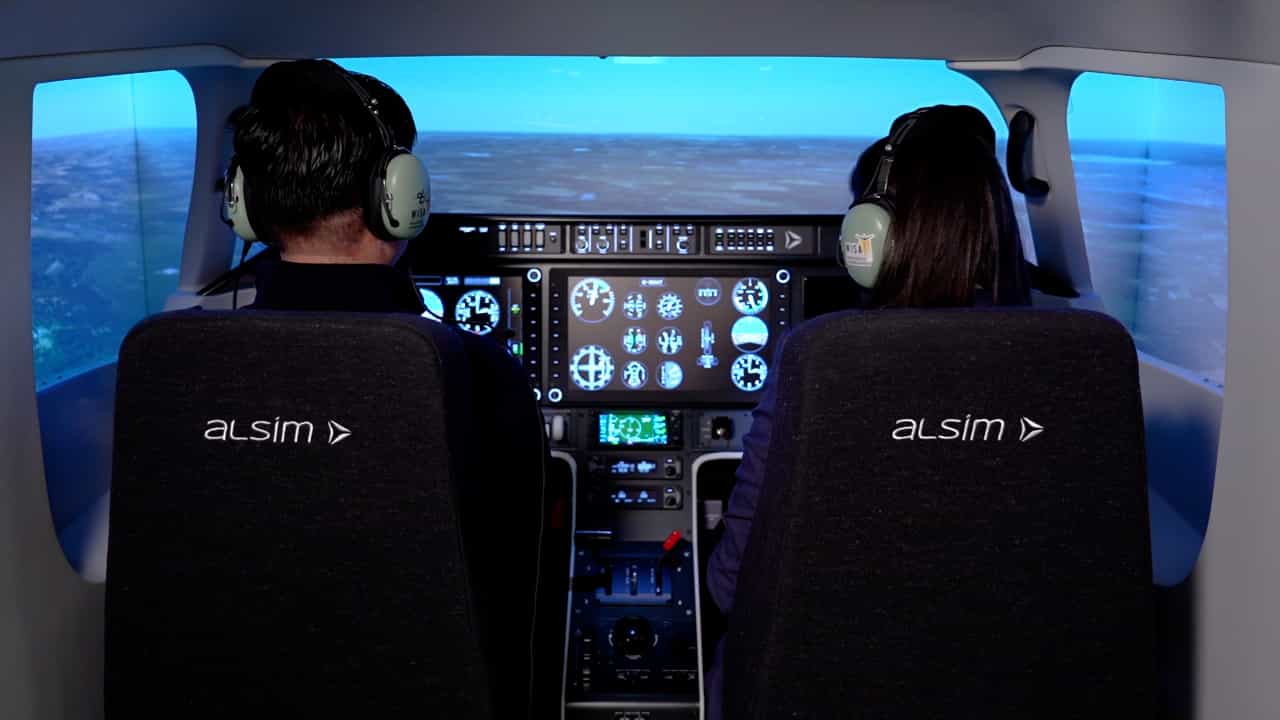
Eye Tracking During A Complex Aviation Task For Insights Into Information Processing
Published on: April 4, 2025
James A Kempton1, Caroline H Brighton1, Lydia A France1
1Department of Biology, University of Oxford, Oxford OX1 3SZ, UK.

Abstract:
The aerial interception behaviour of falcons is well modelled by a guidance law called proportional navigation, which commands steering at a rate proportional to the angular rate of the line-of-sight from predator to prey. Because the line-of-sight rate is defined in an inertial frame of reference, proportional navigation must be implemented using visual-inertial sensor fusion. By contrast, the aerial pursuit behaviour of hawks chasing terrestrial targets is better modelled by a mixed guidance law combining information on the line-of-sight rate with information on the deviation angle between the attacker's velocity and the line-of-sight. Here we ask whether this behaviour may be controlled using visual information alone. We use high-speed motion capture to record n = 228 flights from N = 4 Harris' hawks Parabuteo unicinctus, and show that proportional navigation and mixed guidance both model their trajectories well. The mixed guidance law also models the data closely when visual-inertial information on the line-of-sight rate is replaced by visual information on the motion of the target relative to its background. Although the visual-inertial form of the mixed guidance law provides the closest fit, all three guidance laws provide an adequate phenomenological model of the behavioural data, whilst making different predictions on the physiological pathways involved.
More Related Videos
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...