Related Experiment Video
Updated: Jul 26, 2025

Experimental Protocol for Manipulating Plant-induced Soil Heterogeneity
Published on: March 13, 2014
Feasibility and stability in large Lotka Volterra systems with interaction structure
Xiaoyuan Liu1, George W A Constable1, Jonathan W Pitchford1
1Department of Mathematics, University of York, York, YO10 5DD, United Kingdom.

Abstract:
Complex system stability can be studied via linear stability analysis using random matrix theory (RMT) or via feasibility (requiring positive equilibrium abundances). Both approaches highlight the importance of interaction structure. Here we show, analytically and numerically, how RMT and feasibility approaches can be complementary. In generalized Lotka-Volterra (GLV) models with random interaction matrices, feasibility increases when predator-prey interactions increase; increasing competition/mutualism has the opposite effect. These changes have crucial impact on the stability of the GLV model.
More Related Videos
Related Concept Videos
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:23
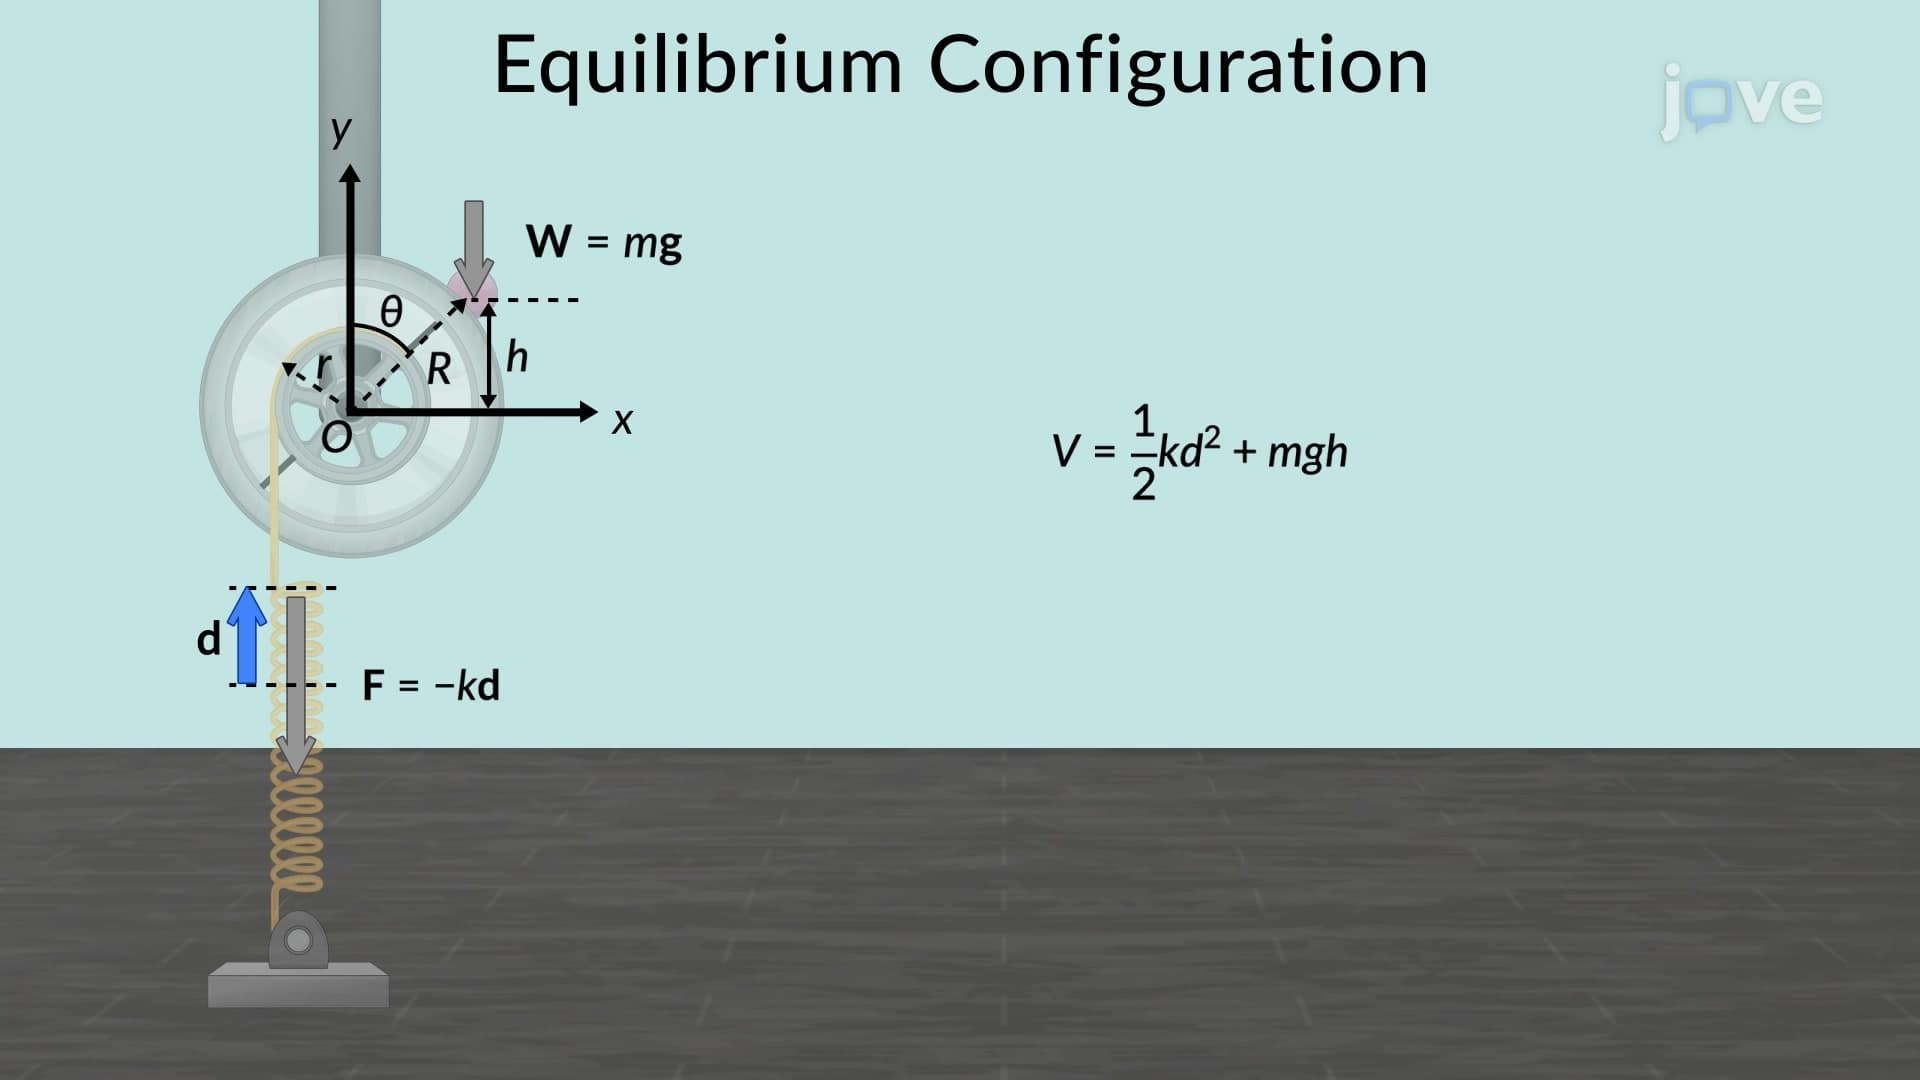
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....