Related Experiment Video
Updated: Jul 26, 2025

Errors as a Means of Reducing Impulsive Food Choice
Published on: June 5, 2016
Learning about Our Vices from Devices: A Model of Individual Learning with an Application to Consumer Food Waste
Danyi Qi1, Brian E Roe2, John W Apolzan3
1Dept. of Agricultural Economics & Agribusiness, Louisiana State University AgCenter.

Abstract:
The proliferation of personal, household and workplace sensors and devices has created individual environments rich with purposeful and incidental feedback capable of altering behavior. We formulate an empirical learning model suitable for understanding individual behavioral responses in such environments. We estimate this model using data collected about the joint personal decisions of food selection, intake, and waste during a study in which users photographed their meal selections and plate waste over the course of a week with a cell phone. Despite neutral recruitment language and no expectation that participants would alter food intake in response to the assessment procedures, we found a substantial learning-by-doing effect in plate waste reduction as those who document greater plate waste in their captured photographs waste less on subsequent days. Further we identified that participants reduced plate waste by learning to eat more rather than by learning to reduce the amount of food selected.
Related Concept Videos
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:06
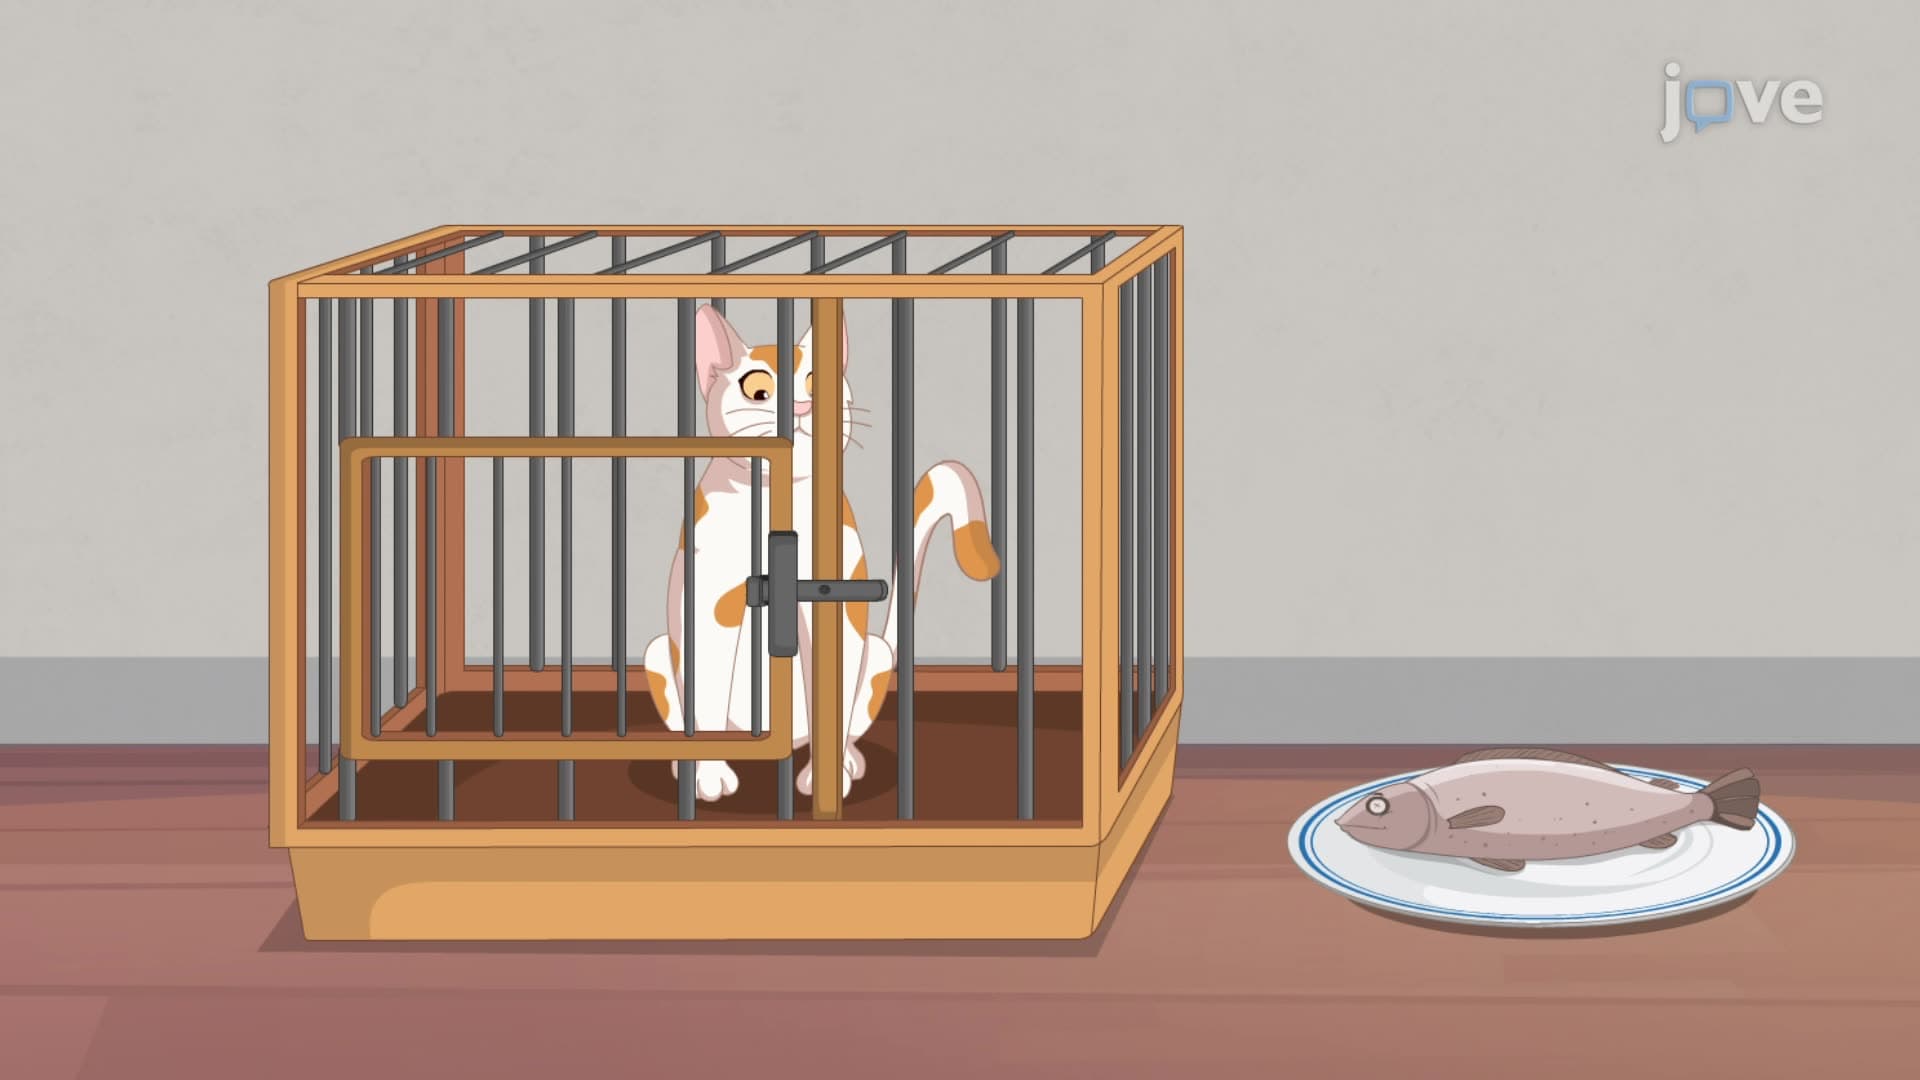
Law of Effect
Edward Thorndike's foundational work involved studying learning in animals, particularly using puzzle...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:12
Observational Learning
 01:23
Mechanistic Models: Compartment Models in Individual and Population Analysis