The Tobit-Unscented-Kalman-Filter-Based Attitude Estimation Algorithm Using the Star Sensor and Inertial Gyro Combination
Related Experiment Video
Updated: Jul 25, 2025
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Xinmei Wang1,2,3,4, Hui Zhang1,2,3, Xiaodong Gao1,2,3
1National Key Laboratory of Optical Field Manipulation Science and Technology, Chinese Academy of Sciences, Chengdu 610209, China.

Abstract:
For the orbit operation of spacecraft, due to environmental factors, a star sensor installed on the spacecraft must have data censoring, which greatly reduces the attitude determination ability of the traditional combined-attitude-determination algorithm. To address this problem, this paper proposes an algorithm for high-precision attitude estimation based on a Tobit unscented Kalman filter. This is on the basis of establishing the nonlinear state equation of the integrated star sensor and gyroscope navigation system. The measurement update process of the unscented Kalman filter is improved. The Tobit model is used to describe the gyroscope drift when the star sensor fails. The latent measurement values are calculated using the probability statistics, and the measurement error covariance expression is derived. The proposed design is verified via computer simulations. When the star sensor fails for 15 min, the accuracy of the Tobit unscented Kalman filter based on the Tobit model is improved by approximately 90% compared to the unscented Kalman filter. Based on the results, the proposed filter can effectively estimate the error caused by the gyro drift, and the method is effective and feasible, provided there is theoretical support for the engineering practice.

Related Concept Videos
 01:02
Gyroscope
 01:24
Gyroscope: Precession
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:19
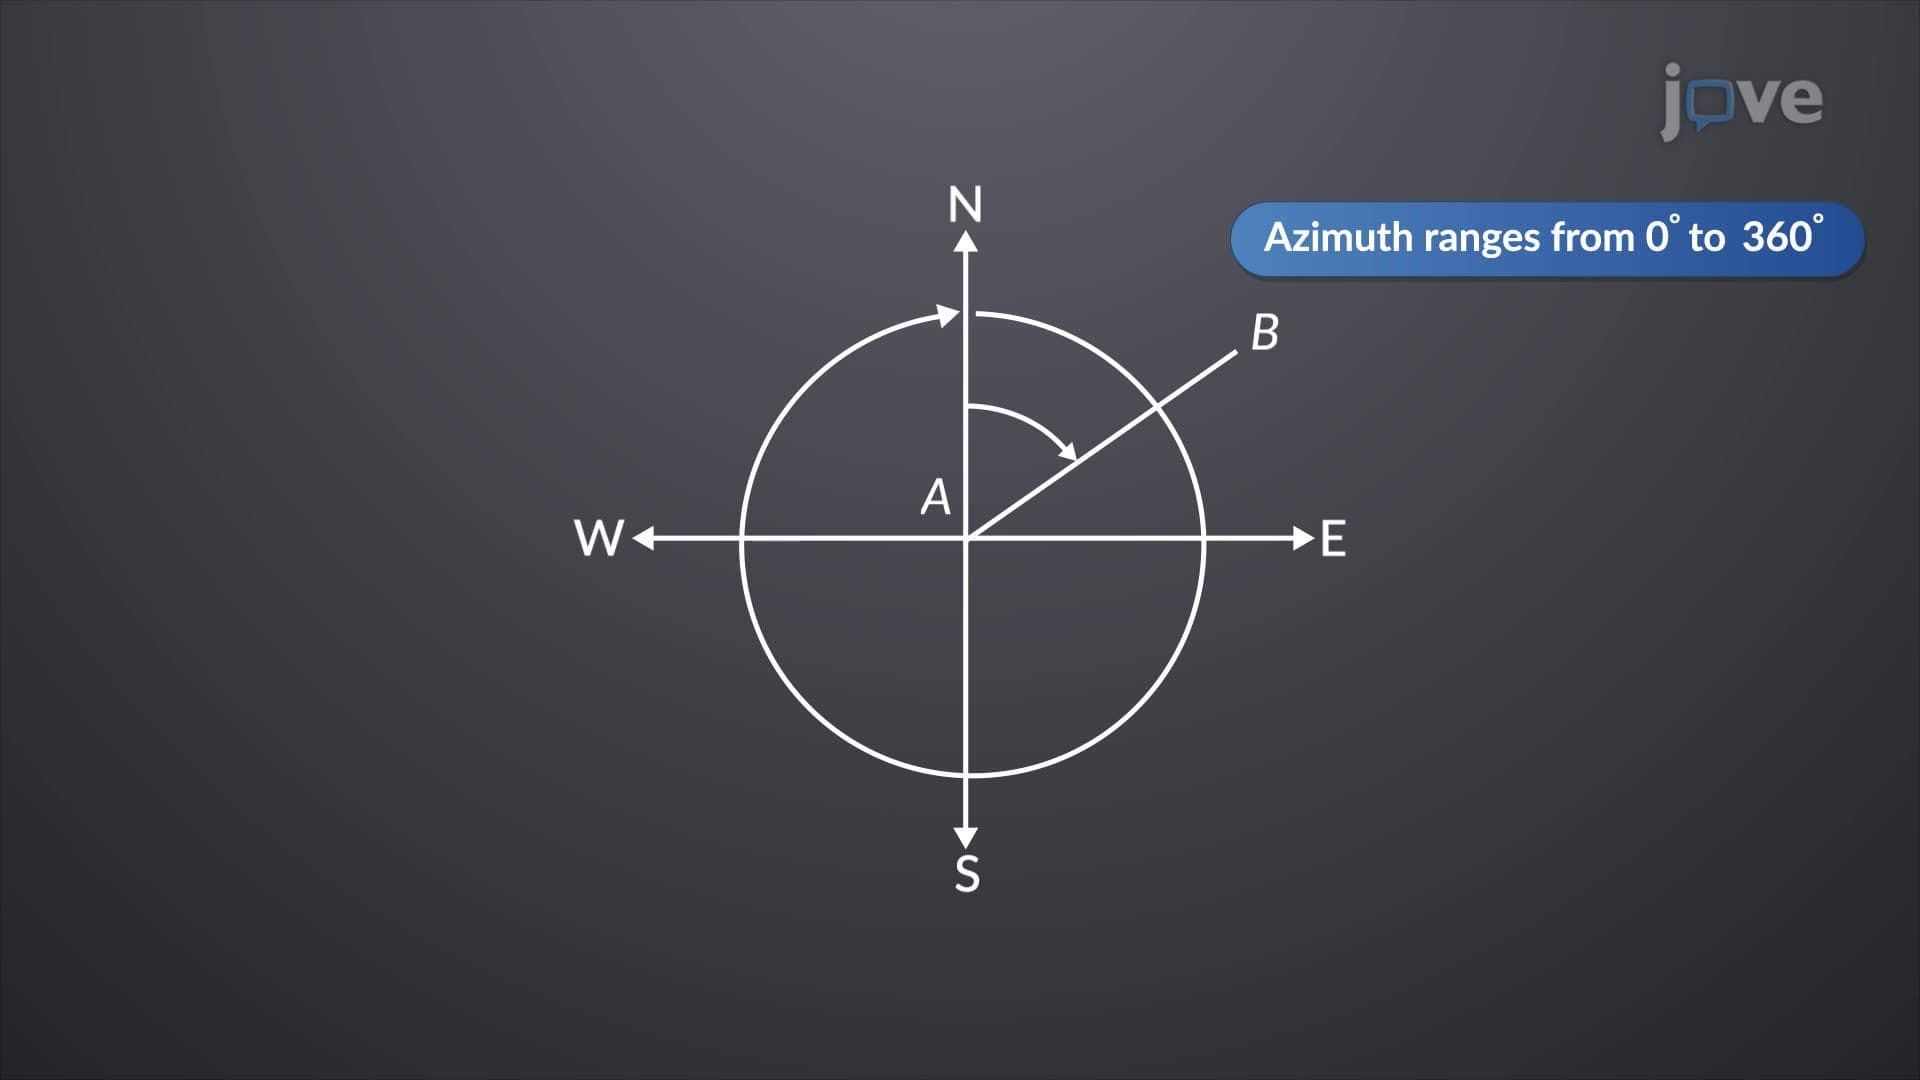
Azimuths and Bearings
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...