Related Experiment Video
Updated: Jul 25, 2025

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Computed torque control and force analysis for mechanical leg with variable rotation axis powered by servo pneumatic
Binrui Wang1, Youcao Wang1, Jiqing Huang1
1College of Mechanical and Electrical Engineering, China Jiliang University, Hangzhou 310018, China.

Abstract:
It is difficult for a humanoid leg driven by two groups of antagonistic pneumatic muscles (PMs) to achieve a flexible humanoid gait, and its inherent strong coupling nonlinear characteristics make it hard to achieve good tracking performance in a large range of motion. Therefore, a four-bar linkage bionic knee joint structure with a variable axis and a double closed-loop servo position control strategy based on computed torque control are designed to improve anthropomorphic characteristics and the dynamic performance of the bionic mechanical leg powered by servo pneumatic muscle (SPM). Firstly, the relationship between the joint torque, the initial jump angle and the bounce height of the mechanical leg is established, and then we design a double-joint PM bionic mechanical leg containing a four-bar linkage mechanism of the knee joint. Secondly, a cascade position control strategy is developed, which consists of the outer position loop and the inner contraction force loop, and the mapping relationship is designed between joint torque and antagonistic PM contraction force. Finally, we further project bounce action timing of mechanical leg to realize the periodic jumping movement of the mechanical leg, and simulation and physical experiments of the real-style machine platform have been provided to demonstrate the effectiveness of the designed SPM controller.


Related Concept Videos
 01:10
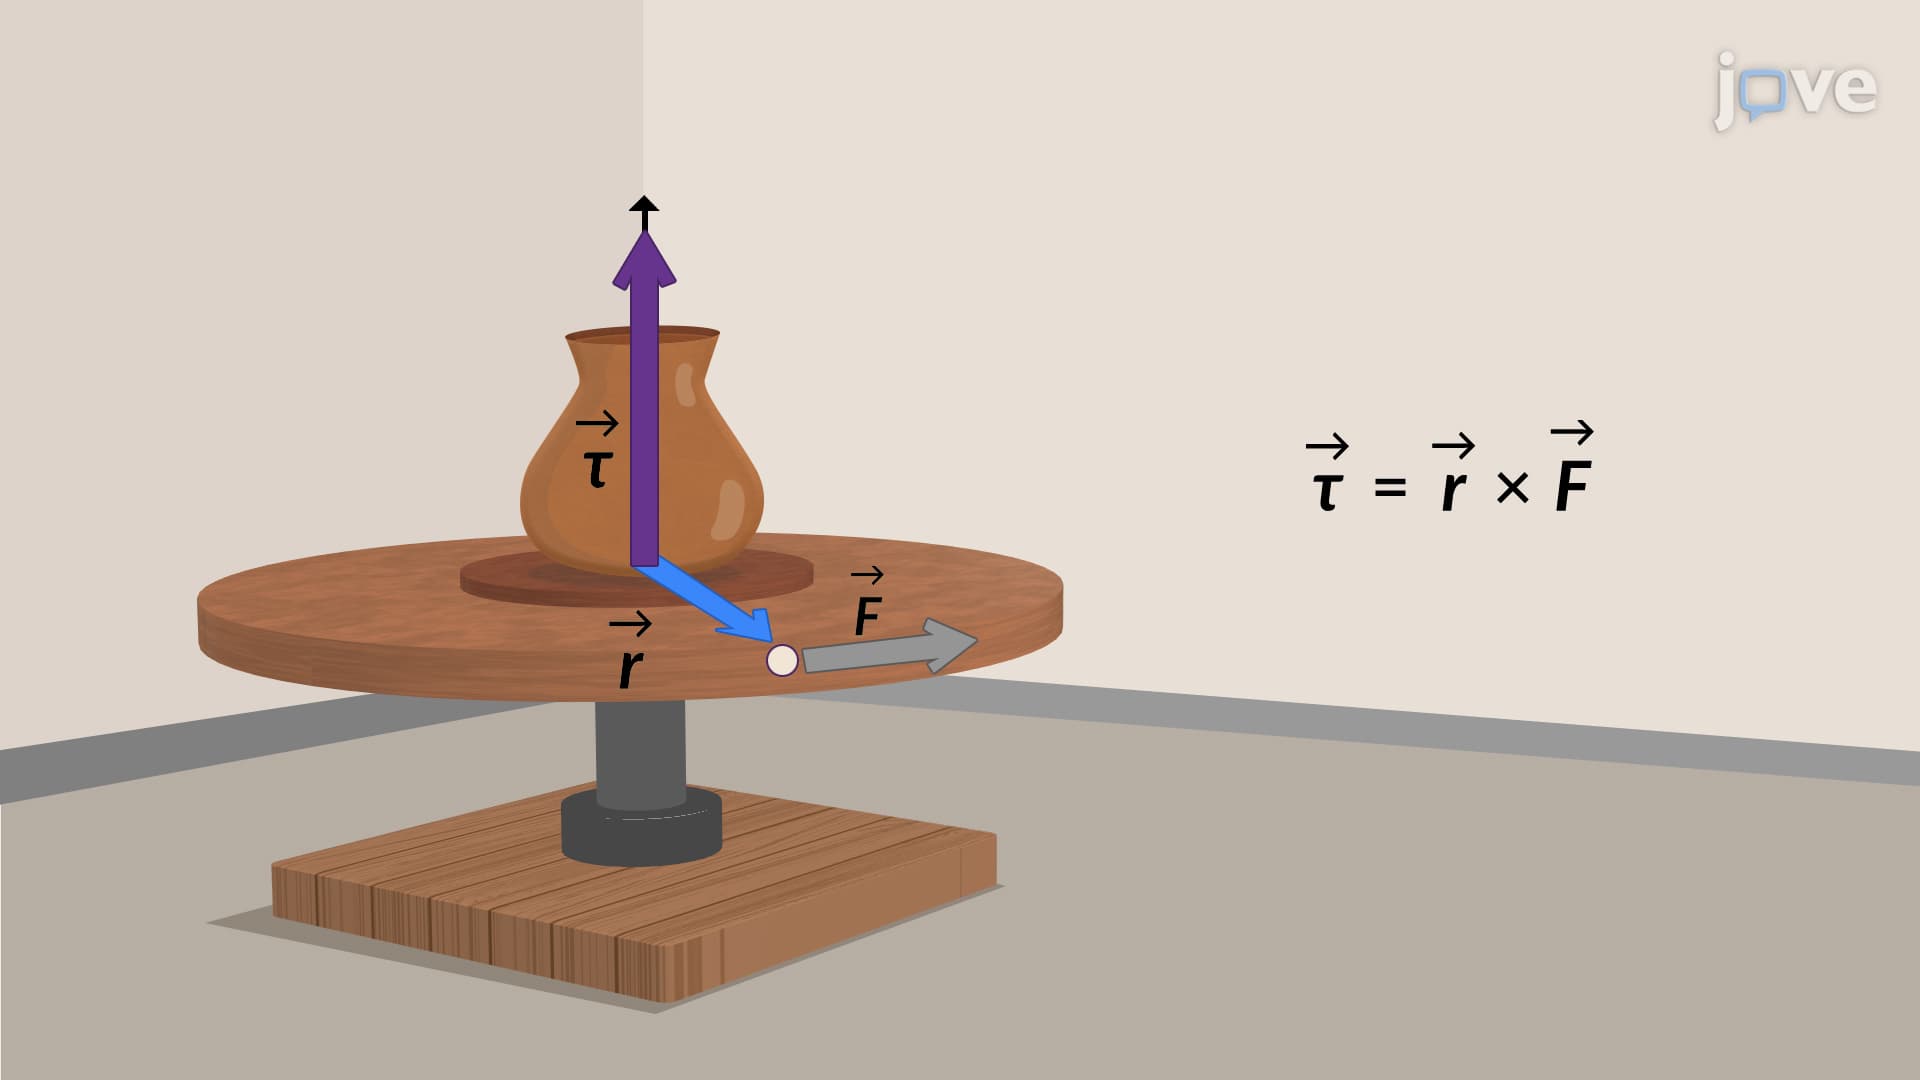
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:15
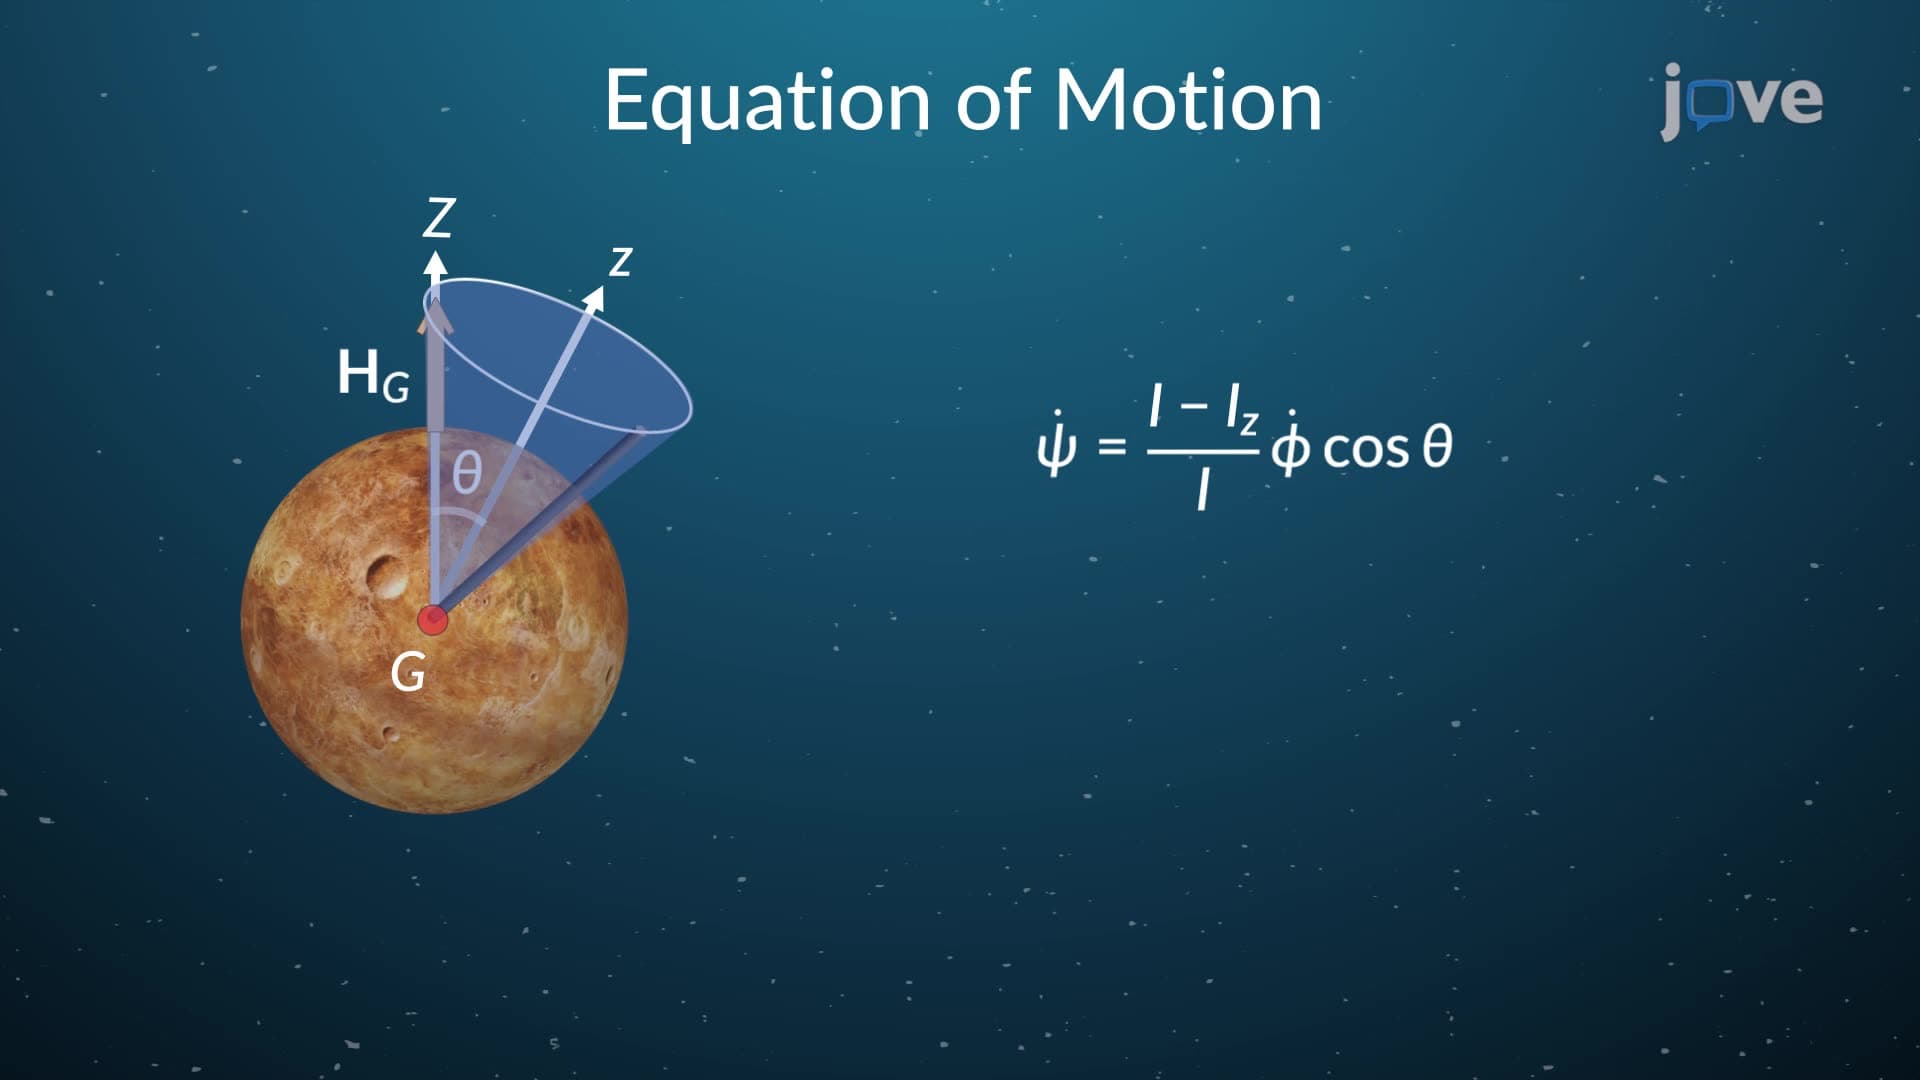
Torque Free Motion
 01:23
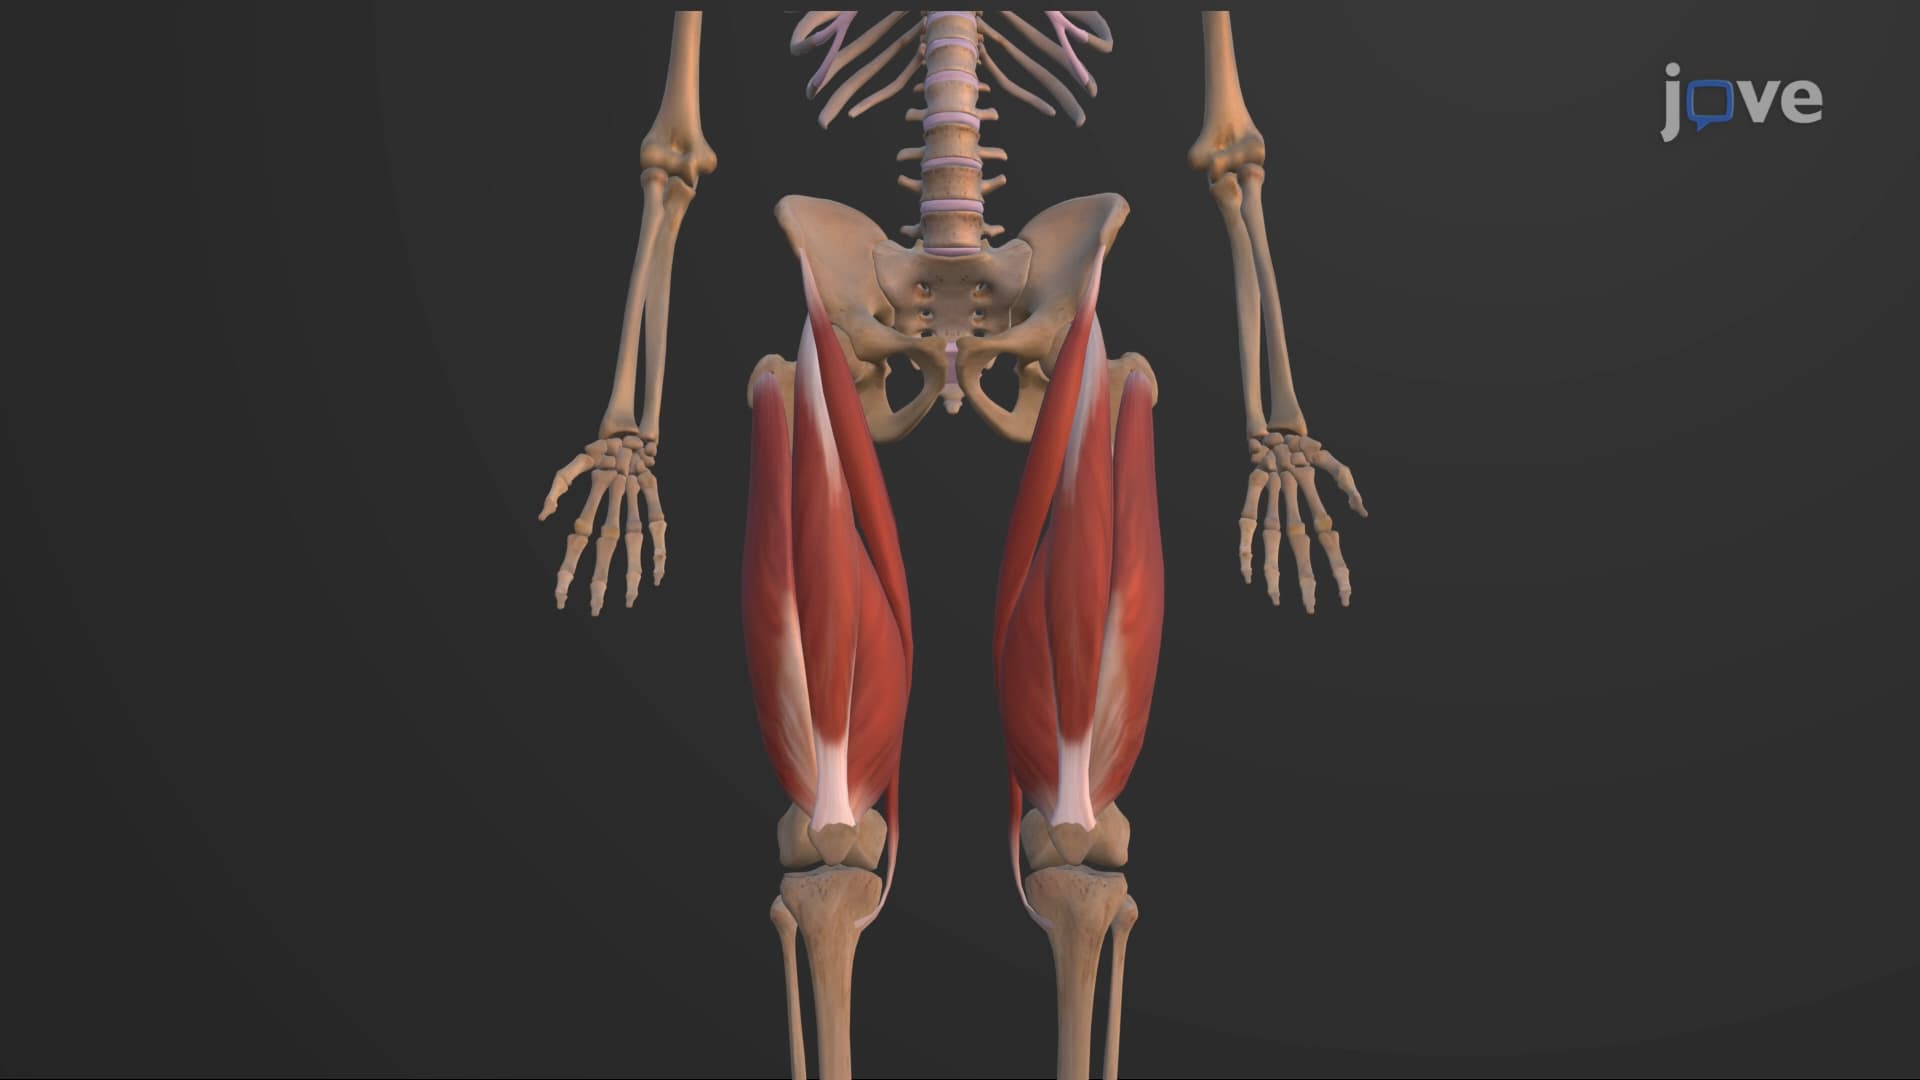
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:22
Mechanical Systems
 01:19
Net Torque Calculations
 00:57
Power Expended by a Constant Force