Related Experiment Video
Updated: Jul 24, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Road traffic safety assessment in self-driving vehicles based on time-to-collision with motion orientation
Fernando M Ortiz1, Matteo Sammarco2, Marcin Detyniecki2
1GTA/PEE/COPPE - Universidade Federal do Rio de Janeiro, Rio de Janeiro, Brazil.

Abstract:
Traffic conflict analysis based on Surrogate Safety Measures (SSMs) helps to estimate the risk level of an ego-vehicle interacting with other road users. Nonetheless, risk assessment for autonomous vehicles (AVs) is still incipient, given that most of the AVs are currently prototypes and current SSMs do not directly apply to autonomous driving styles. Therefore, to assess and quantify the potential risk arising from AV interactions with other road users, this study introduces the TTCmo (Time-to-Collision with motion orientation), a metric that considers the yaw angle of conflicting objects. In fact, the yaw angle represents the orientation of the other road users and objects detected by the AV sensors, enabling a better identification of potential risk events from changes in the motion orientation and position through the geometric analysis of the boundaries for each detected object. Using the 3D object detection data annotations available from the publicly available AV datasets nuScenes and Lyft5 and the TTCmo metric, we find that at least 8% of the interactions with objects detected around the AV present some risk level. This is meaningful, since it is possible to reduce the proportion of data analyzed by up to 60% when replacing regular TTC by our improved TTC computation.
More Related Videos
 11:41
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
 11:12
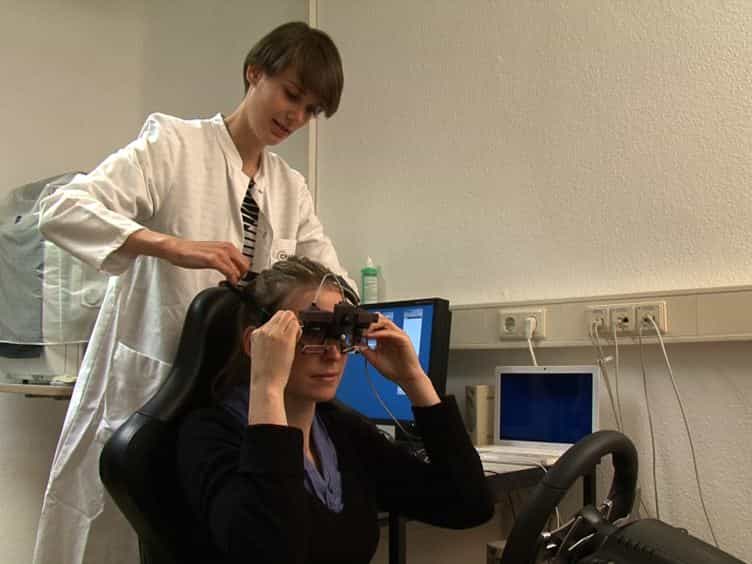
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...