Related Experiment Video
Updated: Jul 24, 2025


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Trajectory Tracking Coordinated Control of 4WID-4WIS Electric Vehicle Considering Energy Consumption Economy Based on
Yiran Qiao1, Xinbo Chen1, Zhen Liu1
1School of Automotive Studies, Tongji University, Shanghai 201804, China.

Abstract:
In order to improve the stability and economy of 4WID-4WIS (four-wheel independent drive-four-wheel independent steering) electric vehicles in trajectory tracking, this paper proposes a trajectory tracking coordinated control strategy considering energy consumption economy. First, a hierarchical chassis coordinated control architecture is designed, which includes target planning layer, and coordinated control layer. Then, the trajectory tracking control is decoupled based on the decentralized control structure. Expert PID and Model Predictive Control (MPC) are employed to realize longitudinal velocity tracking and lateral path tracking, respectively, which calculate generalized forces and moments. In addition, with the objective of optimal overall efficiency, the optimal torque distribution for each wheel is achieved using the Mutant Particle Swarm Optimization (MPSO) algorithm. Additionally, the modified Ackermann theory is used to distribute wheel angles. Finally, the control strategy is simulated and verified using Simulink. Comparing the control results of the average distribution strategy and the wheel load distribution strategy, it can be concluded that the proposed coordinated control not only provides good trajectory tracking but also greatly improves the overall efficiency of the motor operating points, which enhances the energy economy and realizes the multi-objective coordinated control of the chassis.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 08:55
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Related Concept Videos
 01:14
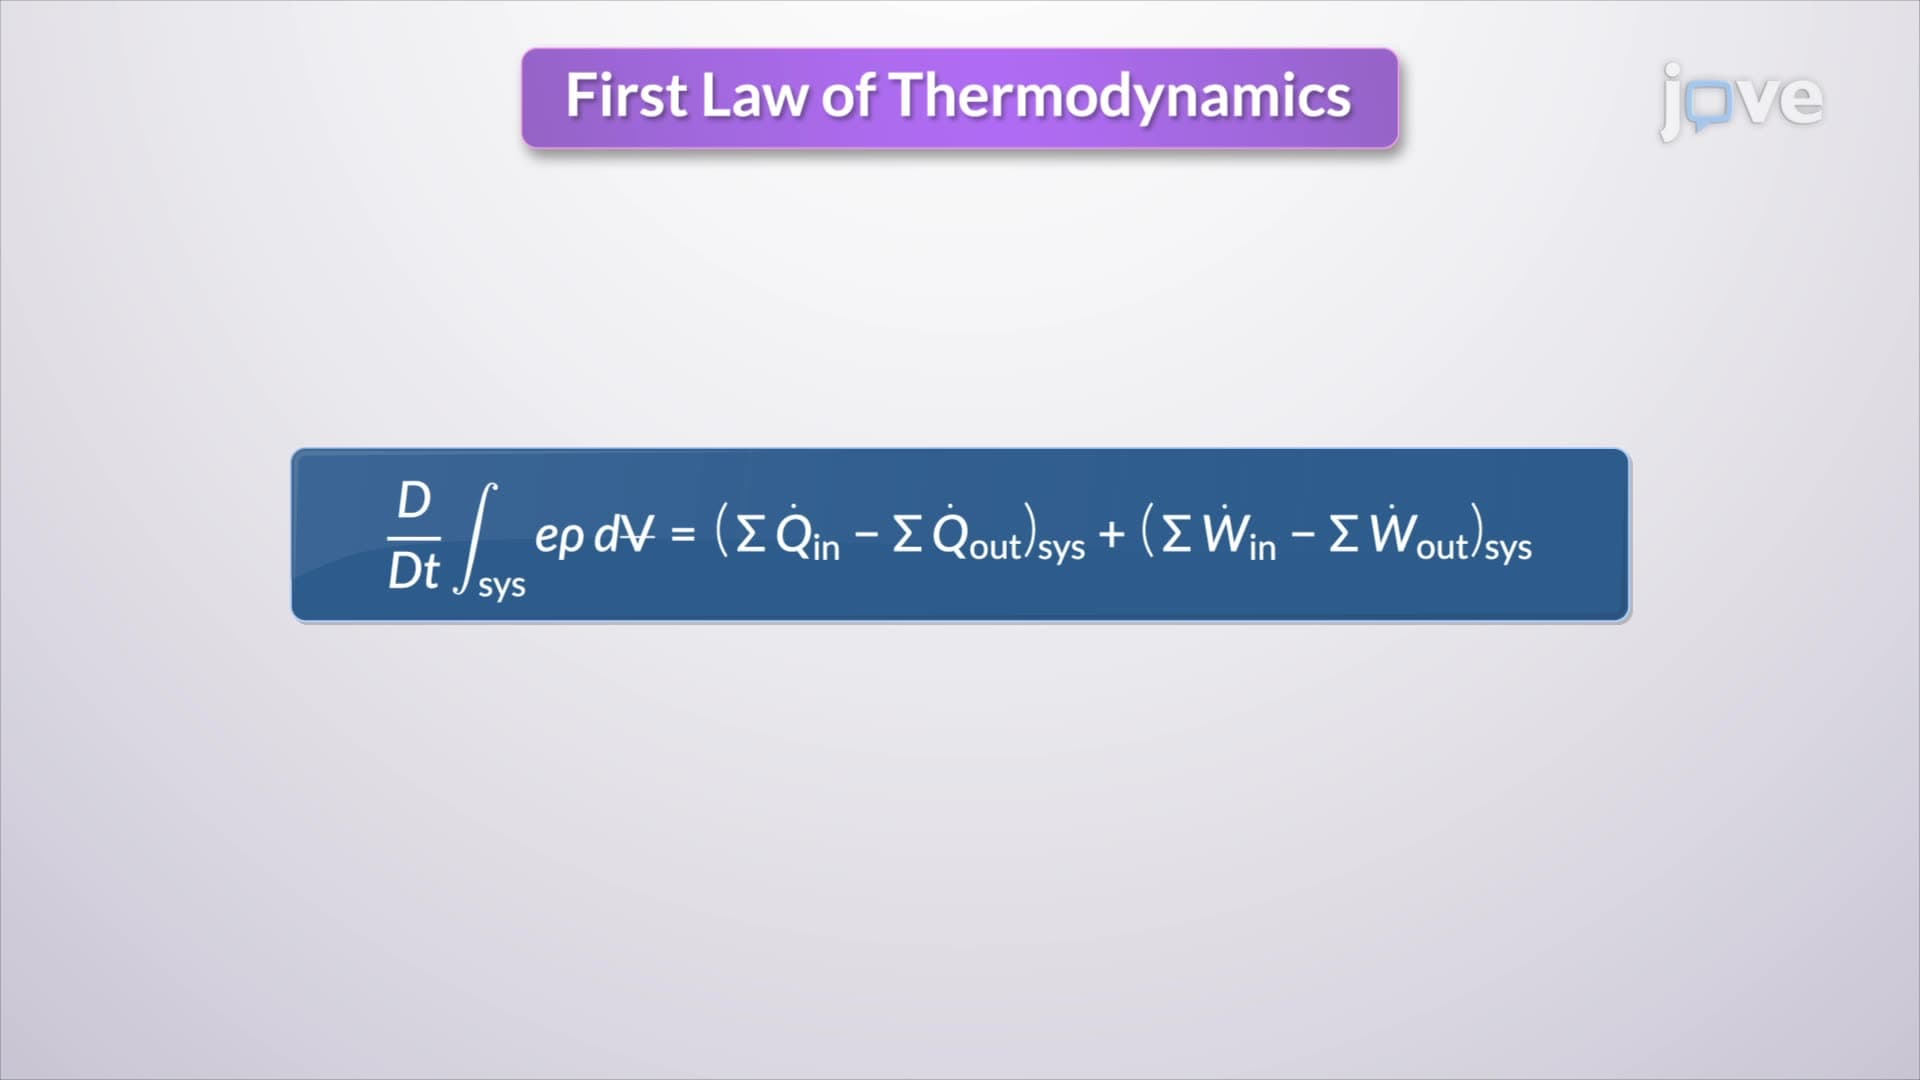
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:19
PID Controller
 01:15
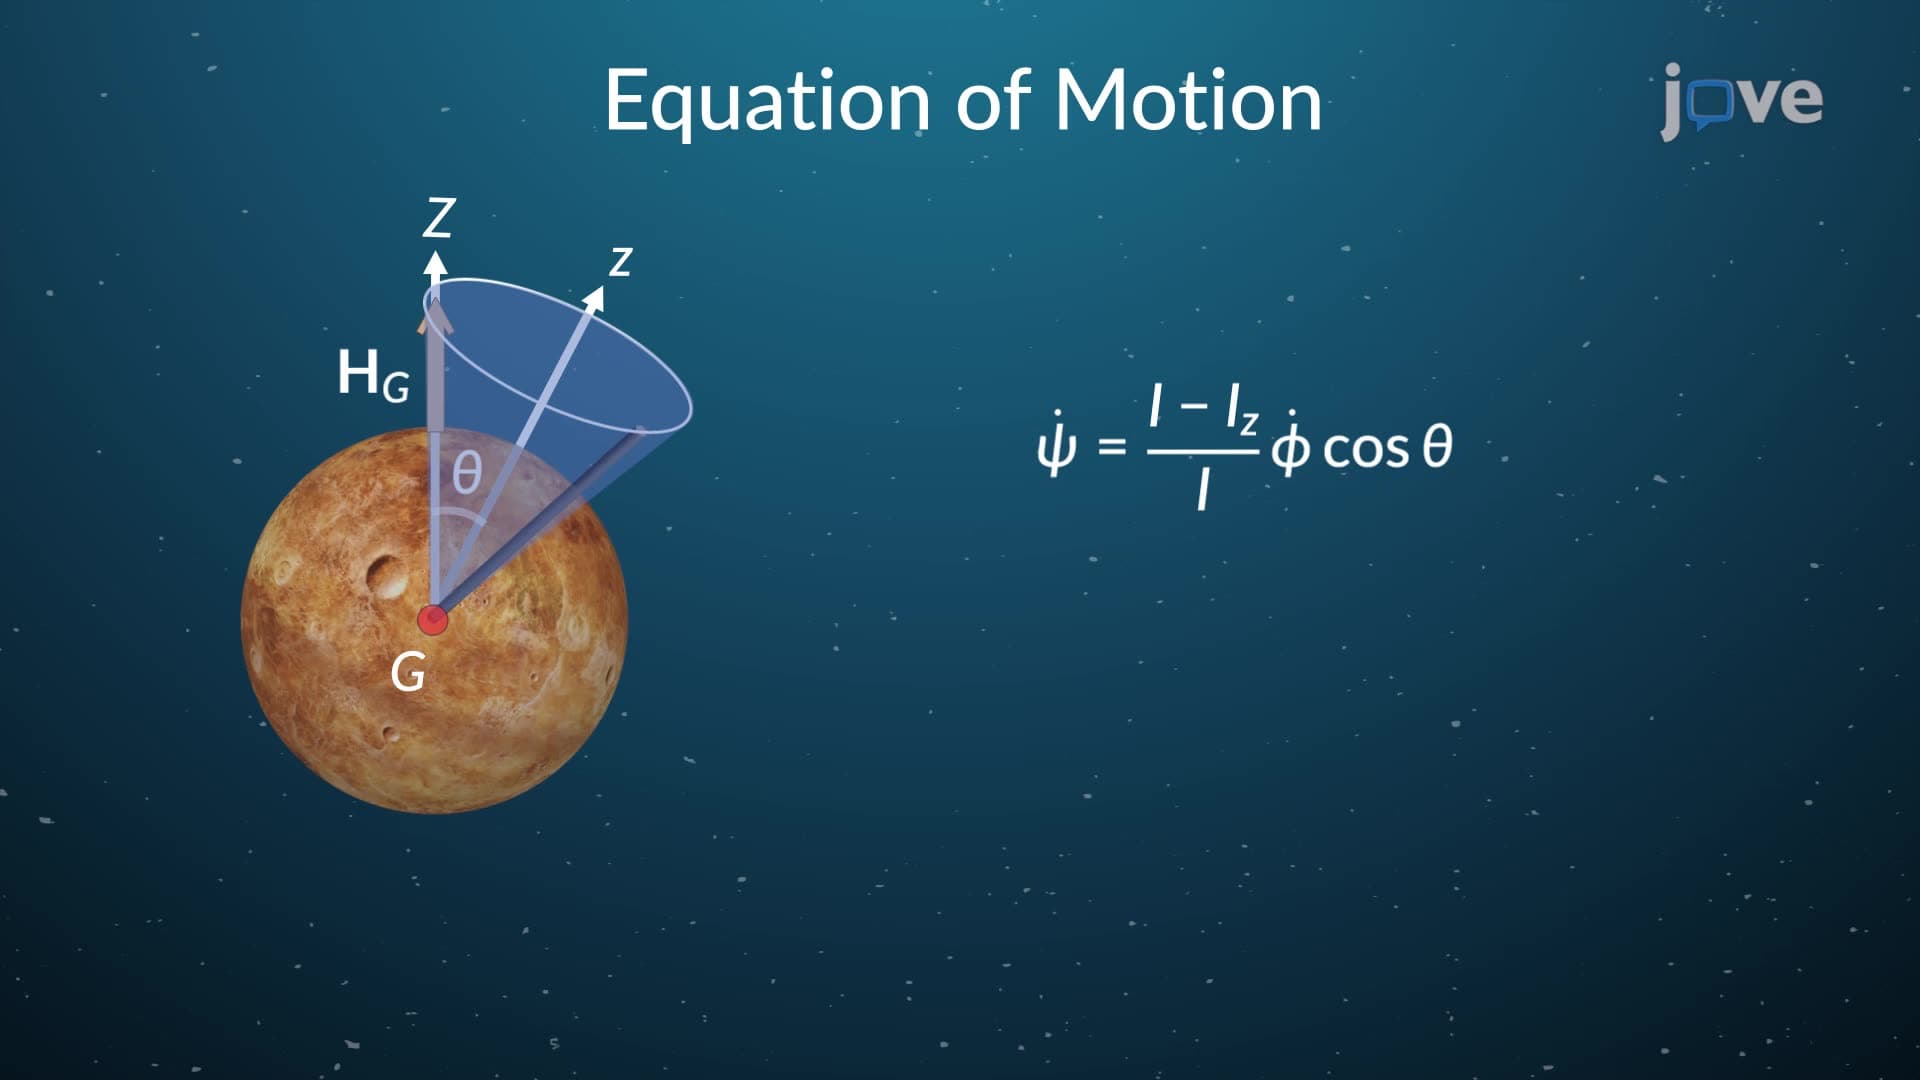
Torque Free Motion