Related Experiment Video
Updated: Jul 24, 2025
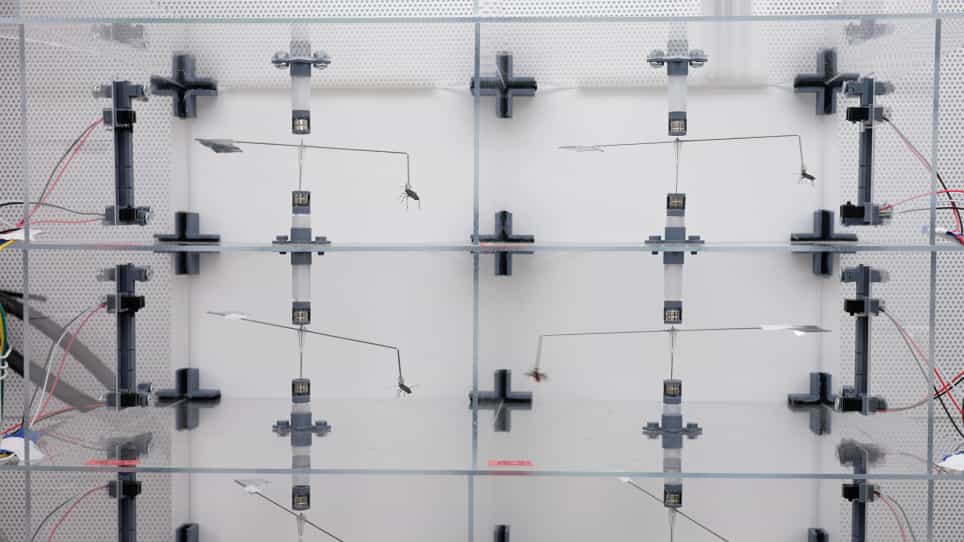
Building an Enhanced Flight Mill for the Study of Tethered Insect Flight
Published on: March 10, 2021
A simple computerized Arduino-based control system for insect rotary flight mills
Miles T Casey1, Scott A Machtley1, Paul V Merten1
1Arid-Land Agricultural Research Center, USDA-ARS, 21881 North Cardon Lane, Maricopa, AZ 85138, USA.

Abstract:
Flight mills are widely used to investigate insect flight behavior. As technology advances, the means to build a computerized control system for a flight mill has become more accessible in terms of both price and availability of components. However, the specialized electronics and programming knowledge required to build such a system can still present an obstacle to interested parties. Here, we describe a simple and inexpensive flight mill control system that can be easily assembled and operated without specialized experience. The hardware and software components are built around an Arduino single-board microcontroller, which outputs raw data in the form of timestamped detections of rotations of the flight mill arm. This control system is suitable both as the basis for new flight mills and for replacing outdated computer controls on existing flight mills. Additionally, it can be used with any rotary flight mill design that uses an electronic sensor to count rotations.
More Related Videos
Related Concept Videos
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
PI Controller: Design
 01:22
Mechanical Systems
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...