Related Experiment Video
Updated: Jul 24, 2025
Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
Intelligent Vehicle Path Tracking Control Method Based on Curvature Optimisation
Qing Ye1, Chaojun Gao1, Yao Zhang1
1Automotive Engineering Research Institute, Jiangsu University, Zhenjiang 212013, China.

Abstract:
In this study, an intelligent vehicle (IV) path tracking control method based on curvature optimisation is proposed to reduce the comprehensive performance conflict of the system. This system conflict is caused by the mutual restriction between the path tracking accuracy and the body stability during the movement of the intelligent automobile. First, the working principle of the new IV path tracking control algorithm is briefly introduced. Then, a three-degrees-of-freedom vehicle dynamics model and a preview error model considering vehicle roll are established. In addition, a path tracking control method based on curvature optimisation is designed to solve the deterioration of vehicle stability even when the path tracking accuracy of the IV is improved. Finally, the effectiveness of the IV path tracking control system is validated through simulations and the Hardware in the Loop (HIL) test with various conditions forms. Results clearly show that the optimisation amplitude of the IV lateral deviation is up to 84.10%, and the stability is improved by approximately 2% under the v = 10 m/s and ρ = 0.15 m-1 condition; the optimisation amplitude of the lateral deviation is up to 66.80%, and the stability is improved by approximately 4% under the v = 10 m/s and ρ = 0.2 m-1 condition; the body stability is improved by 20-30% under the v = 15 m/s and ρ = 0.15 m-1 condition, and the boundary conditions of body stability are triggered. The curvature optimisation controller can effectively improve the tracking accuracy of the fuzzy sliding mode controller. The body stability constraint can also ensure the smooth running of the vehicle in the optimisation process.


Related Concept Videos
 01:27
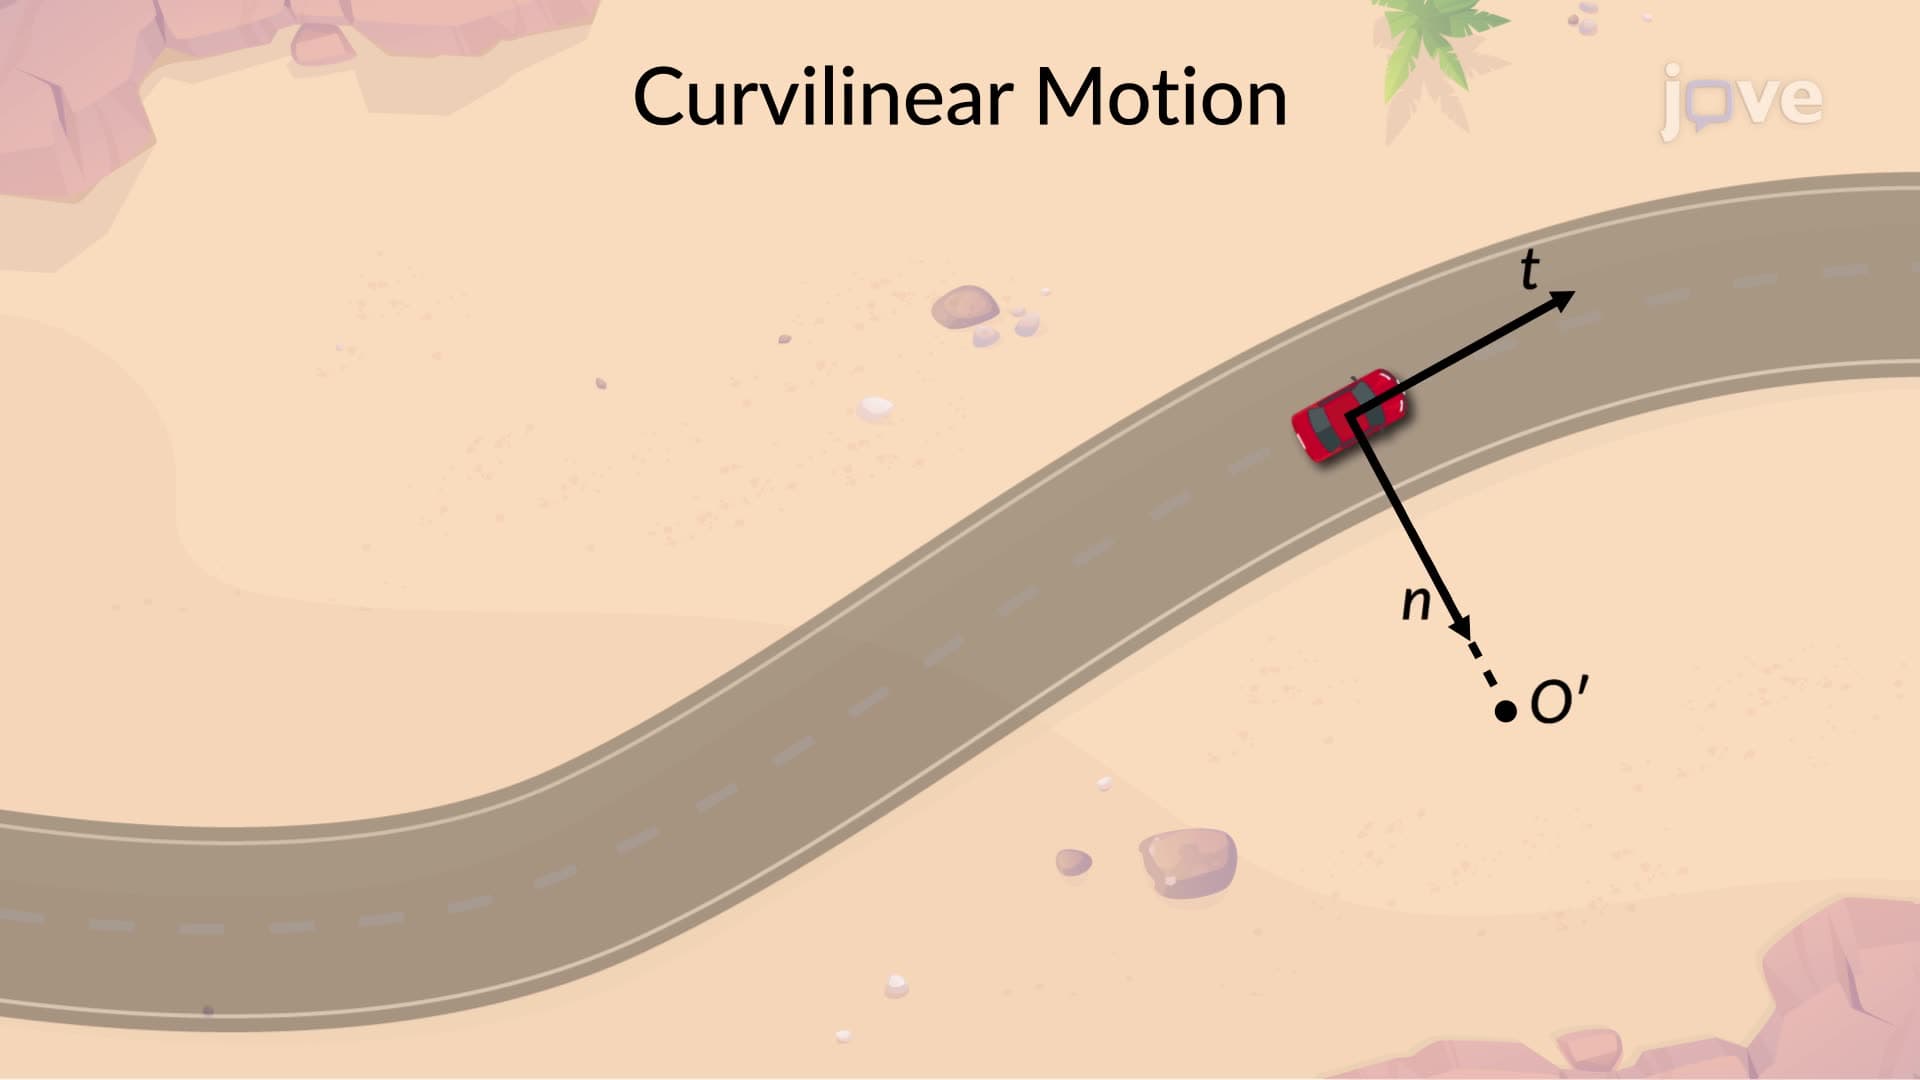
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Introduction to Vertical Curves
 01:27
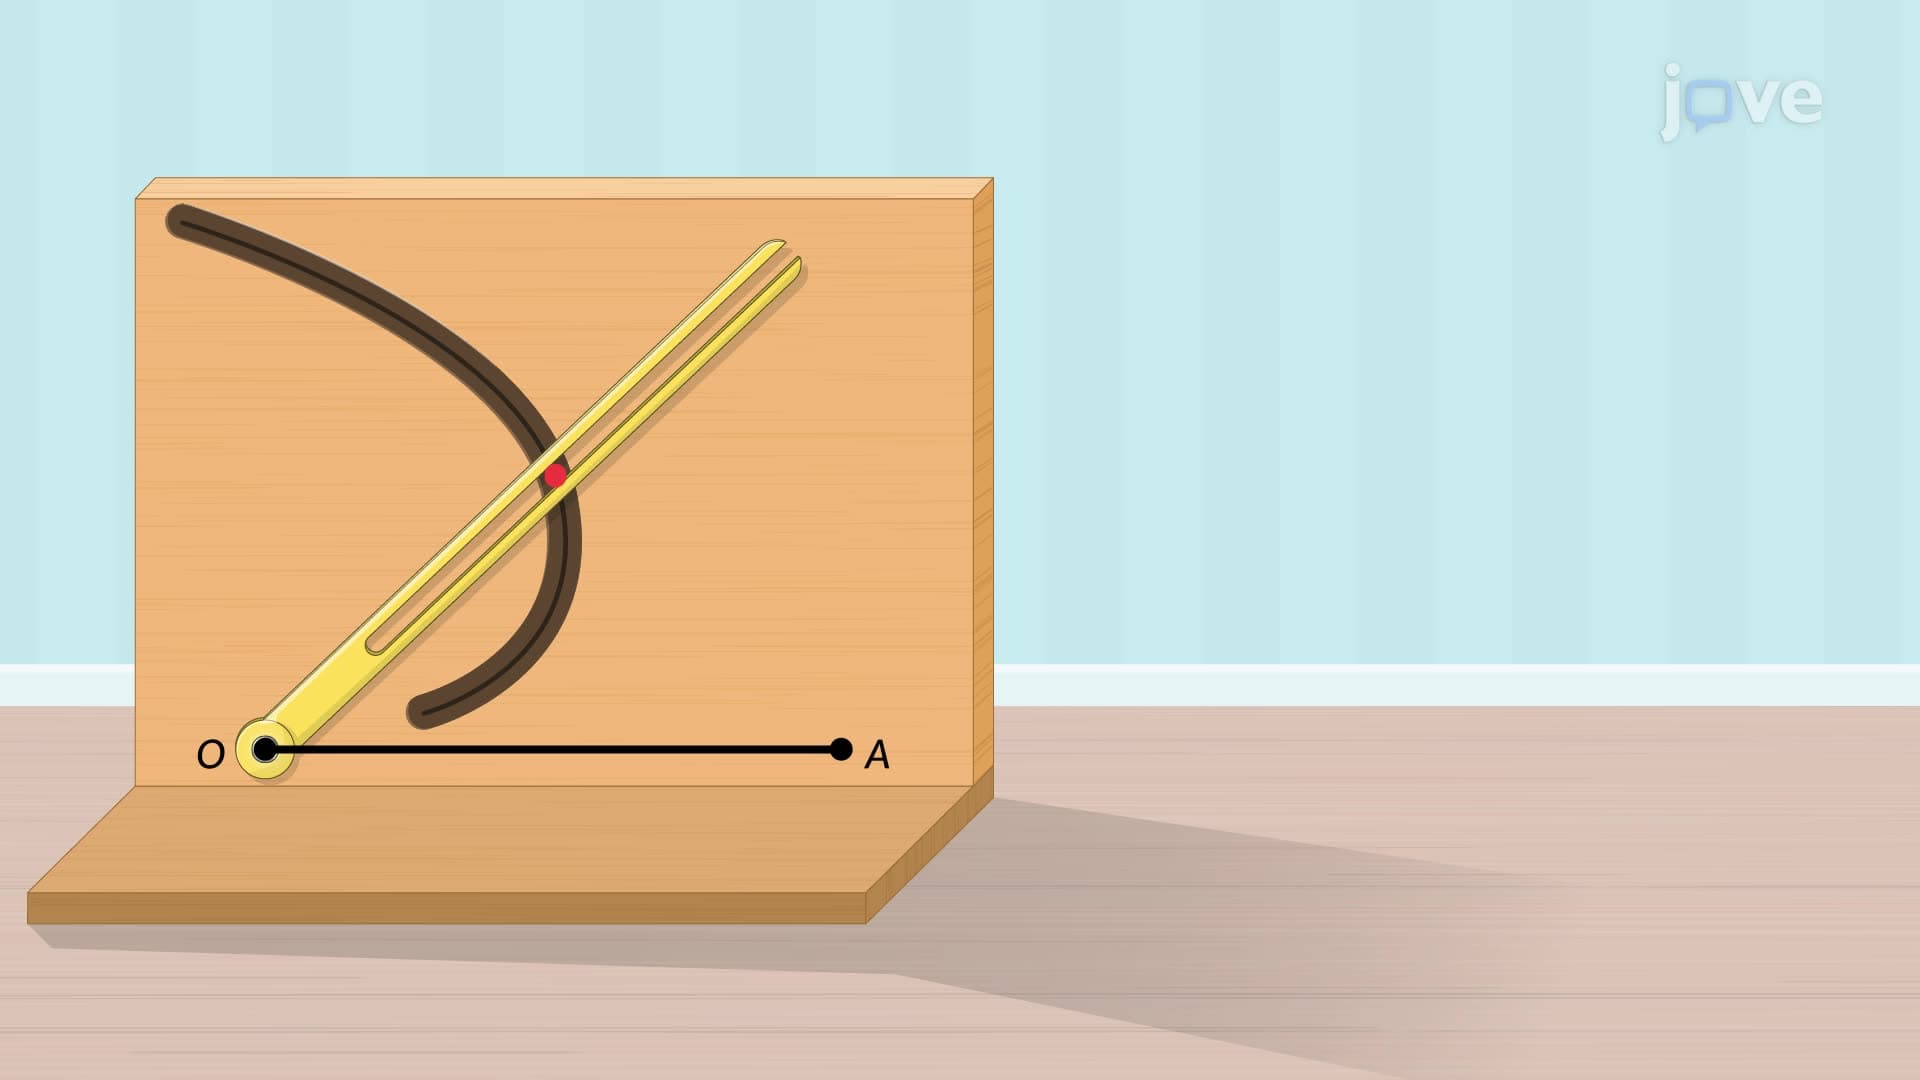
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...