Related Experiment Video
Updated: Jul 23, 2025
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Trends in road accidents on Brazil's highways: Evidence of persistence using fractional integration
Peter Wanke1, Luis Alberiko Gil-Alana2,3, Yong Tan4
1Federal University of Rio de Janeiro, Rio de Janeiro, Brazil.

Abstract:
This paper deals with the analysis of trends in road accidents on highways in Brazil. We use time series techniques based on fractional integration that allow us to determine if exogenous shocks in the data have transitory or permanent effects depending on the order of integration of the series. Our results indicate that a low degree of long memory was detected in the series with shocks having thus transitory effects over time. We further find that the number of accidents have been reducing over time, though in the presence of negative shocks, the recovery is not going to be immediate due to the long memory nature of the data. Despite the absence of relevant investment relating to infrastructure expansion, it is worth mentioning the consolidation of a nationwide tolled road system in Brazil involving concessions to private administrators, alongside more severe traffic laws that can impose limitations on driving licences.
Related Concept Videos
 01:08
Determination of Expected Frequency
 01:16
Hypothesis Test for Test of Independence
H0: The two variables (factors)...
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
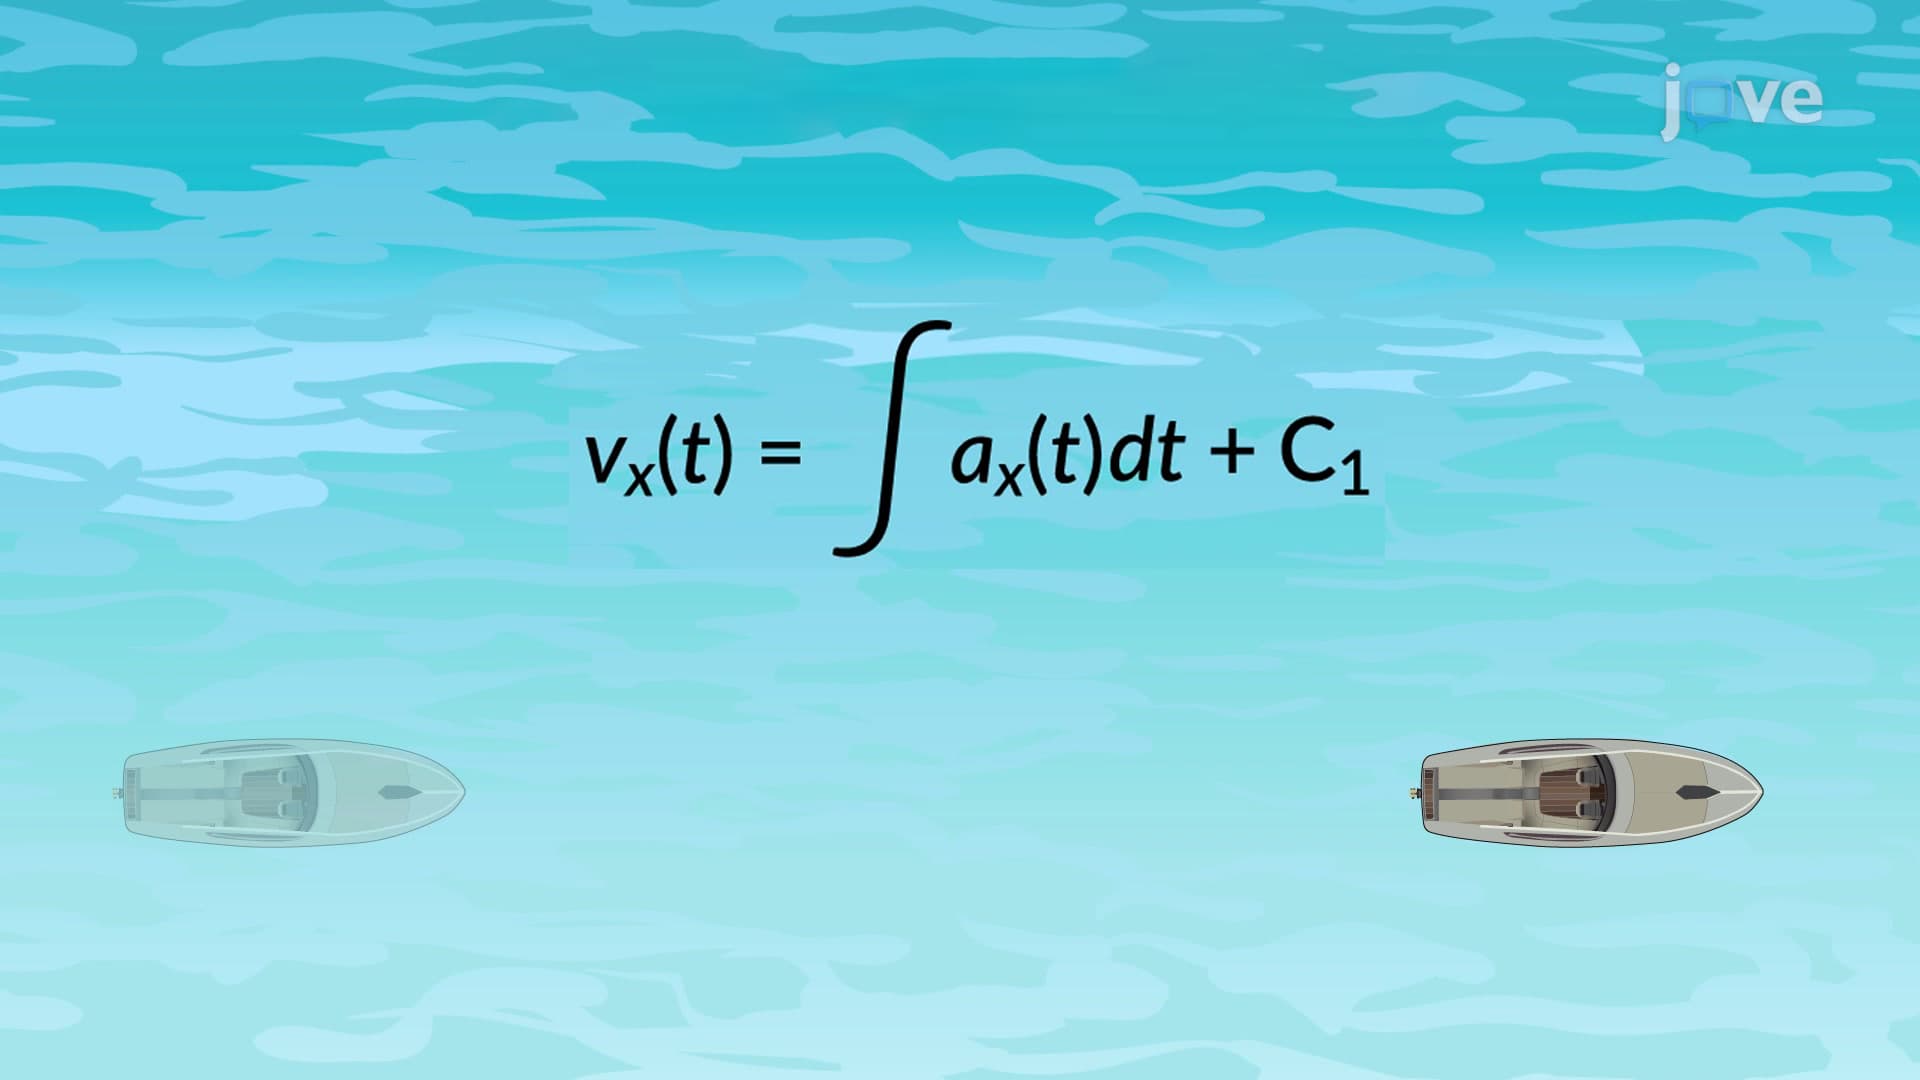 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:24
PI Controller: Design
 01:27
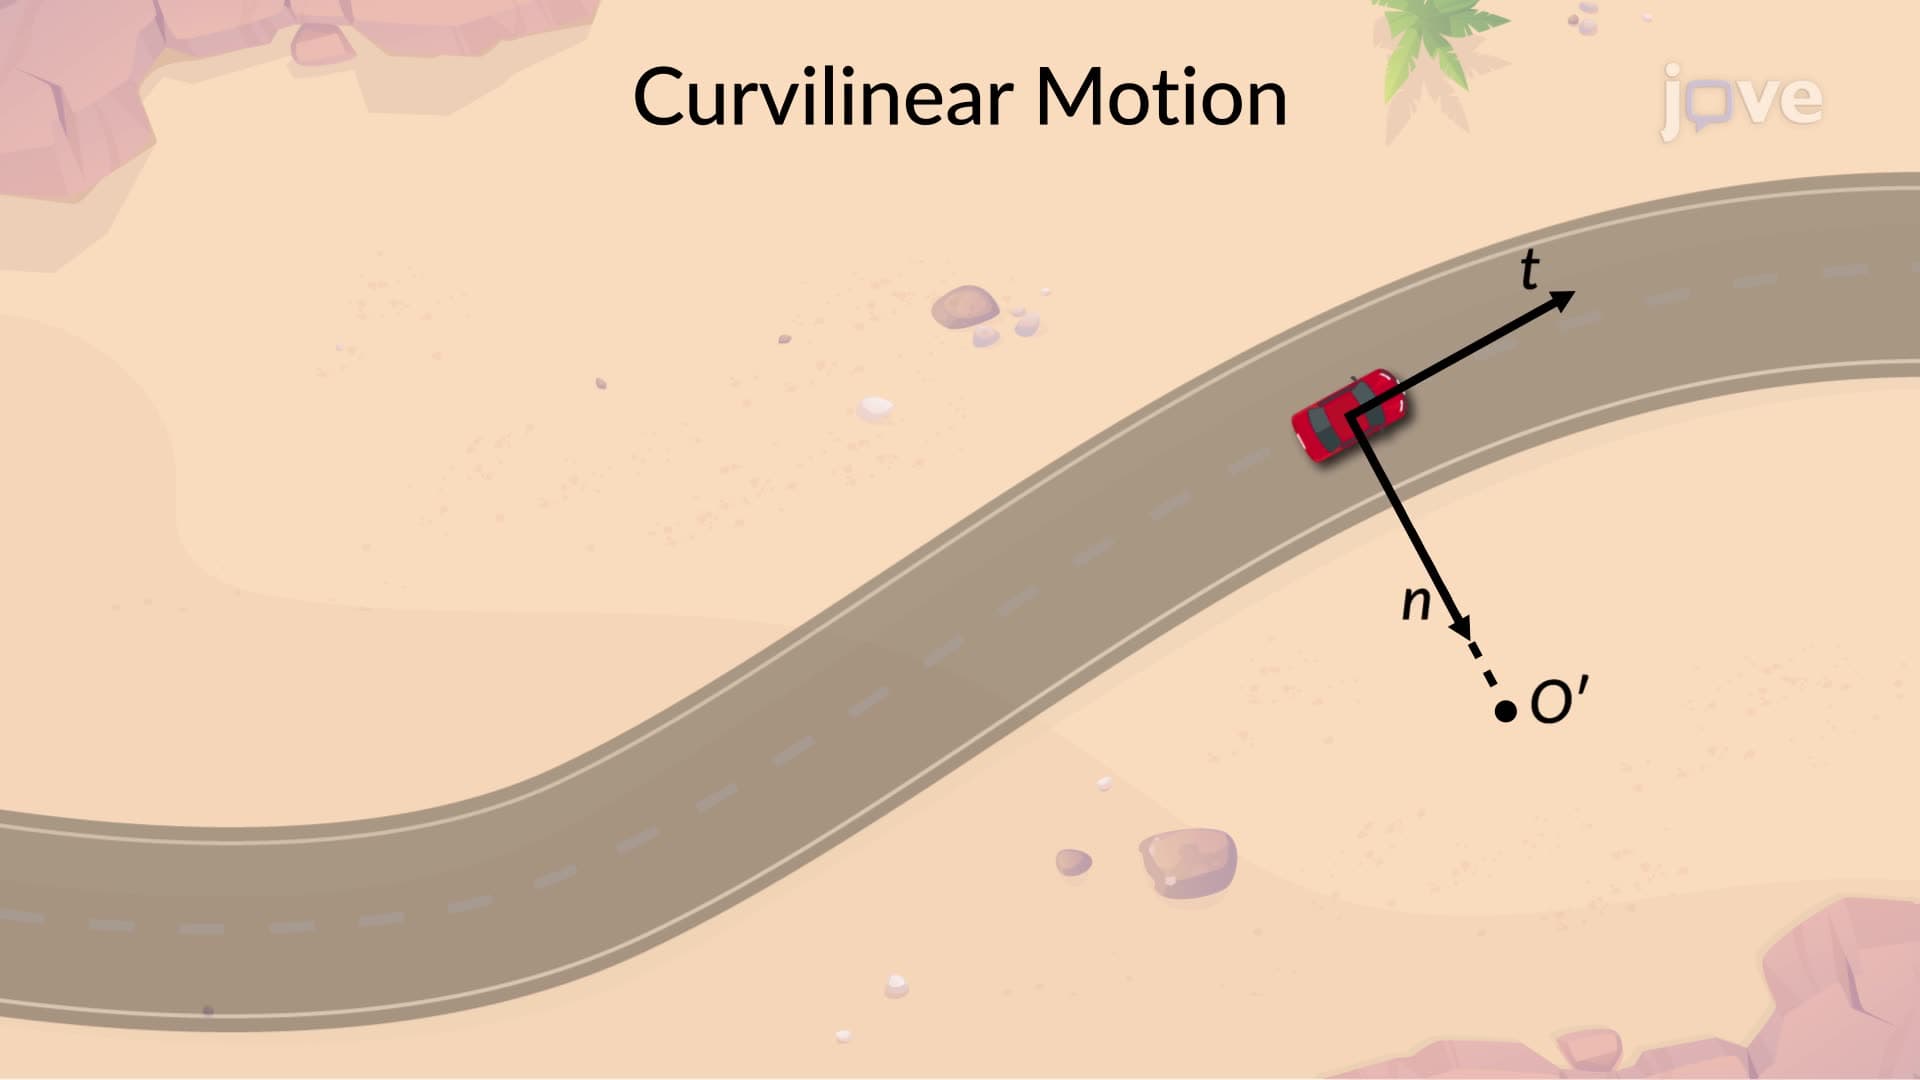
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...