Related Experiment Video
Updated: Jul 21, 2026
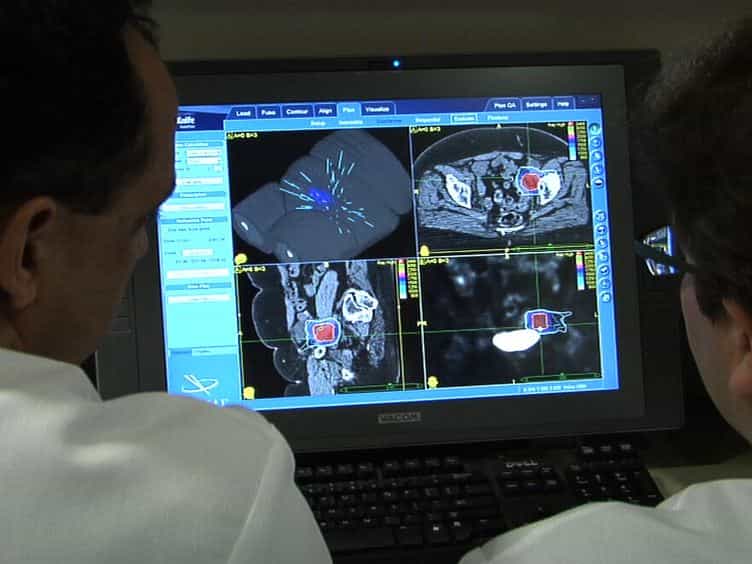

Stereotactic Radiosurgery for Gynecologic Cancer
Published on: April 17, 2012
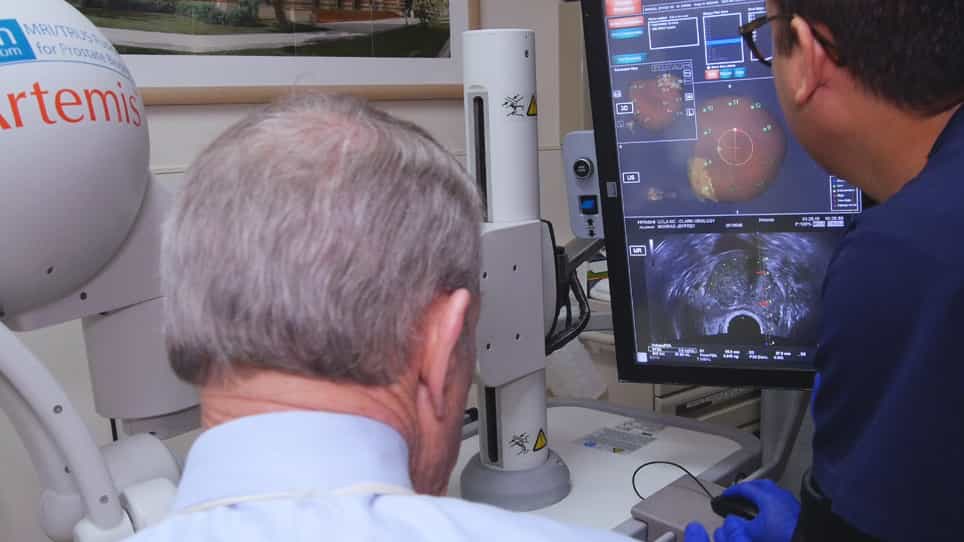
MR-guided HDR prostate brachytherapy with teleoperated steerable needles
M de Vries1, M Wijntjes2, J Sikorski2
1Department of Biomechanical Engineering, Delft University of Technology, Delft, The Netherlands. M.devries-2@tudelft.nl.

Abstract:
Conformity of tumour volumes and dose plans in prostate brachytherapy (BT) can be constrained by unwanted needle deflections, needle access restrictions and visualisation limitations. This work validates the feasibility of teleoperated robotic control of an active steerable needle using magnetic resonance (MR) for guidance. With this system, perturbations can be counteracted and critical structures can be circumvented to access currently inaccessible areas. The system comprises of (1) a novel steerable needle, (2) the minimally invasive robotics in an MR environment (MIRIAM) system, and (3) the daVinci Research Kit (dVRK). MR scans provide visual feedback to the operator controlling the dVRK. Needle steering is performed along curved trajectories to avoid the urethra towards targets (representing tumour tissue) in a prostate phantom with a targeting error of 1.2 ± 1.0 mm. This work shows the potential clinical applicability of active needle steering for prostate BT with a teleoperated robotic system in an MR environment.
Related Concept Videos
 01:24
Magnetic Resonance Imaging
 01:14
Imaging Studies I: CT and MRI
Description of the Procedures
Computed Tomography (CT) scan:
Computed Tomography (CT) scans use X-ray technology to generate detailed images of bones, organs, and tissues. During the scan, the patient lies on a moving table...
 01:21
Imaging Studies for Cardiovascular System IV: CMRI
 01:27
Imaging Studies IV: Magnetic Resonance Imaging