A haptic illusion created by gravity
Related Experiment Video
Updated: Jul 22, 2025
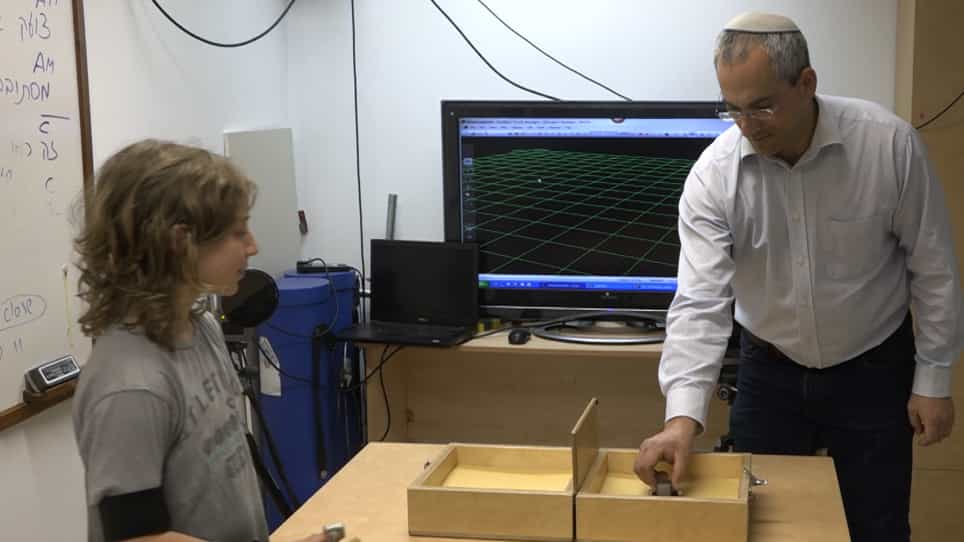
Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Laurent Opsomer1,2, Benoit P Delhaye1,2, Vincent Théate1,2
1Institute of Neuroscience, Université catholique de Louvain, 1200 Brussels, Belgium.

Abstract:
Human dexterity requires very fine and efficient control of fingertip forces, which relies on the integration of cutaneous and proprioceptive feedback. Here, we examined the influence of gravity on isometric force control. We trained participants to reproduce isometric vertical forces on a dynamometer held between the thumb and the index finger in normal gravity and tested them during parabolic flight creating phases of microgravity and hypergravity, thereby strongly influencing the motor commands and the proprioceptive feedback. We found that gravity creates the illusion that upward forces are larger than downward forces of the same magnitude. The illusion increased under hypergravity and was abolished under microgravity. Gravity also affected the control of the grip force employed to secure the grasp. These findings suggest that gravity biases the haptic estimation of forces, which has implications for the design of haptic devices to be used during flight or space activities.

Related Concept Videos
 01:09
Apparent Weight
Consider a person standing on a bathroom scale inside an elevator. If the scale is accurate at rest, its reading equals the...
 01:01
Weightlessness
 02:26
Responses to Gravity and Touch
 01:20
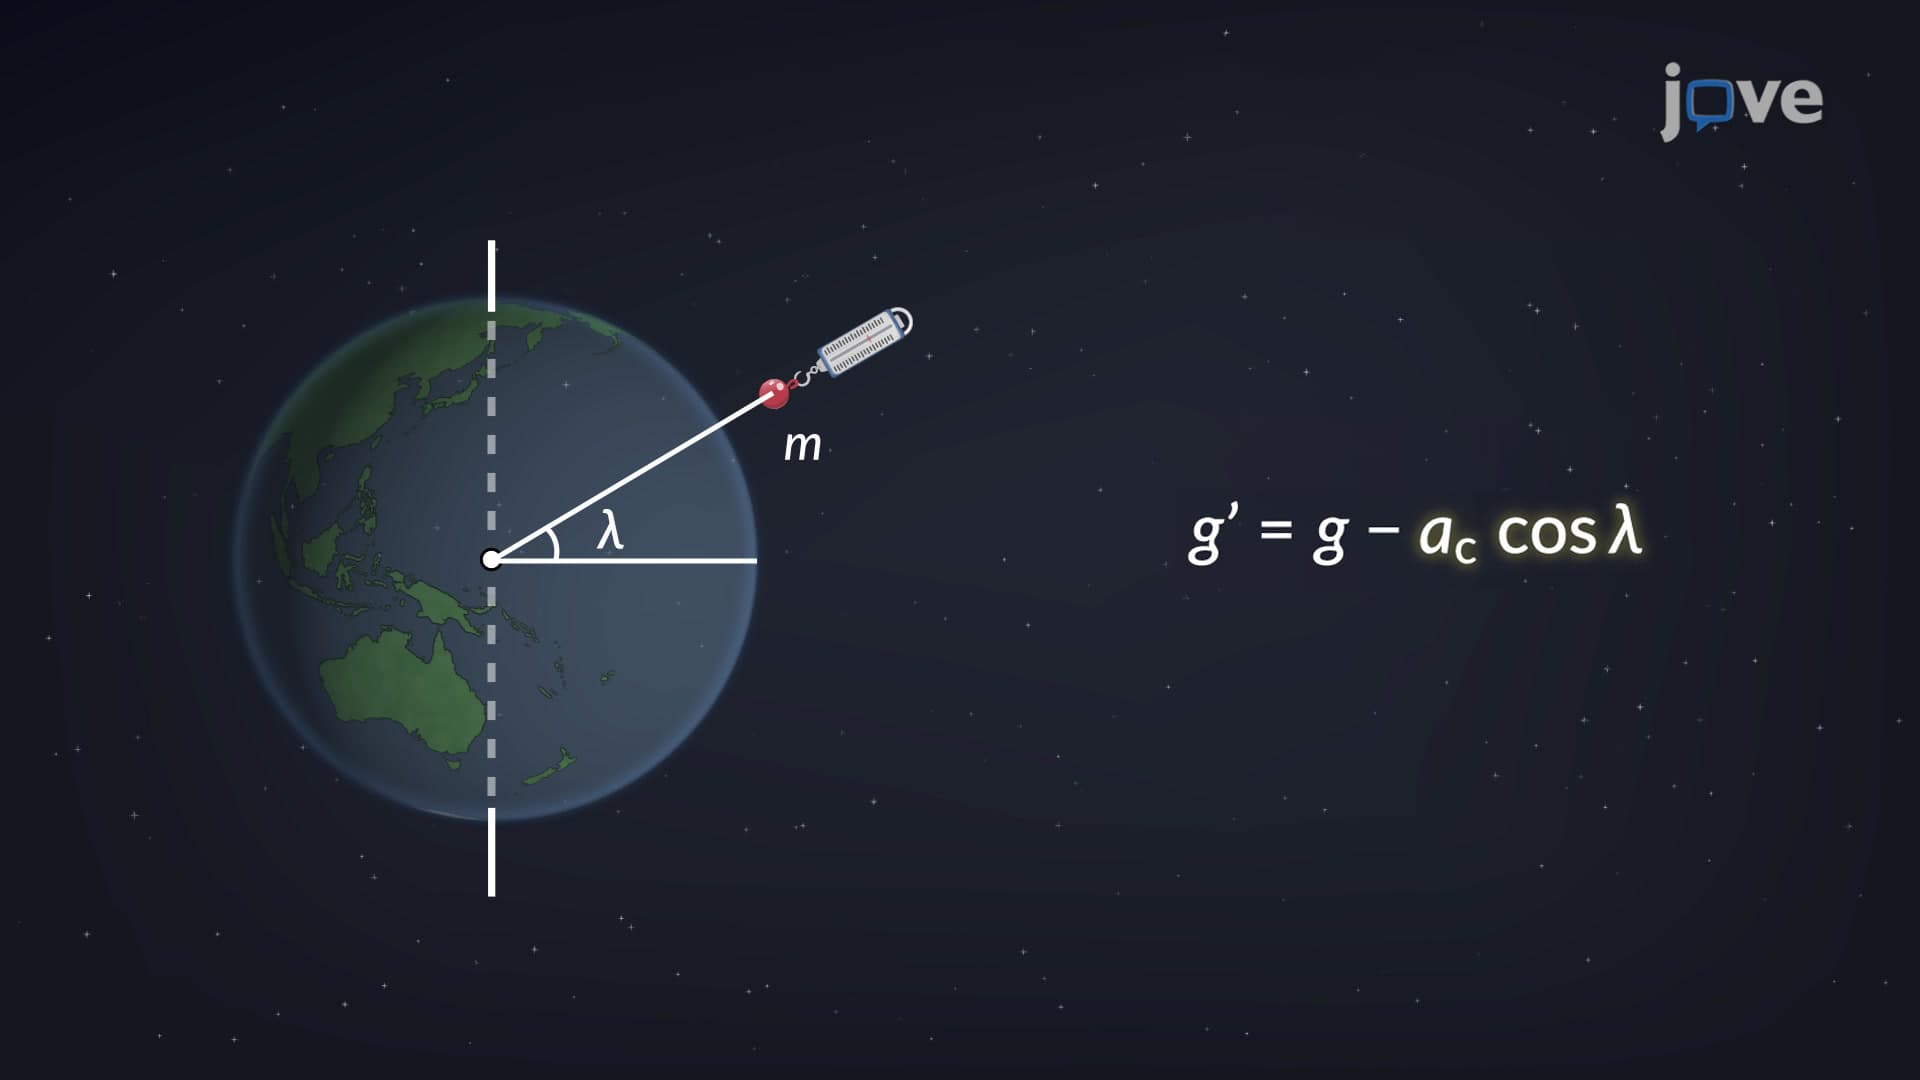
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:18
Principle of Equivalence