Equations for estimating the static supportive torque provided by upper-limb exoskeletons
Related Experiment Video
Updated: Jul 21, 2025

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Michael W B Watterworth1, Ryuta Dharmaputra1, Ryan Porto2
1Ontario Tech University, Oshawa, Ontario, Canada.

Abstract:
Upper-limb exoskeletons are gaining traction in industrial work environments. However, other than advertised general specifications (e.g., peak support angle), the support torque provided throughout the reach envelope is largely unknown to end users. As such, this paper describes a methodology for measuring the specific supportive torque provided by upper-limb exoskeletons. The support of four commercially available passive upper-limb exoskeletons was quantified using an isokinetic dynamometer for all support ranges and levels (n = 68). Tests were repeated four times to determine between-session reliability. Intraclass correlation coefficients demonstrated 'Good' to 'Excellent' reliability, except for one condition. Polynomial regression equations were developed for each condition to predict exoskeleton support for any upper-limb elevation angle between 10° and 180°. These equations can be used to approximate upper-limb exoskeleton support in digital human modeling assessments, or to aid selection of exoskeleton settings specific to a worker's anthropometry and work task location.
Related Concept Videos
 01:19
Net Torque Calculations
 01:30
Machines: Problem Solving II
 01:13
Angle of Twist: Problem Solving
 01:21
Screw: Problem Solving
To evaluate the...
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:05
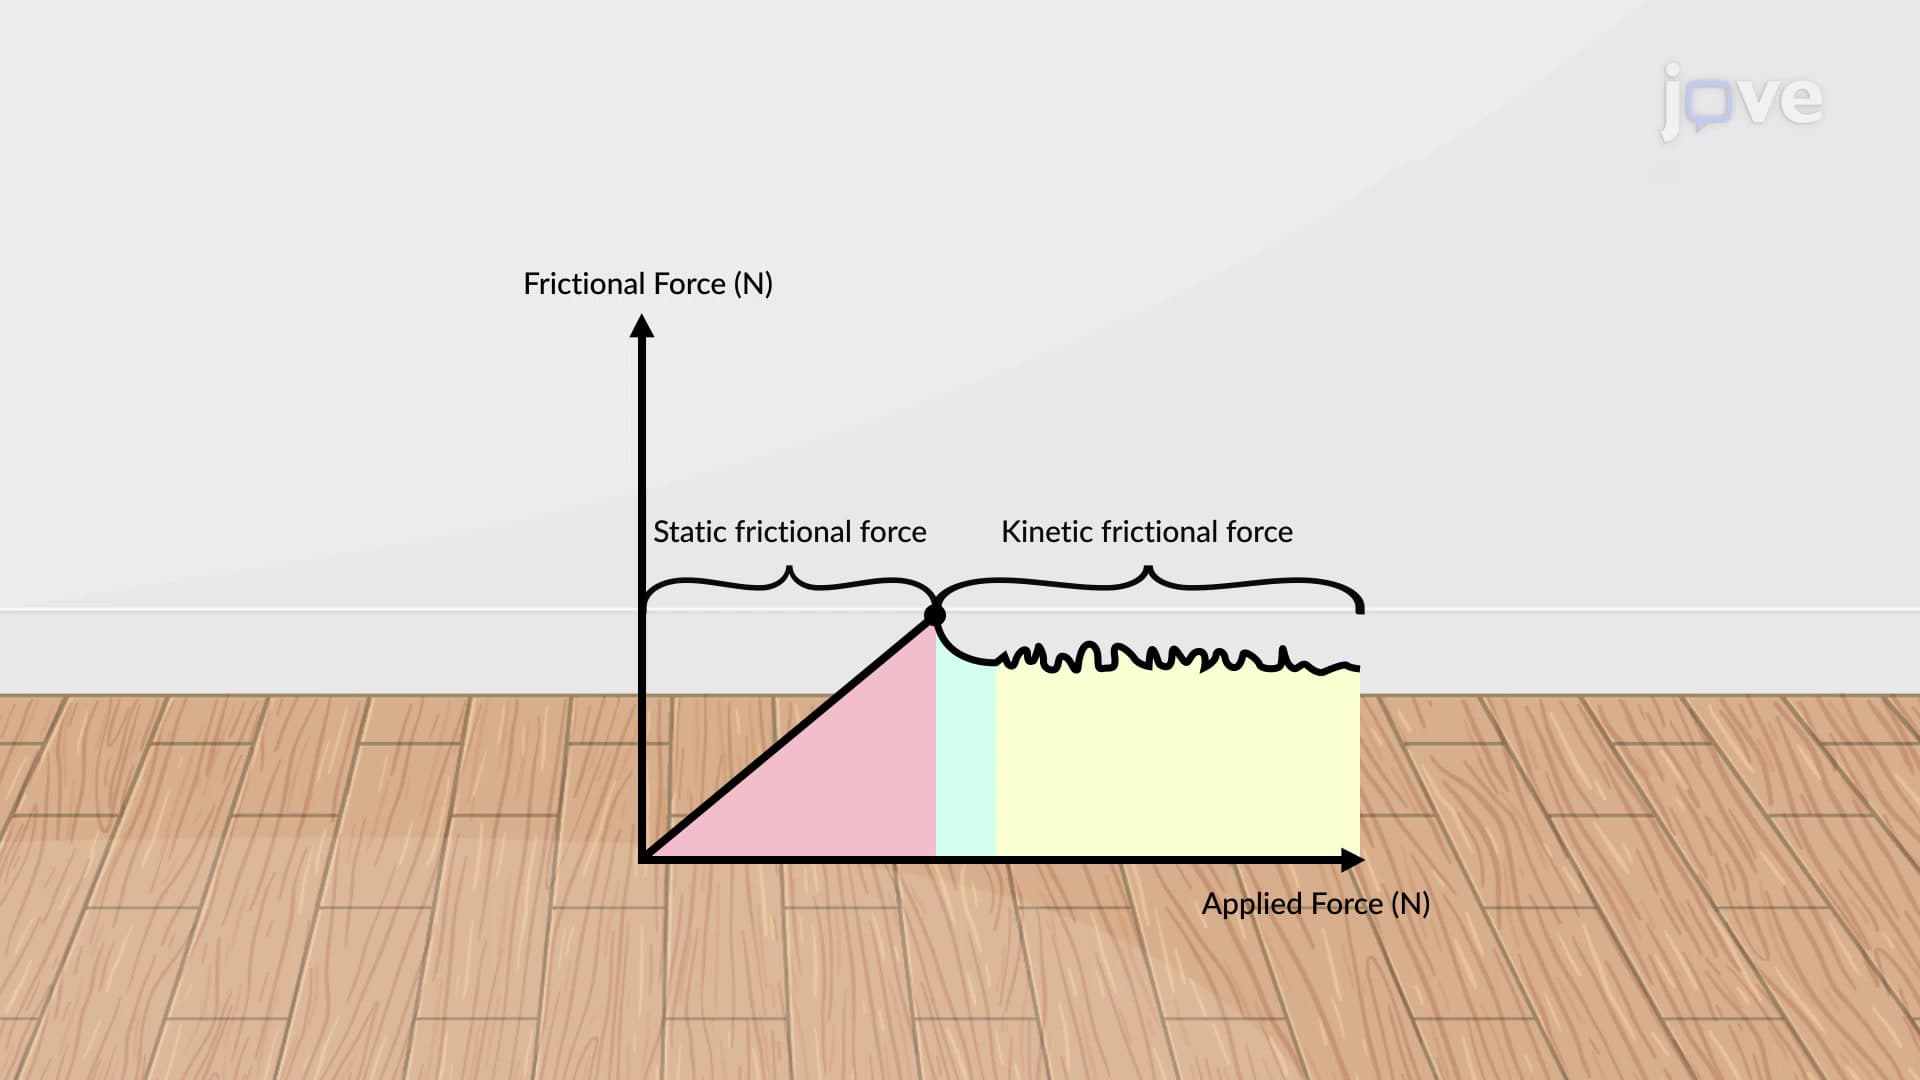
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...