Related Experiment Video
Updated: Jul 21, 2025


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Curriculum-reinforcement learning on simulation platform of tendon-driven high-degree of freedom underactuated
Keung Or1, Kehua Wu2, Kazashi Nakano2
1School of Science and Technology, Meiji University, Kawasaki, Japan.

Abstract:
A high degree of freedom (DOF) benefits manipulators by presenting various postures when reaching a target. Using a tendon-driven system with an underactuated structure can provide flexibility and weight reduction to such manipulators. The design and control of such a composite system are challenging owing to its complicated architecture and modeling difficulties. In our previous study, we developed a tendon-driven, high-DOF underactuated manipulator inspired from an ostrich neck referred to as the Robostrich arm. This study particularly focused on the control problems and simulation development of such a tendon-driven high-DOF underactuated manipulator. We proposed a curriculum-based reinforcement-learning approach. Inspired by human learning, progressing from simple to complex tasks, the Robostrich arm can obtain manipulation abilities by step-by-step reinforcement learning ranging from simple position control tasks to practical application tasks. In addition, an approach was developed to simulate tendon-driven manipulation with a complicated structure. The results show that the Robostrich arm can continuously reach various targets and simultaneously maintain its tip at the desired orientation while mounted on a mobile platform in the presence of perturbation. These results show that our system can achieve flexible manipulation ability even if vibrations are presented by locomotion.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:23
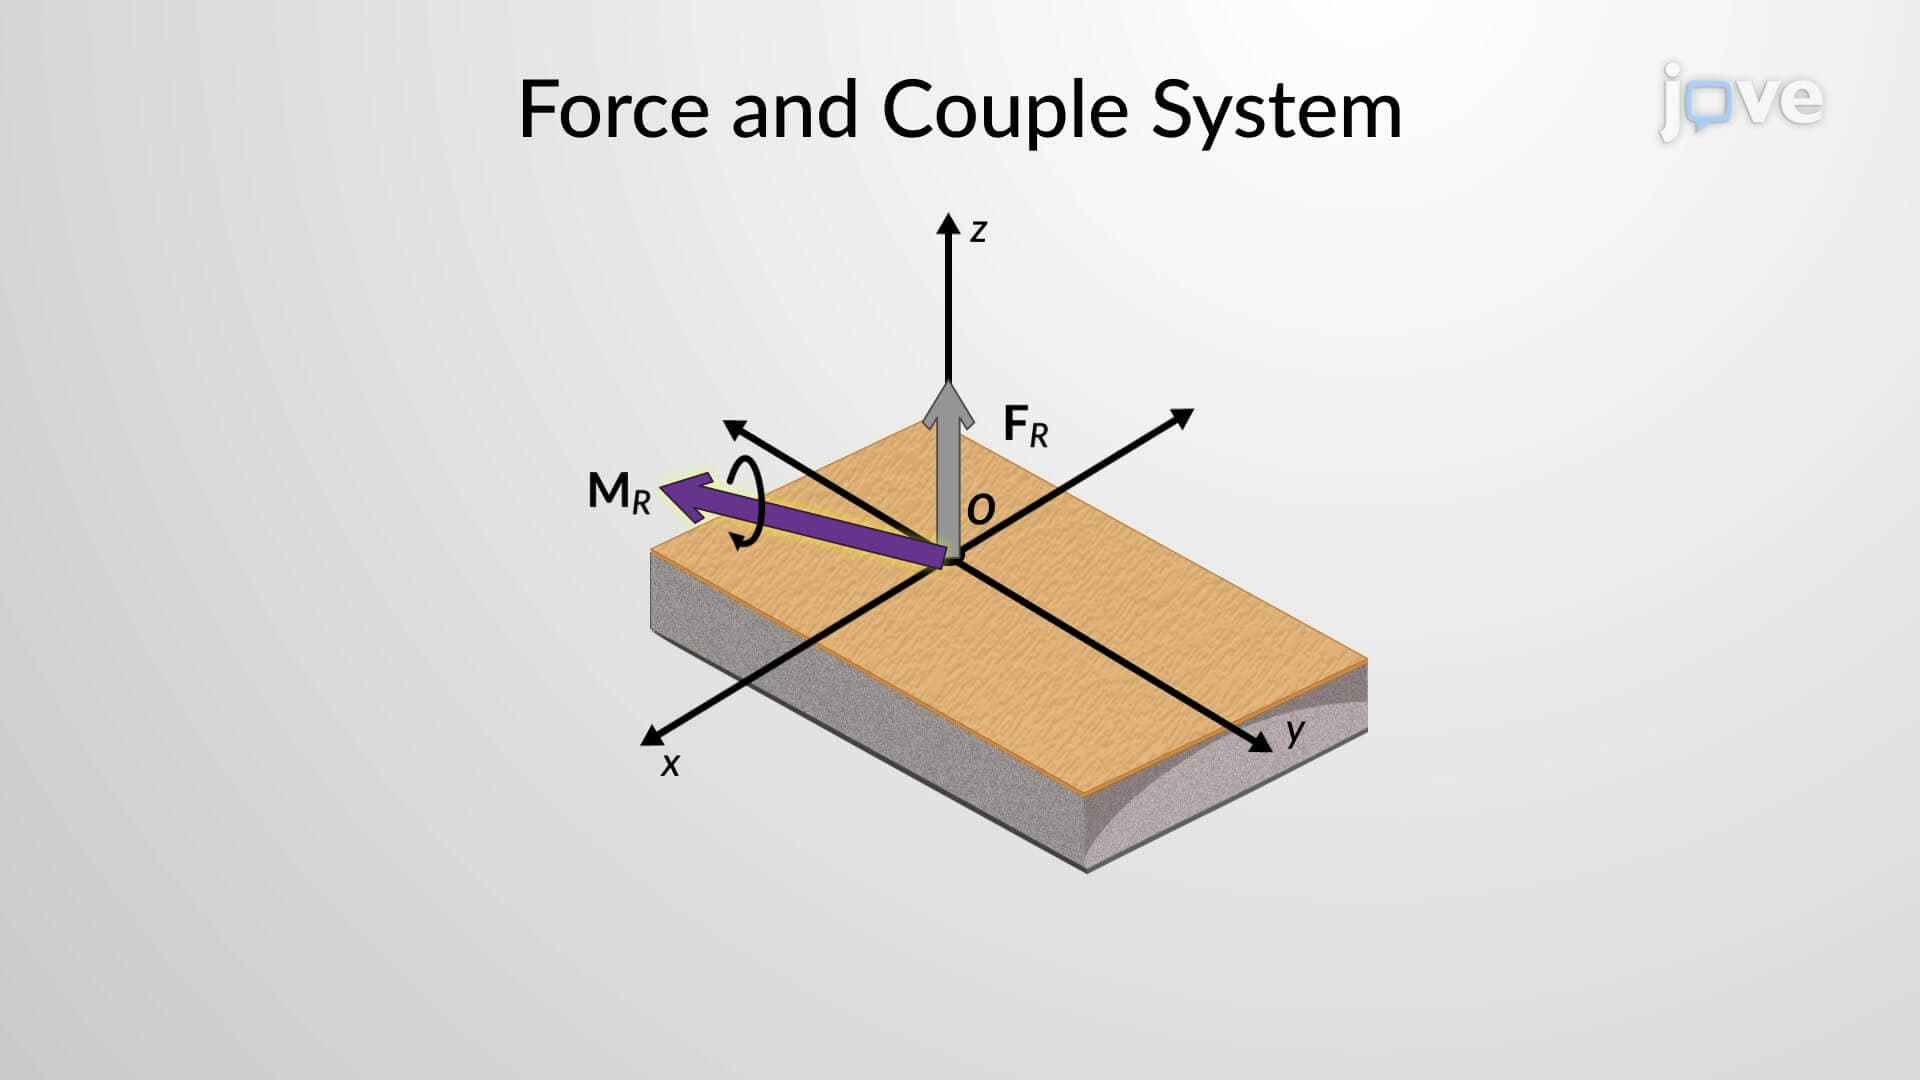
Simplification of a Force and Couple System: II
 01:15
Torque Free Motion