A Spider-Joint-like Bionic Actuator with an Approximately Triangular Prism Shape
Related Experiment Video
Updated: Jul 21, 2025
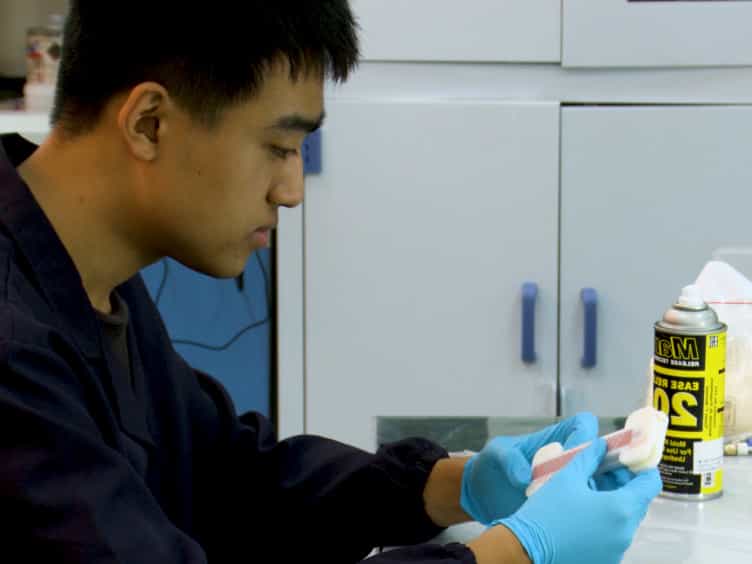
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Xiaomao Jiang1, Jun Yang1, Le Zeng2
1College of Engineering and Design, Hunan Normal University, Changsha 410081, China.

Abstract:
The unique drive principle and strong manipulation ability of spider legs have led to several bionic robot designs. However, some parameters of bionic actuators still need to be improved, such as torque. Inspired by the hydraulic drive principle of spider legs, this paper describes the design of a bionic actuator characterized by the use of air pressure on each surface and its transmittance in the direction of movement, achieving a torque amplification effect. The produced torque is as high as 4.78 N m. In addition, its torque characteristics during folding motions are similar to those during unfolding motions, showing that the bionic actuator has stable bidirectional drive capability.
Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:20
Plastic Deformation in Circular Shafts
 01:23
Pivot Bearings
A pivot bearing is a specialized type of bearing designed to support axial loads on a rotating shaft. The bearing surface, or the pivot, is positioned at the end of a shaft to support the axial thrust. The pivot may...