Related Experiment Video
Updated: Jul 20, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
You have been terminated: robots, work, and taxation
Gizem Akar1, Giorgia Casalone2, Martin Zagler1,2
1WU Vienna University of Economics and Business, Vienna, Austria.

Abstract:
We present a three sector OLG model with a homogeneous output good that is produced with traditional or robot technology. The traditional sector produces with labor and capital, whereas the modern sector employs robots instead of labor. Robots and workers are modeled as perfect substitutes to investigate whether economic policy under the harshest assumptions is able to prevent the ascent of a robotized economy. While we find that the transition is inevitable, higher taxes on robots and revenues can slow down the process. We also that the economy will switch from an exogenous growth model based on TFP to an endogenous growth model due to constant returns with respect to reproducible factors of production as it becomes fully robotized.
Related Concept Videos
 01:11
Work-Energy Theorem for Rotational Motion
 01:14
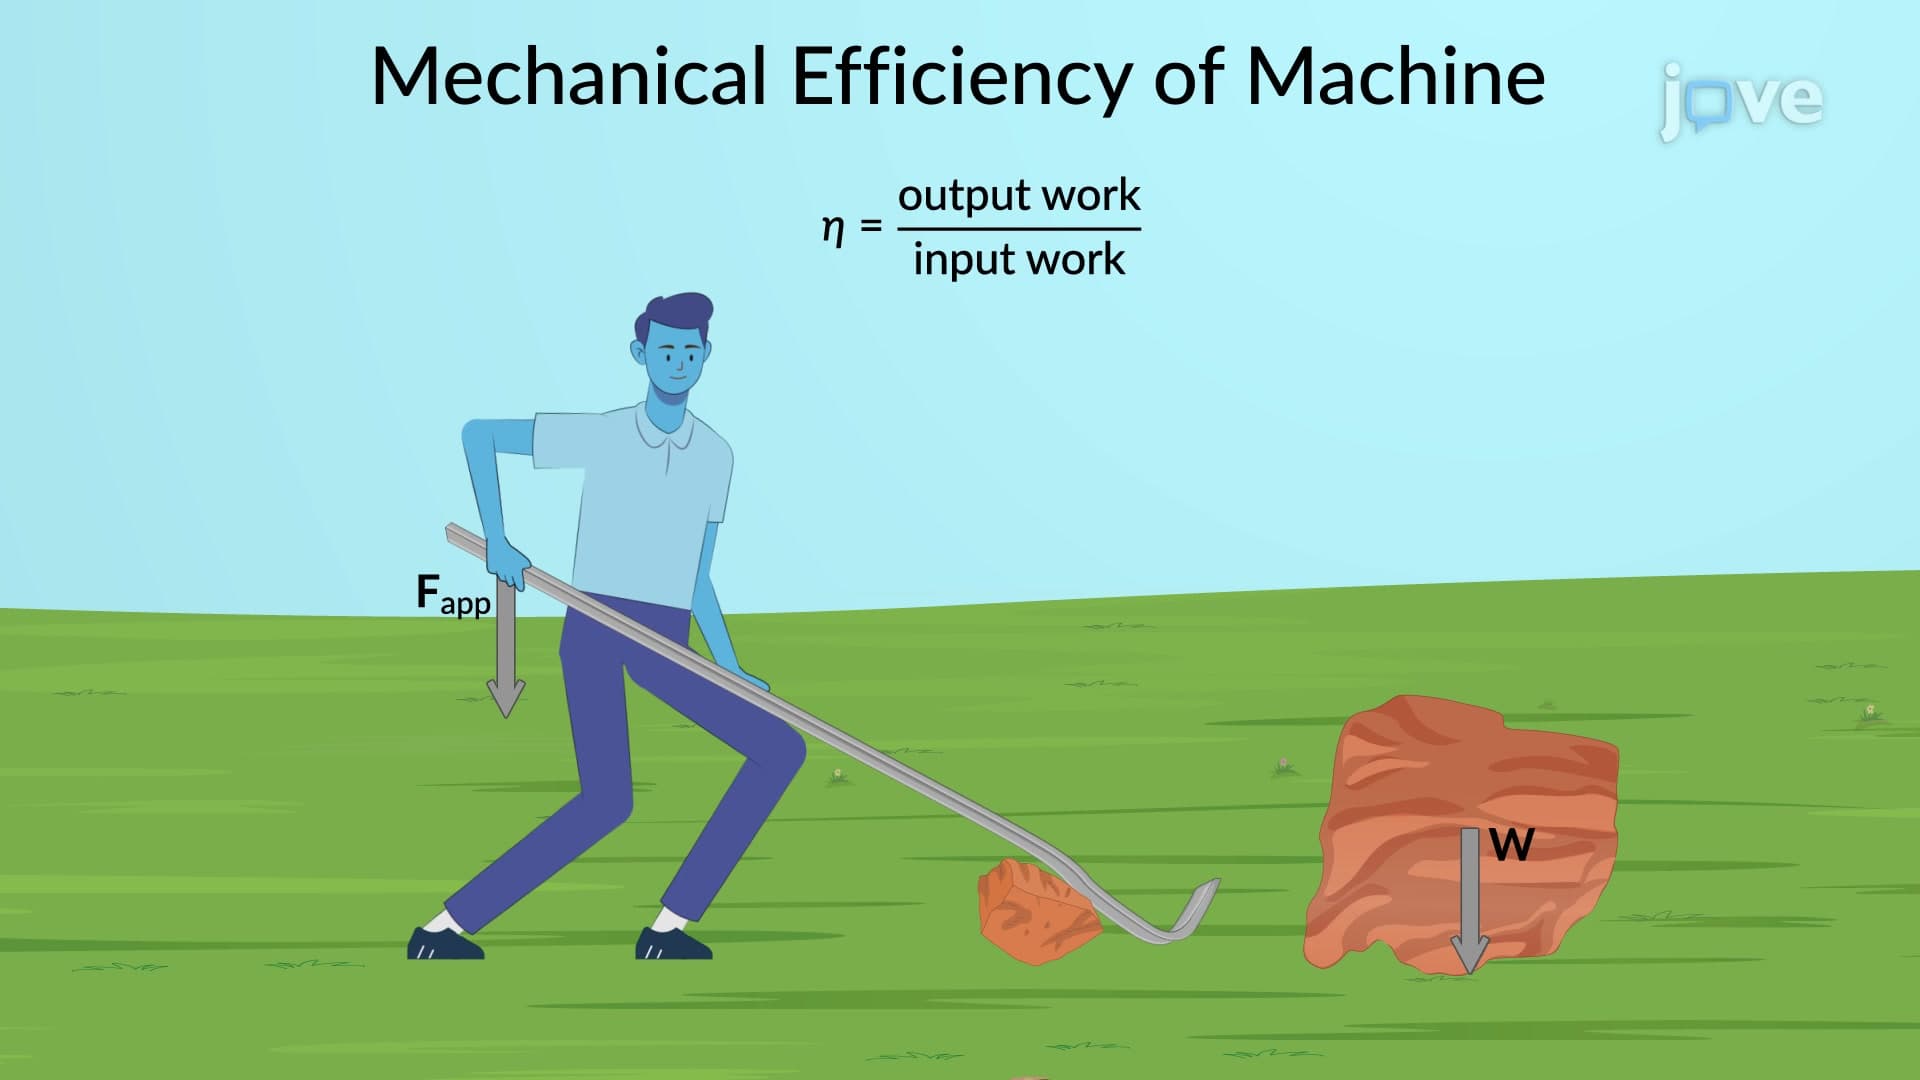
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:14
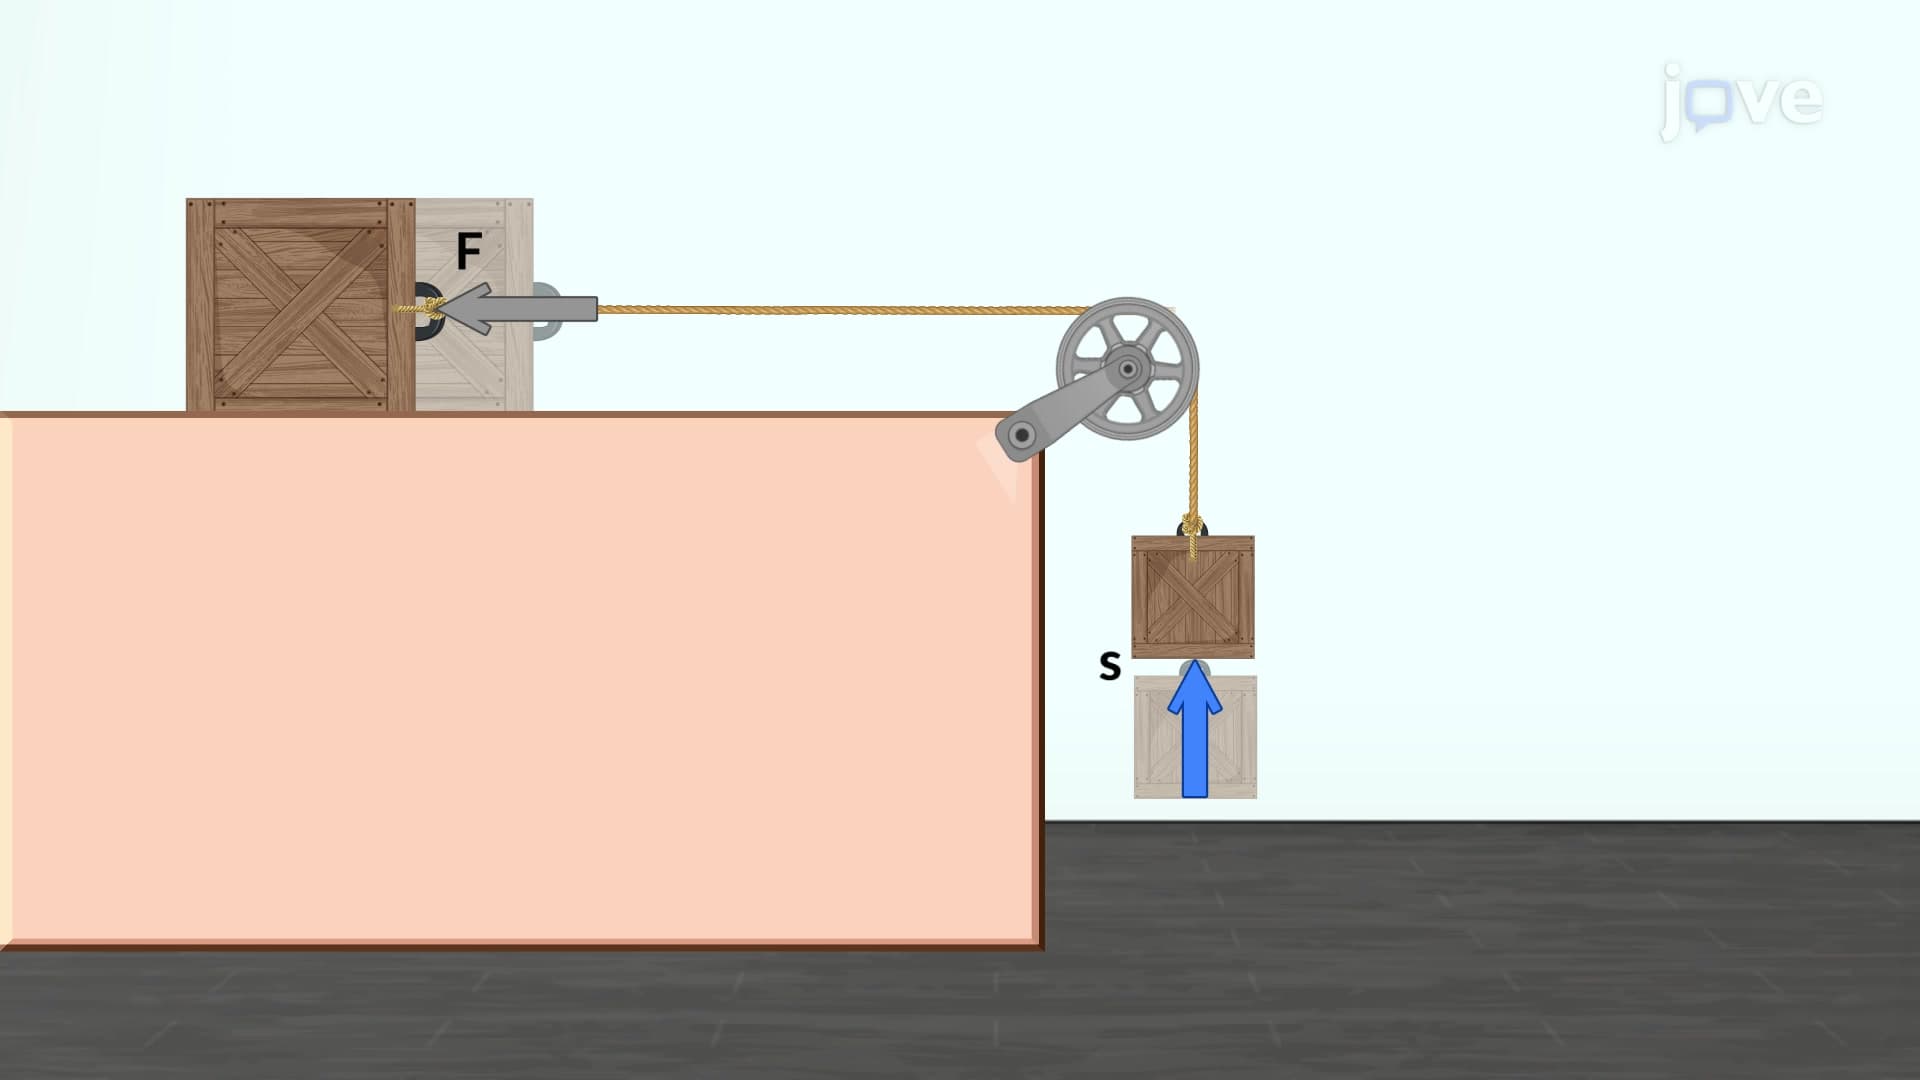
Work
Work is defined as the result of a force acting on an object, causing it to move along the line of action of force. It is also defined as the process of transferring energy through the application of force on an object, resulting in its displacement.
 01:27
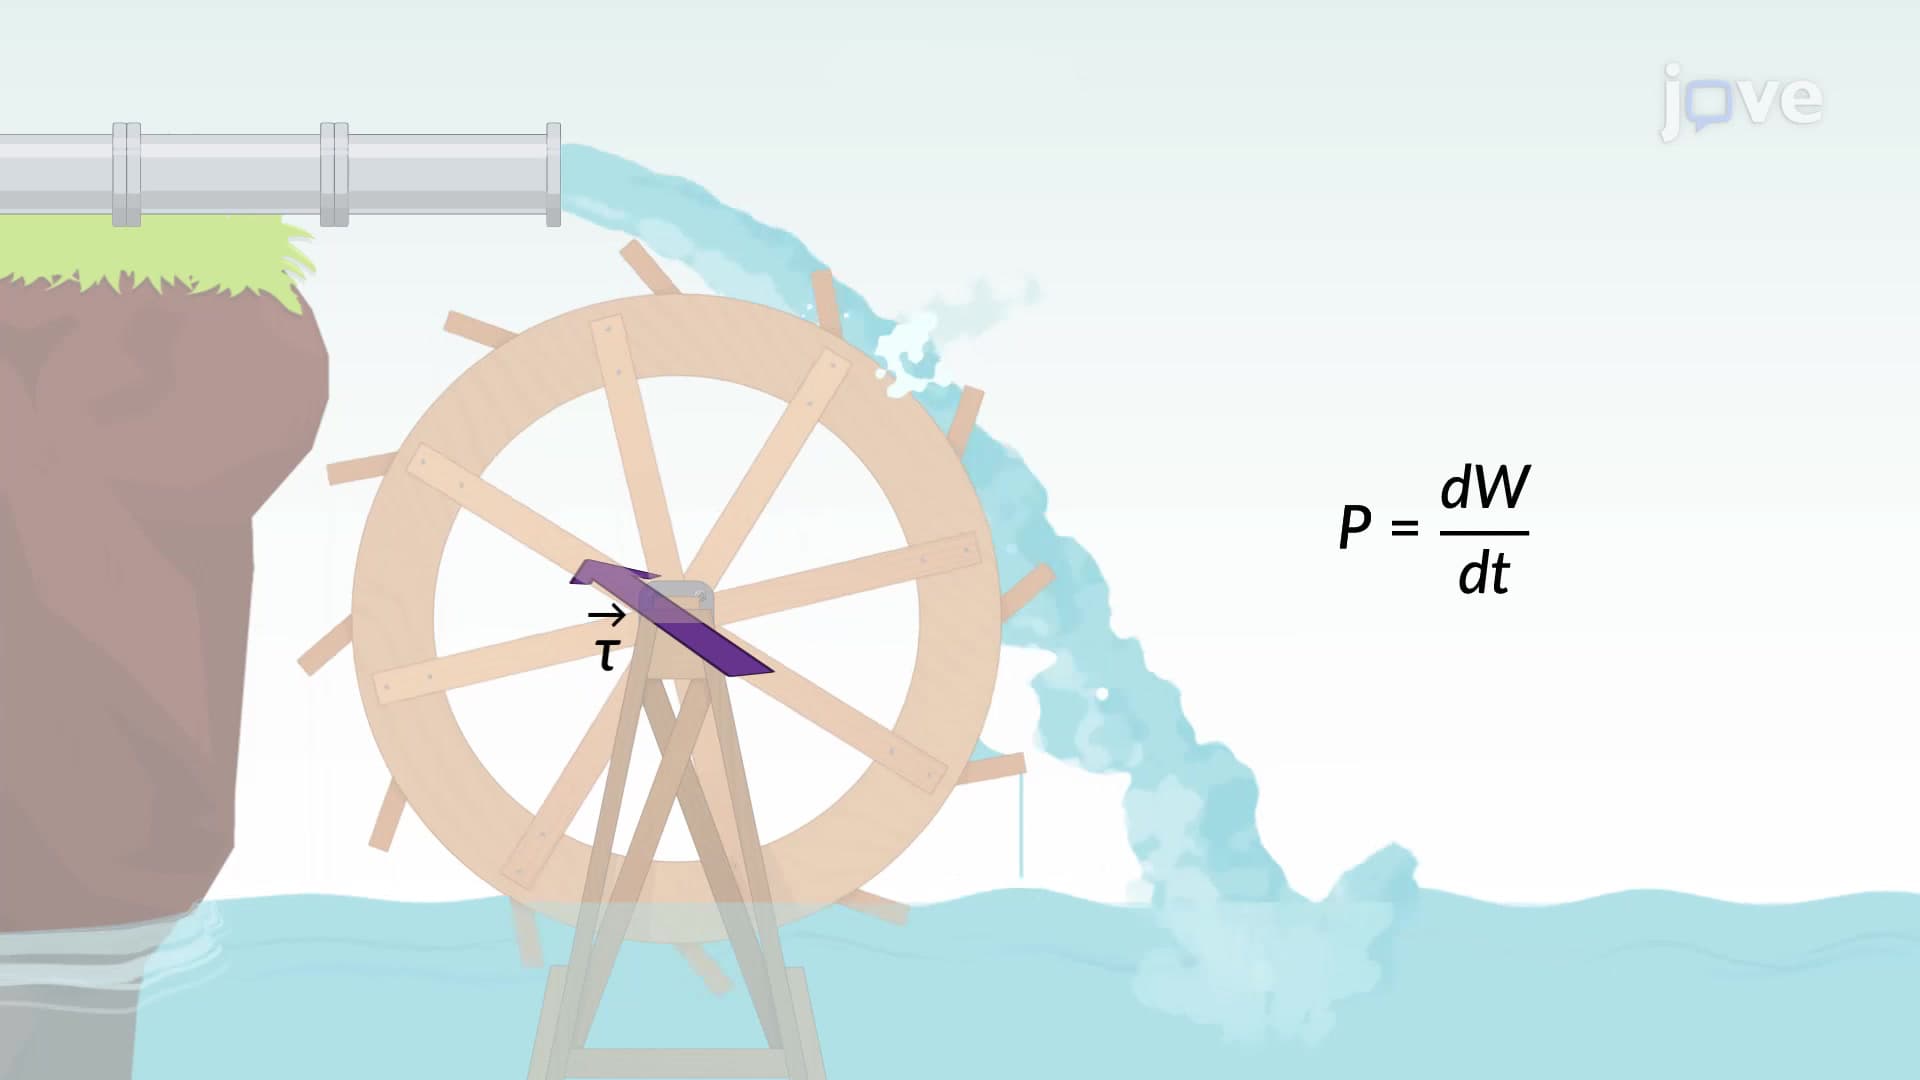
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis...
 01:10
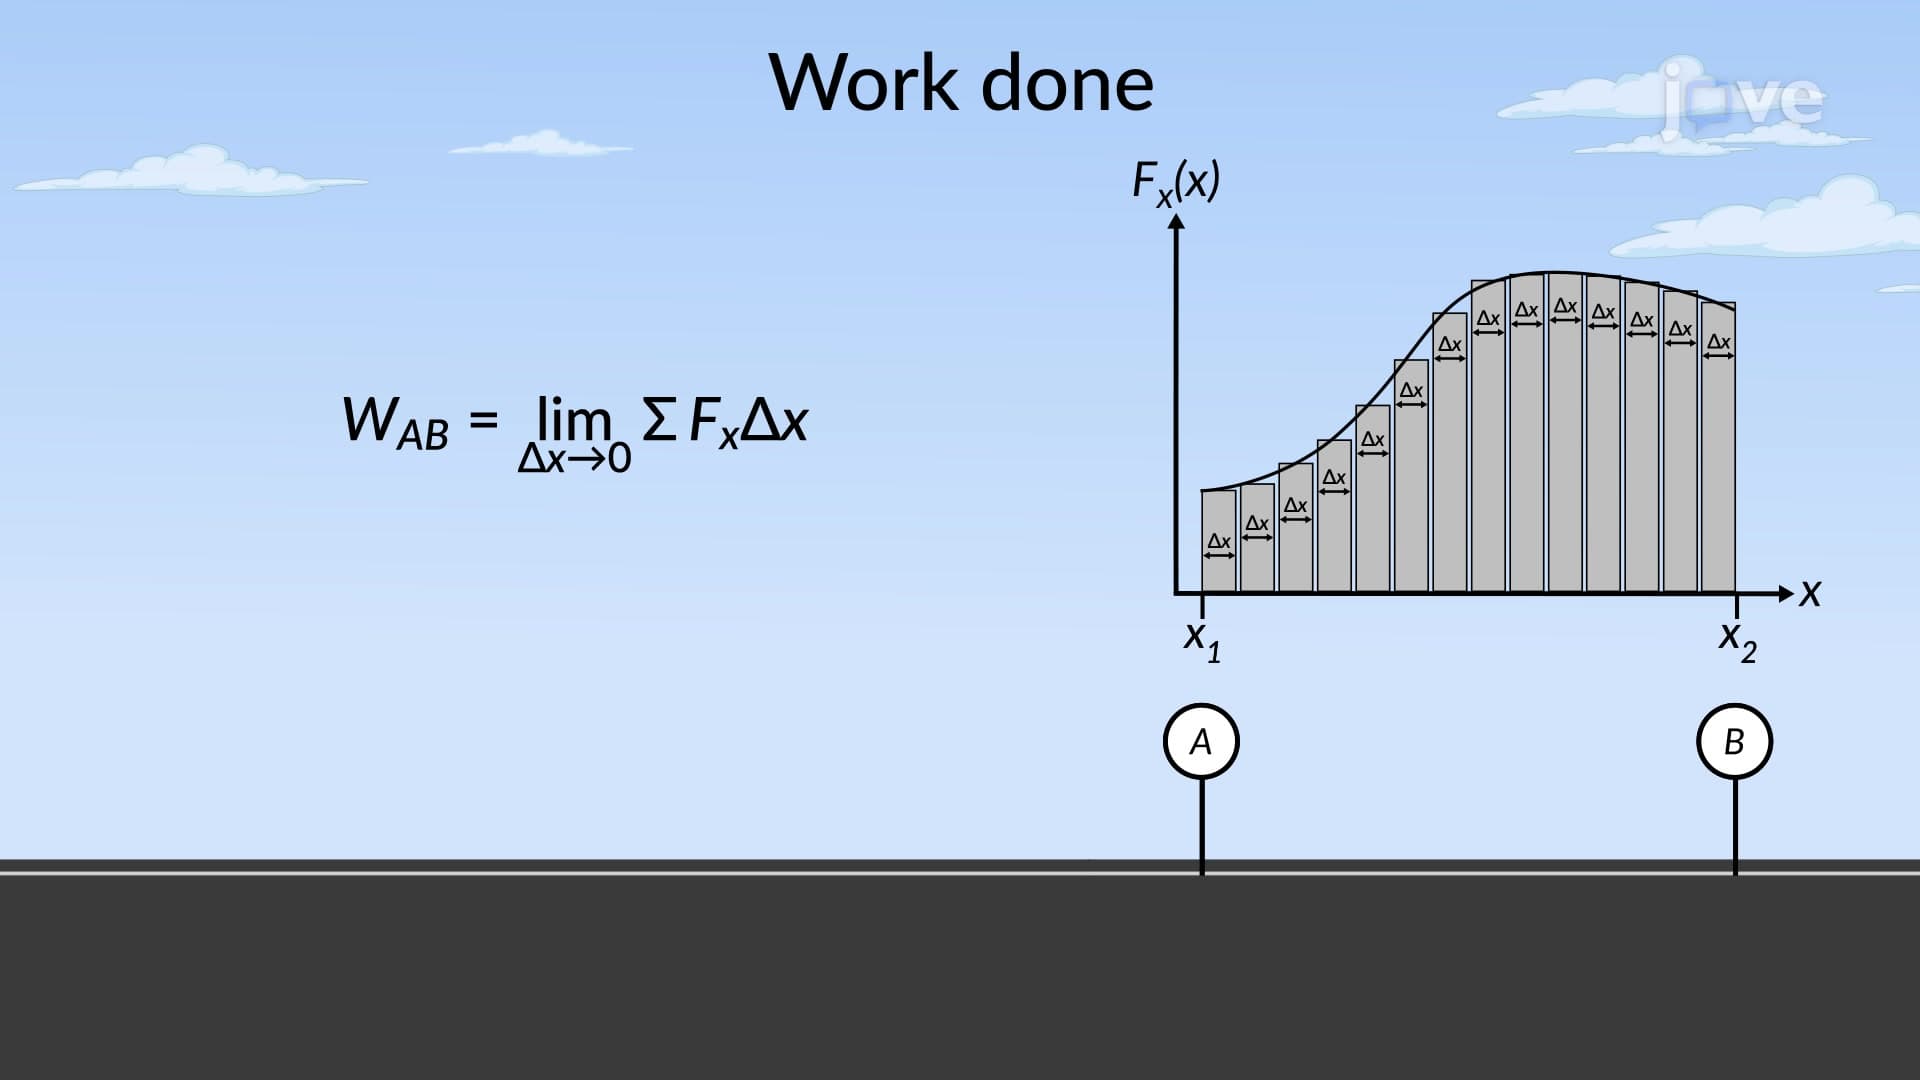
Work and Energy for Variable Forces
 01:14
Conservative Forces