Related Experiment Video
Updated: Jul 20, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Passivity based nonlinear model predictive control (PNMPC) of multi-robot systems for space applications
Serdar Kalaycioglu1, Anton De Ruiter1
1Department of Aerospace Engineering, Toronto Metropolitan University, Toronto, ON, Canada.

Abstract:
In the past 2 decades, there has been increasing interest in autonomous multi-robot systems for space use. They can assemble space structures and provide services for other space assets. The utmost significance lies in the performance, stability, and robustness of these space operations. By considering system dynamics and constraints, the Model Predictive Control (MPC) framework optimizes performance. Unlike other methods, standard MPC can offer greater robustness due to its receding horizon nature. However, current literature on MPC application to space robotics primarily focuses on linear models, which is not suitable for highly non-linear multi-robot systems. Although Nonlinear MPC (NMPC) shows promise for free-floating space manipulators, current NMPC applications are limited to unconstrained non-linear systems and do not guarantee closed-loop stability. This paper introduces a novel approach to NMPC using the concept of passivity to multi-robot systems for space applications. By utilizing a passivity-based state constraint and a terminal storage function, the proposed PNMPC scheme ensures closed-loop stability and a superior performance. Therefore, this approach offers an alternative method to the control Lyapunov function for control of non-linear multi-robot space systems and applications, as stability and passivity exhibit a close relationship. Finally, this paper demonstrates that the benefits of passivity-based concepts and NMPC can be combined into a single NMPC scheme that maintains the advantages of each, including closed-loop stability through passivity and good performance through one-line optimization in NMPC.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:13
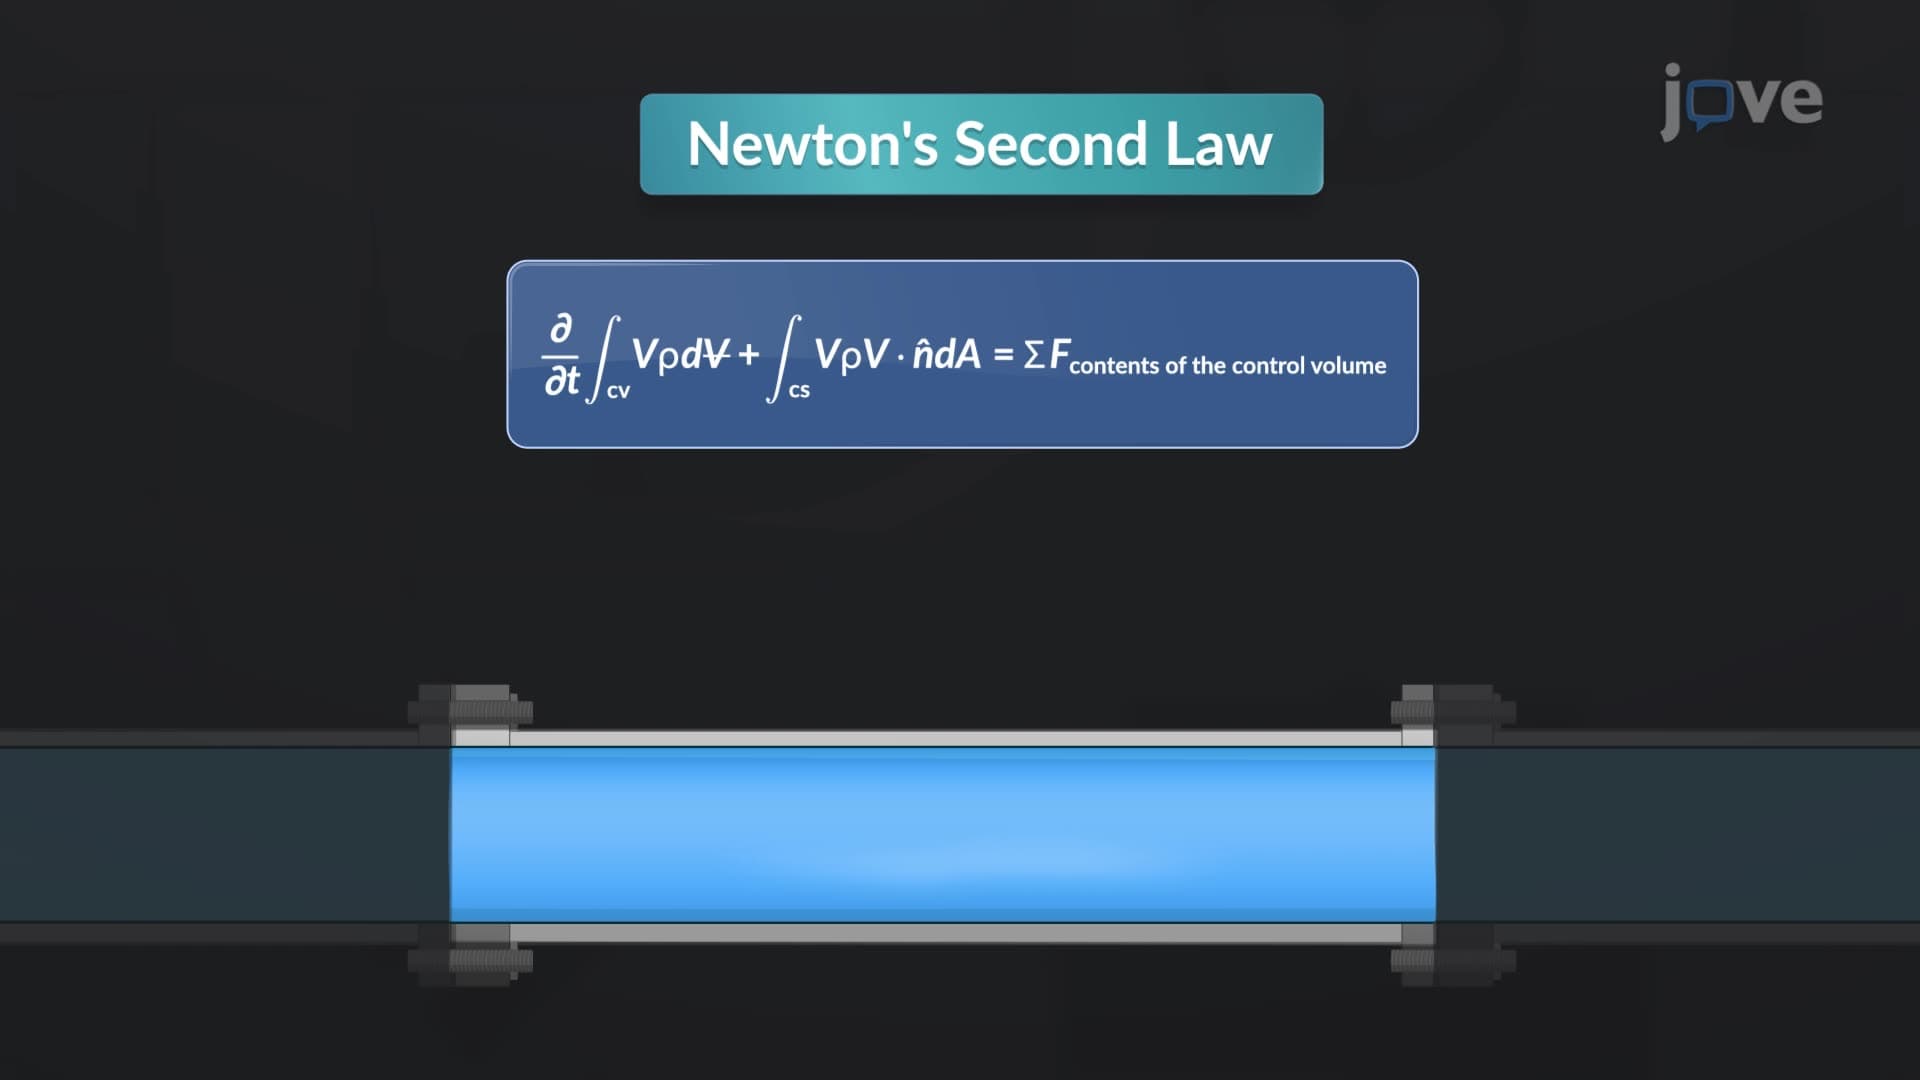
Linear Momentum in Control Volume