Related Experiment Video
Updated: Jul 20, 2025
06:42

Generation and Coherent Control of Pulsed Quantum Frequency Combs
Published on: June 8, 2018
9.0K
Retracted: A Novel of New 7D Hyperchaotic System with Self-Excited Attractors and Its Hybrid Synchronization
Computational Intelligence and Neuroscience
|August 4, 2023

Abstract:
[This retracts the article DOI: 10.1155/2021/3081345.].

Related Concept Videos
 01:24
One-Degree-of-Freedom System
517
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
517
 01:18
Second Order systems II
130
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
130
 01:23
Root Loci for Positive-Feedback Systems
146
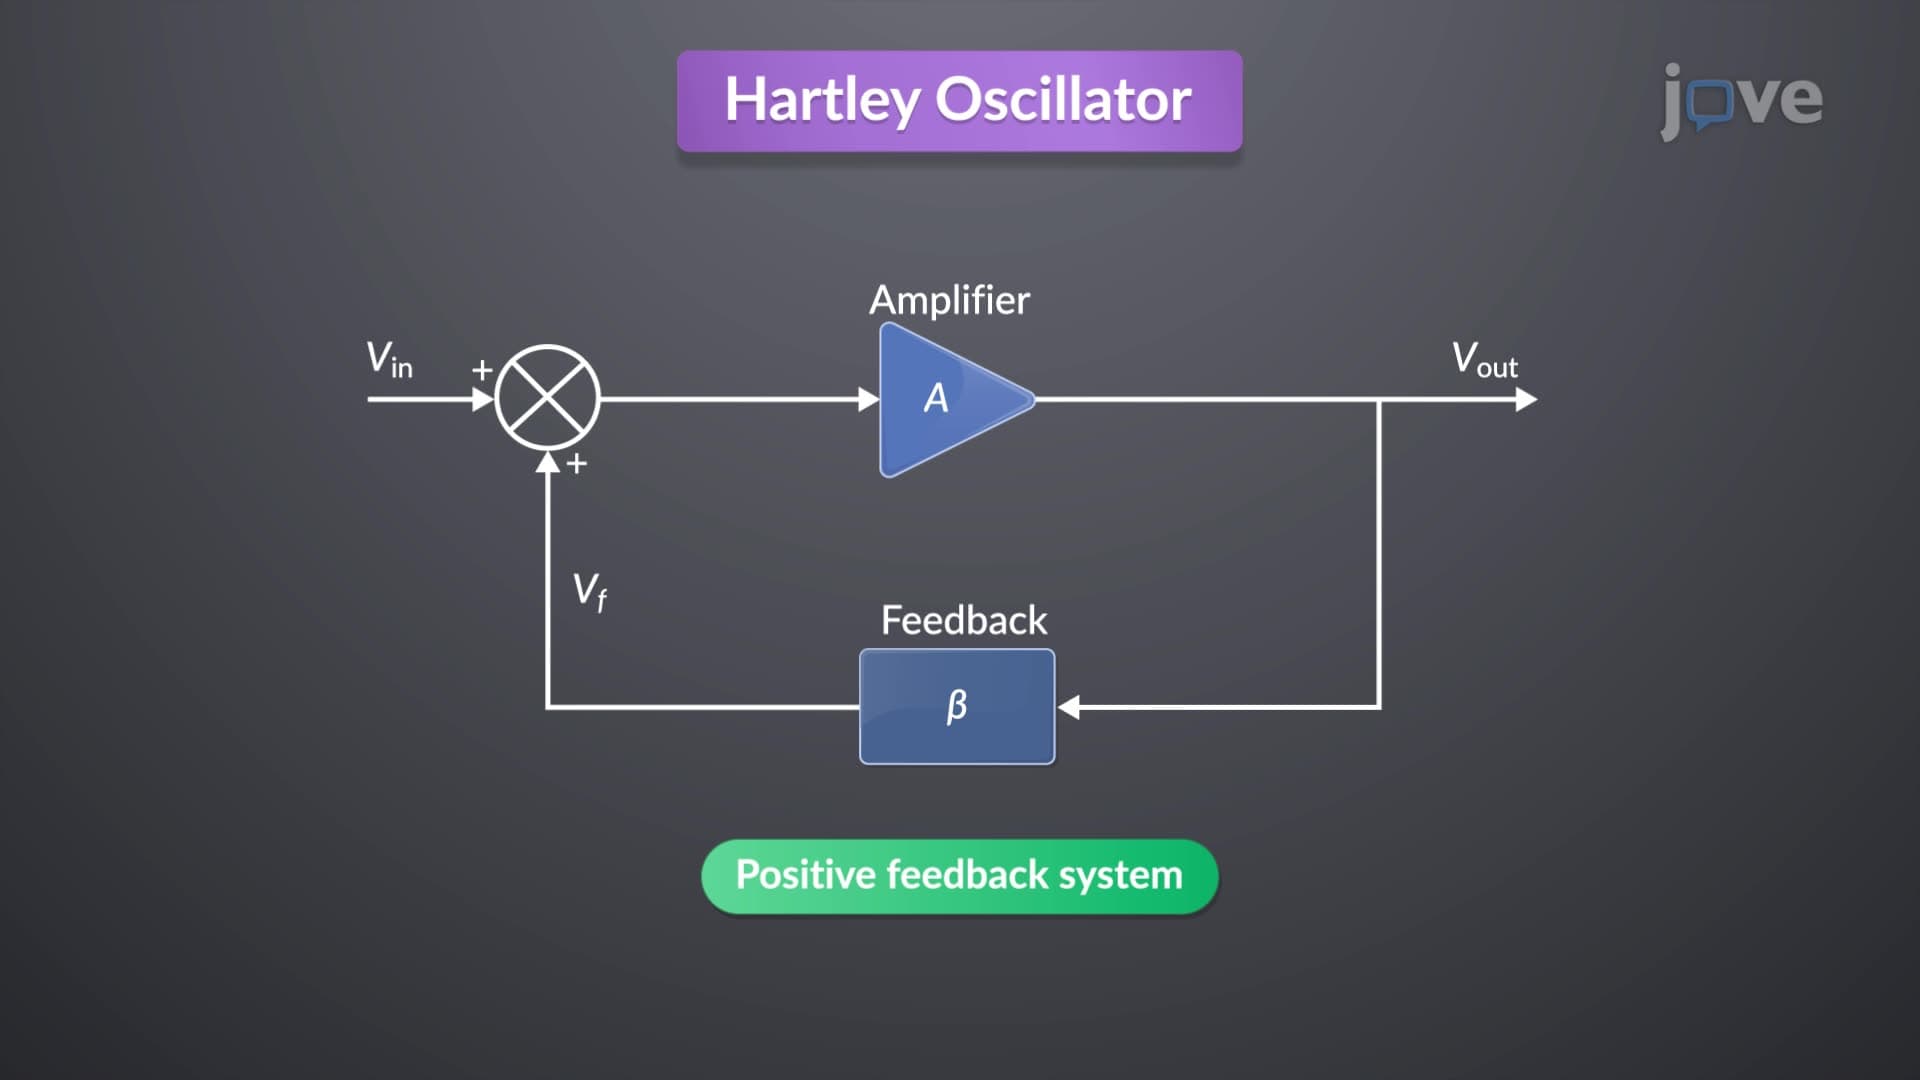
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
146
 01:24
Pole and System Stability
329
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
329
 01:06
Forced Oscillations
6.6K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.6K
 01:30
Simplified Synchronous Machine Model
276
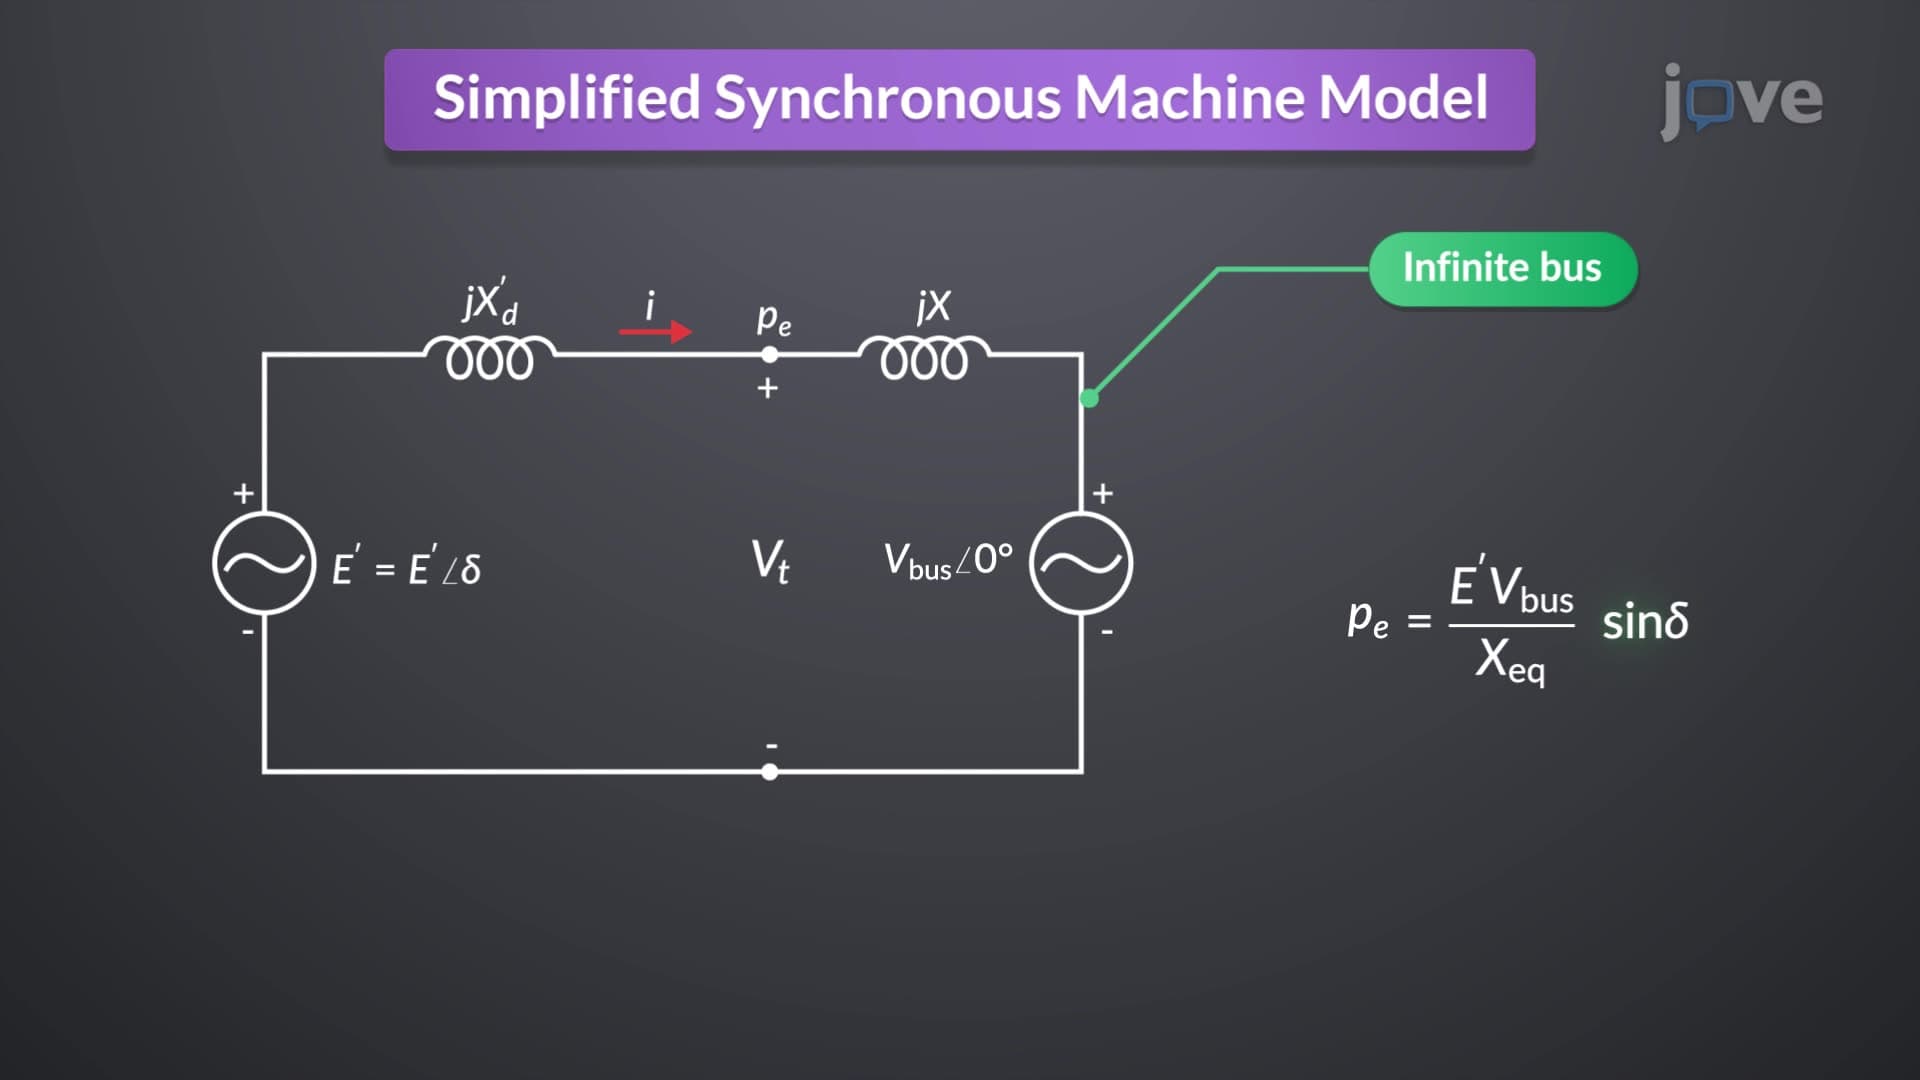
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
276