Related Experiment Video
Updated: Jul 19, 2025

Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
Computing geodesic paths encoding a curvature prior for curvilinear structure tracking
Da Chen1, Jean-Marie Mirebeau2, Minglei Shu1
1Shandong Artificial Intelligence Institute, Qilu University of Technology (Shandong Academy of Sciences), Jinan 250014, China.

Abstract:
In this paper, we introduce an efficient method for computing curves minimizing a variant of the Euler-Mumford elastica energy, with fixed endpoints and tangents at these endpoints, where the bending energy is enhanced with a user-defined and data-driven scalar-valued term referred to as the curvature prior. In order to guarantee that the globally optimal curve is extracted, the proposed method involves the numerical computation of the viscosity solution to a specific static Hamilton-Jacobi-Bellman (HJB) partial differential equation (PDE). For that purpose, we derive the explicit Hamiltonian associated with this variant model equipped with a curvature prior, discretize the resulting HJB PDE using an adaptive finite difference scheme, and solve it in a single pass using a generalized fast-marching method. In addition, we also present a practical method for estimating the curvature prior values from image data, designed for the task of accurately tracking curvilinear structure centerlines. Numerical experiments on synthetic and real-image data illustrate the advantages of the considered variant of the elastica model with a prior curvature enhancement in complex scenarios where challenging geometric structures appear.

Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
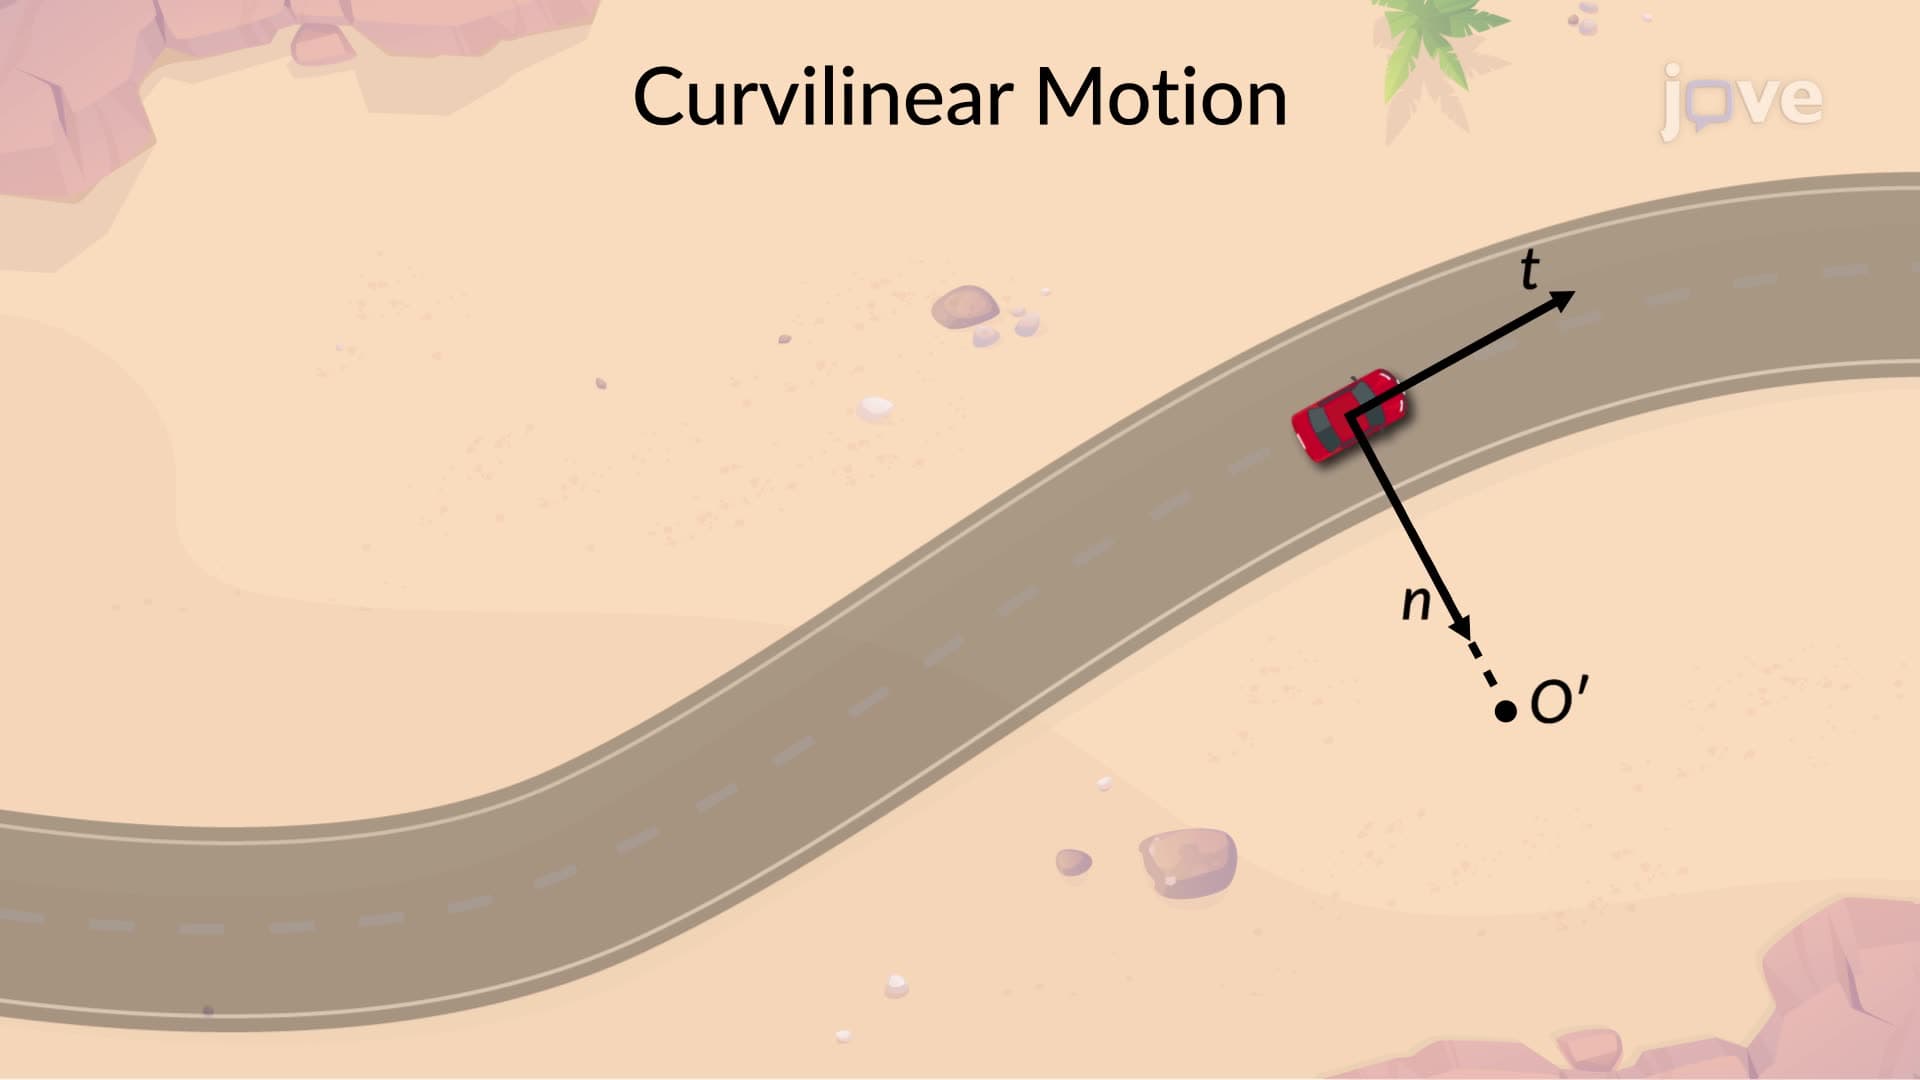
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:19
Degree of Curvature and Radius of Curvature
 01:26
Field Procedure for Staking Out Curves
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...