Related Experiment Video
Updated: Jul 19, 2025
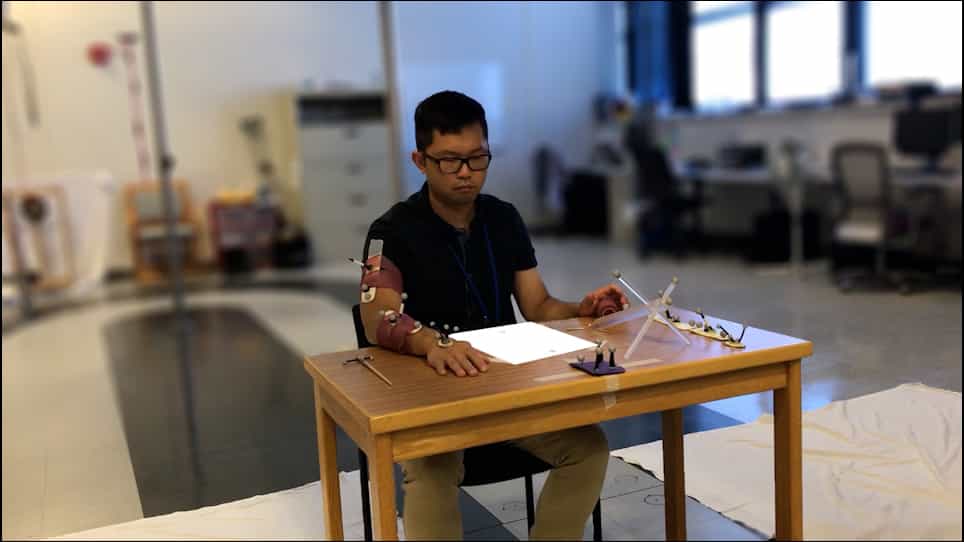

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Depth and direction effects in the prediction of static and shifted reaching goals from kinematics
A Bosco1,2, M Filippini3,4, D Borra5
1Department of Biomedical and Neuromotor Sciences, University of Bologna, Bologna, Italy. annalisa.bosco2@unibo.it.

Abstract:
The kinematic parameters of reach-to-grasp movements are modulated by action intentions. However, when an unexpected change in visual target goal during reaching execution occurs, it is still unknown whether the action intention changes with target goal modification and which is the temporal structure of the target goal prediction. We recorded the kinematics of the pointing finger and wrist during the execution of reaching movements in 23 naïve volunteers where the targets could be located at different directions and depths with respect to the body. During the movement execution, the targets could remain static for the entire duration of movement or shifted, with different timings, to another position. We performed temporal decoding of the final goals and of the intermediate trajectory from the past kinematics exploiting a recurrent neural network. We observed a progressive increase of the classification performance from the onset to the end of movement in both horizontal and sagittal dimensions, as well as in decoding shifted targets. The classification accuracy in decoding horizontal targets was higher than the classification accuracy of sagittal targets. These results are useful for establishing how human and artificial agents could take advantage from the observed kinematics to optimize their cooperation in three-dimensional space.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
Kinematic Equations: Problem Solving
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...