Related Experiment Video
Updated: Jul 19, 2025
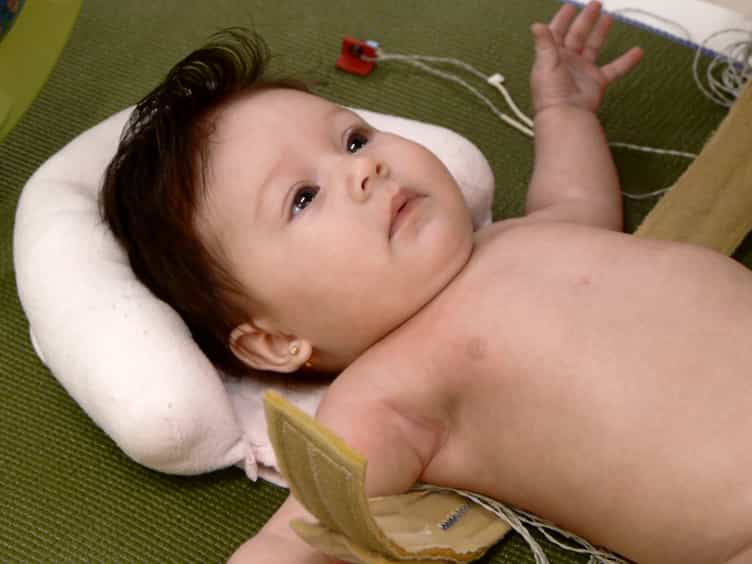

Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Bio-inspired, task-free continual learning through activity regularization
Francesco Lässig1, Pau Vilimelis Aceituno2, Martino Sorbaro2,3
1Institute of Neuroinformatics University of Zürich and ETH, Zürich, Switzerland. flaessig@ethz.ch.

Abstract:
The ability to sequentially learn multiple tasks without forgetting is a key skill of biological brains, whereas it represents a major challenge to the field of deep learning. To avoid catastrophic forgetting, various continual learning (CL) approaches have been devised. However, these usually require discrete task boundaries. This requirement seems biologically implausible and often limits the application of CL methods in the real world where tasks are not always well defined. Here, we take inspiration from neuroscience, where sparse, non-overlapping neuronal representations have been suggested to prevent catastrophic forgetting. As in the brain, we argue that these sparse representations should be chosen on the basis of feed forward (stimulus-specific) as well as top-down (context-specific) information. To implement such selective sparsity, we use a bio-plausible form of hierarchical credit assignment known as Deep Feedback Control (DFC) and combine it with a winner-take-all sparsity mechanism. In addition to sparsity, we introduce lateral recurrent connections within each layer to further protect previously learned representations. We evaluate the new sparse-recurrent version of DFC on the split-MNIST computer vision benchmark and show that only the combination of sparsity and intra-layer recurrent connections improves CL performance with respect to standard backpropagation. Our method achieves similar performance to well-known CL methods, such as Elastic Weight Consolidation and Synaptic Intelligence, without requiring information about task boundaries. Overall, we showcase the idea of adopting computational principles from the brain to derive new, task-free learning algorithms for CL.
More Related Videos

Related Concept Videos
 01:12
Observational Learning
 01:22
Purposive Learning
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:18
Introduction to Learning
In contrast to learned behaviors, unlearned behaviors such as crying, sexual...
 01:27
Associative Learning
Classical conditioning, also known...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...