
Stability of Delay Hopfield Neural Networks with Generalized Riemann-Liouville Type Fractional Derivative
Ravi P Agarwal1, Snezhana Hristova2
1Department of Mathematics, Texas A & M University-Kingsville, Kingsville, TX 78363, USA.

Abstract:
The general delay Hopfield neural network is studied. We consider the case of time-varying delay, continuously distributed delays, time-varying coefficients, and a special type of a Riemann-Liouville fractional derivative (GRLFD) with an exponential kernel. The kernels of the fractional integral and the fractional derivative in this paper are Sonine kernels and satisfy the first and the second fundamental theorems in calculus. The presence of delays and GRLFD in the model require a special type of initial condition. The applied GRLFD also requires a special definition of the equilibrium of the model. A constant equilibrium of the model is defined. An inequality for Lyapunov type of convex functions with the applied GRLFD is proved. It is combined with the Razumikhin method to study stability properties of the equilibrium of the model. As a partial case we apply quadratic Lyapunov functions. We prove some comparison results for Lyapunov function connected deeply with the applied GRLFD and use them to obtain exponential bounds of the solutions. These bounds are satisfied for intervals excluding the initial time. Also, the convergence of any solution of the model to the equilibrium at infinity is proved. An example illustrating the importance of our theoretical results is also included.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:18
Second Order systems II
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:30
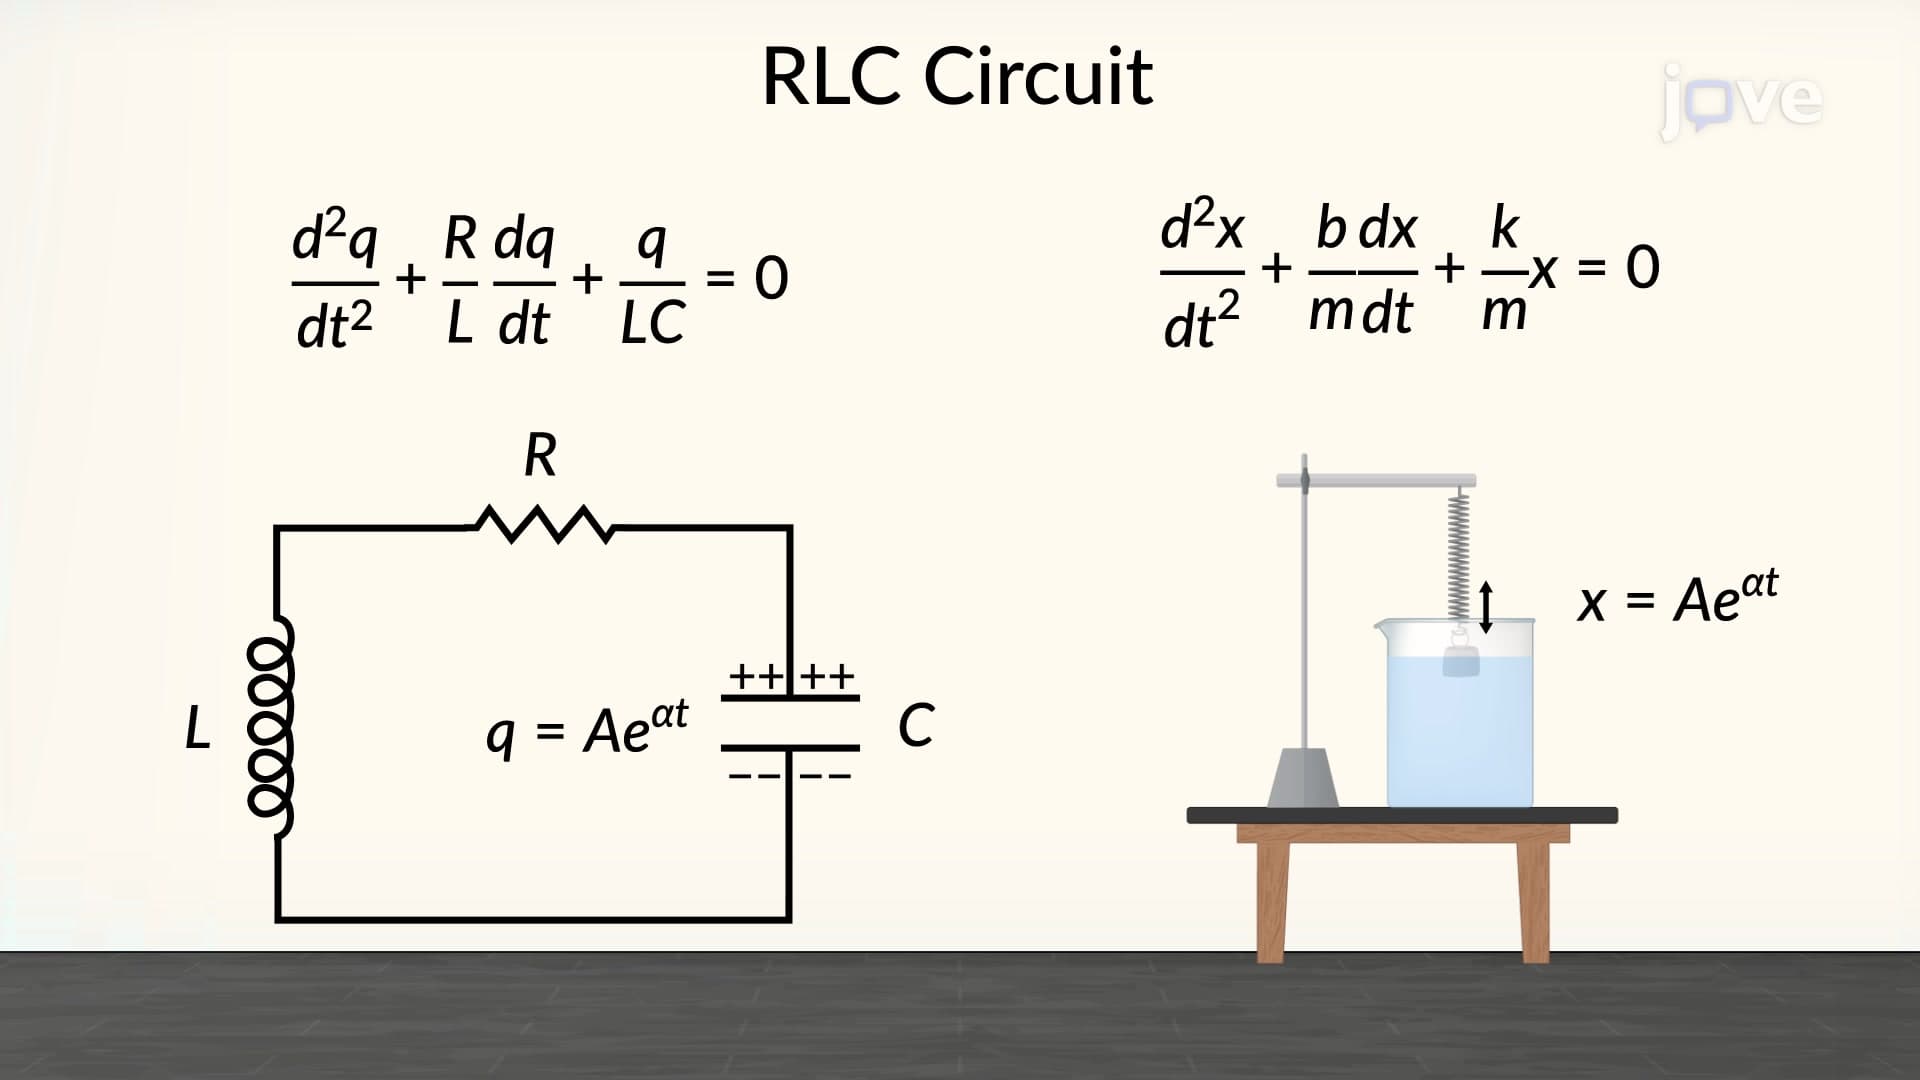
RLC Circuit as a Damped Oscillator
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...