Related Experiment Video
Updated: Jul 18, 2025
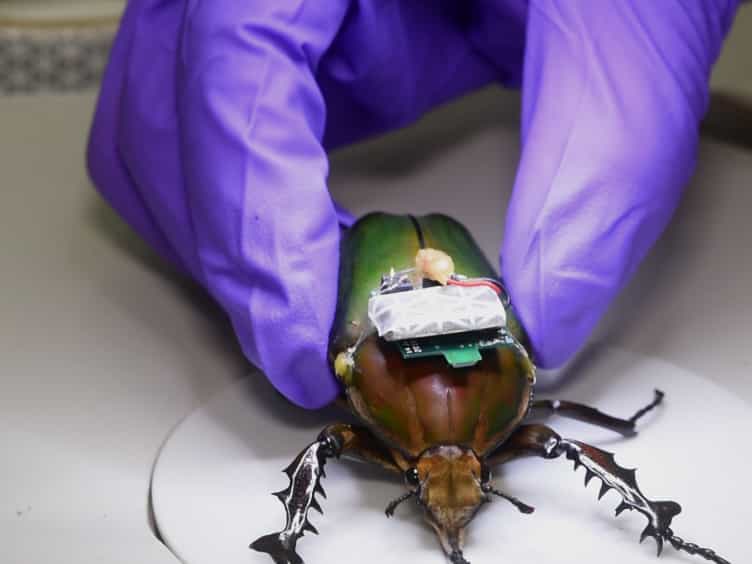

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Review of the Flight Control Method of a Bird-like Flapping-Wing Air Vehicle
Xiaoqing Fang1, Yian Wen2, Zhida Gao1
1College of Automotive and Mechanical Engineering, Changsha University of Science & Technology, Changsha 410114, China.

Abstract:
The Bird-like Flapping-wing Air Vehicle (BFAV) is a robotic innovation that emulates the flight patterns of birds. In comparison to fixed-wing and rotary-wing air vehicles, the BFAV offers superior attributes such as stealth, enhanced maneuverability, strong adaptability, and low noise, which render the BFAV a promising prospect for numerous applications. Consequently, it represents a crucial direction of research in the field of air vehicles for the foreseeable future. However, the flapping-wing vehicle is a nonlinear and unsteady system, posing significant challenges for BFAV to achieve autonomous flying since it is difficult to analyze and characterize using traditional methods and aerodynamics. Hence, flight control as a major key for flapping-wing air vehicles to achieve autonomous flight garners considerable attention from scholars. This paper presents an exposition of the flight principles of BFAV, followed by a comprehensive analysis of various significant factors that impact bird flight. Subsequently, a review of the existing literature on flight control in BFAV is conducted, and the flight control of BFAV is categorized into three distinct components: position control, trajectory tracking control, and formation control. Additionally, the latest advancements in control algorithms for each component are deliberated and analyzed. Ultimately, a projection on forthcoming directions of research is presented.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:54
Convergent Evolution
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
Lift
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...