Related Experiment Video
Updated: Jul 17, 2025

Experiments on Ultrasonic Lubrication Using a Piezoelectrically-assisted Tribometer and Optical Profilometer
Published on: September 28, 2015
A bipedal cooperative drive method for the stick-slip piezoelectric actuator to achieve smooth motion
Zhaochen Ding1, Huadong Yu1, Xiaoqin Zhou1
1School of Mechanical and Aerospace Engineering, Jilin University, Changchun, Jilin 130022, China.

Abstract:
Existing kinds of stepping piezoelectric actuators have difficulty in maintaining smooth stepping characteristics in motion, especially with applied loads, because they are limited by their driving principle and structural design. However, non-smooth stepping characteristics not only reduce the output performance of piezoelectric actuators but also greatly limit the applications of piezoelectric actuators. In this paper, a bipedal cooperative drive method for the stick-slip actuator is proposed to improve stepping characteristics and achieve smooth motion under different conditions. Two flexible driving feet alternately push the rotor to rotate clockwise. Experimental results show that the stepping characteristics vary with the driving voltage, and the displacement curve transitions from non-smooth to smooth to sudden jump as the driving voltage rises. Furthermore, the displacement curves can maintain good smoothness within a horizontal load range of 20-30 g. The maximum angular speed of the designed actuator is 1452 mrad/s when the driving voltage and driving frequency are 100 V and 1400 Hz, respectively. These features help broaden the practical application of actuators.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:59
Modeling and Experimental Analysis of the Single-Shaft Coaxial Motor-Pump Assembly in Electrohydrostatic Actuators
Published on: June 13, 2022
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design
 01:05
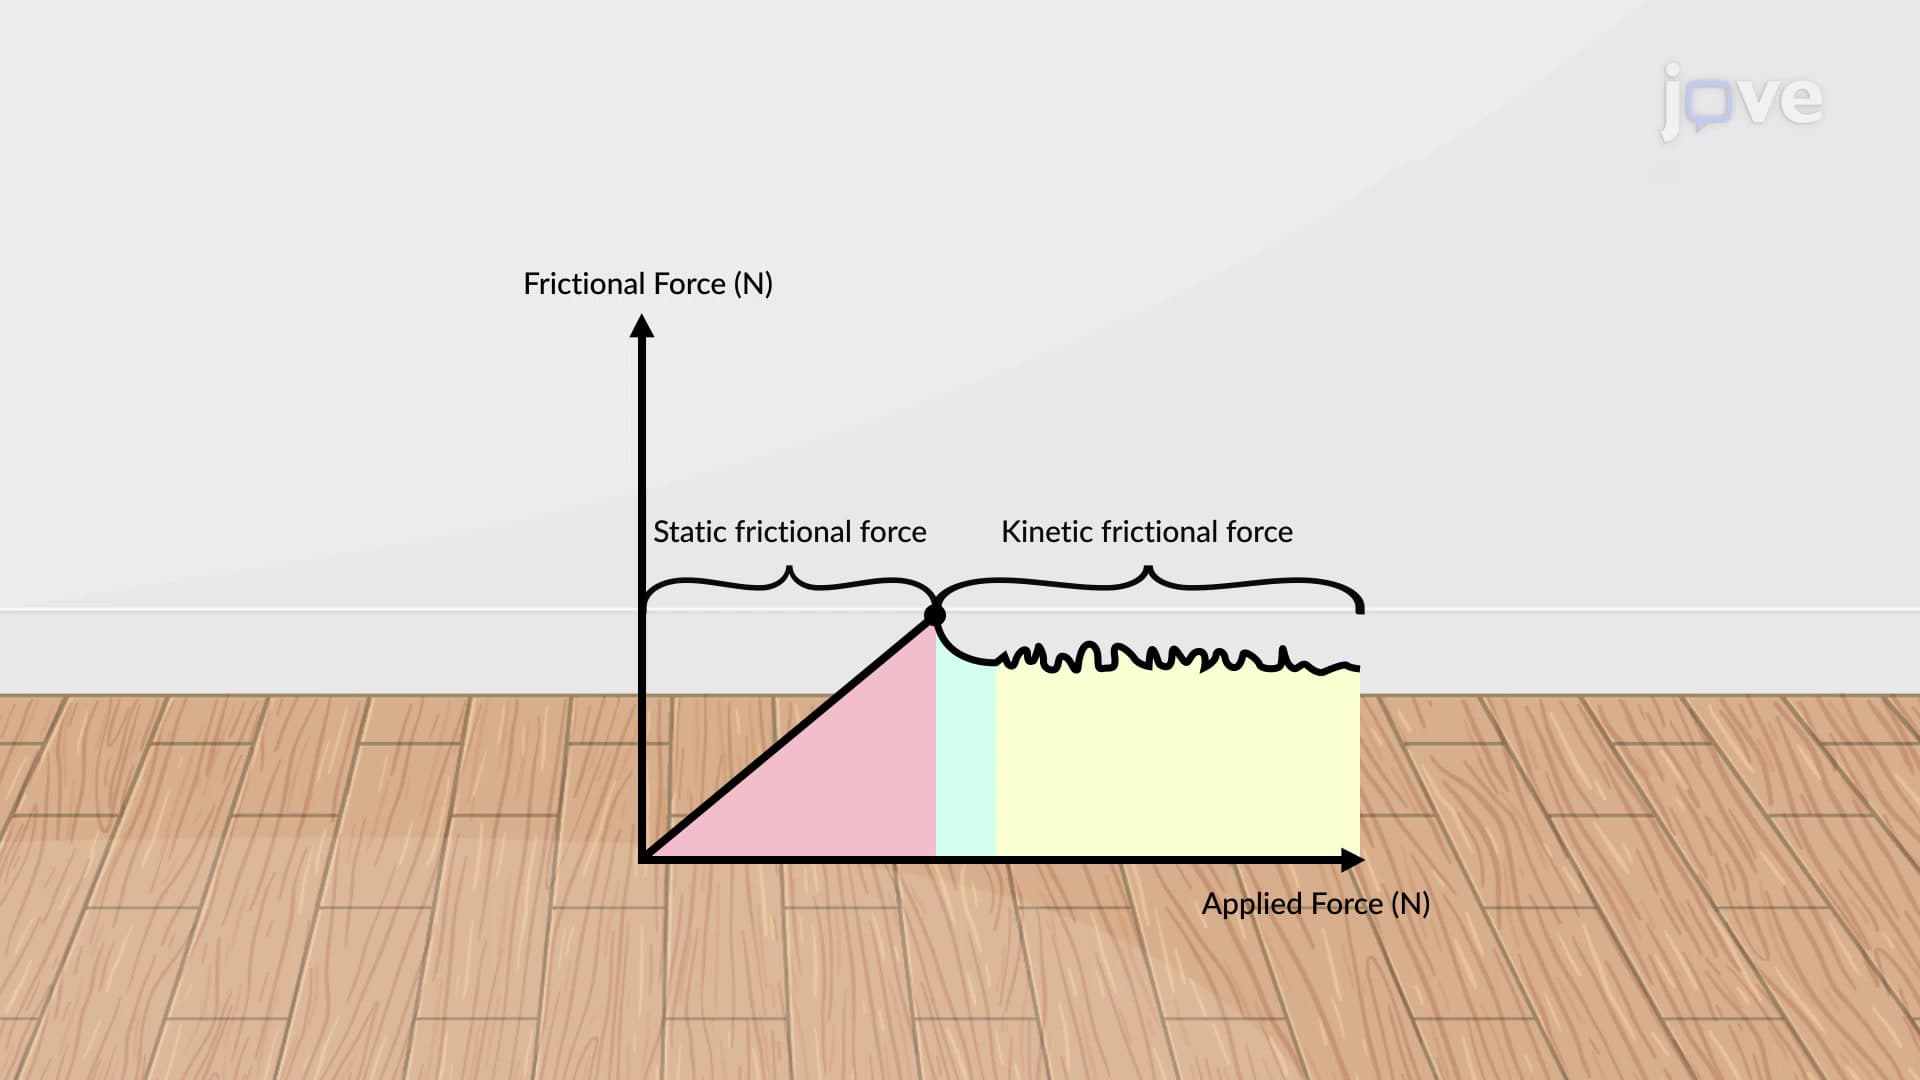
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...