Related Experiment Video
Updated: Jul 16, 2025
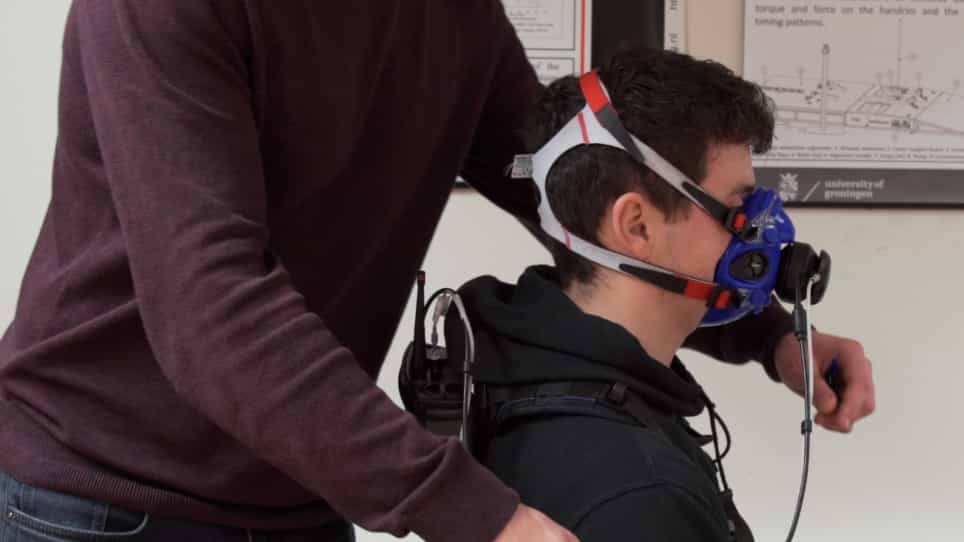

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Moving forward: A review of continuous kinetics and kinematics during handcycling propulsion
Kellie M Halloran1, Michael D K Focht1, Alexander Teague2
1Department of Mechanical Science and Engineering, University of Illinois Urbana-Champaign, United States of America.

Abstract:
Wheelchair users (WCUs) face high rates of shoulder overuse injuries. As exercise is recommended to reduce cardiovascular disease prevalent among WCUs, it is becoming increasingly important to understand the mechanisms behind shoulder soft-tissue injury in WCUs. Understanding the kinetics and kinematics during upper-limb propulsion is the first step toward evaluating soft-tissue injury risk in WCUs. This paper examines continuous kinetic and kinematic data available in the literature. Attach-unit and recumbent handcycling are examined and compared. Athletic modes of propulsion such as recumbent handcycling are important considering the higher contact forces, speed, and power outputs experienced during these activities that could put users at increased risk of injury. Understanding the underlying kinetics and kinematics during various propulsion modes can lend insight into shoulder loading, and therefore injury risk, during these activities and inform future exercise guidelines for WCUs.
More Related Videos

Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:16
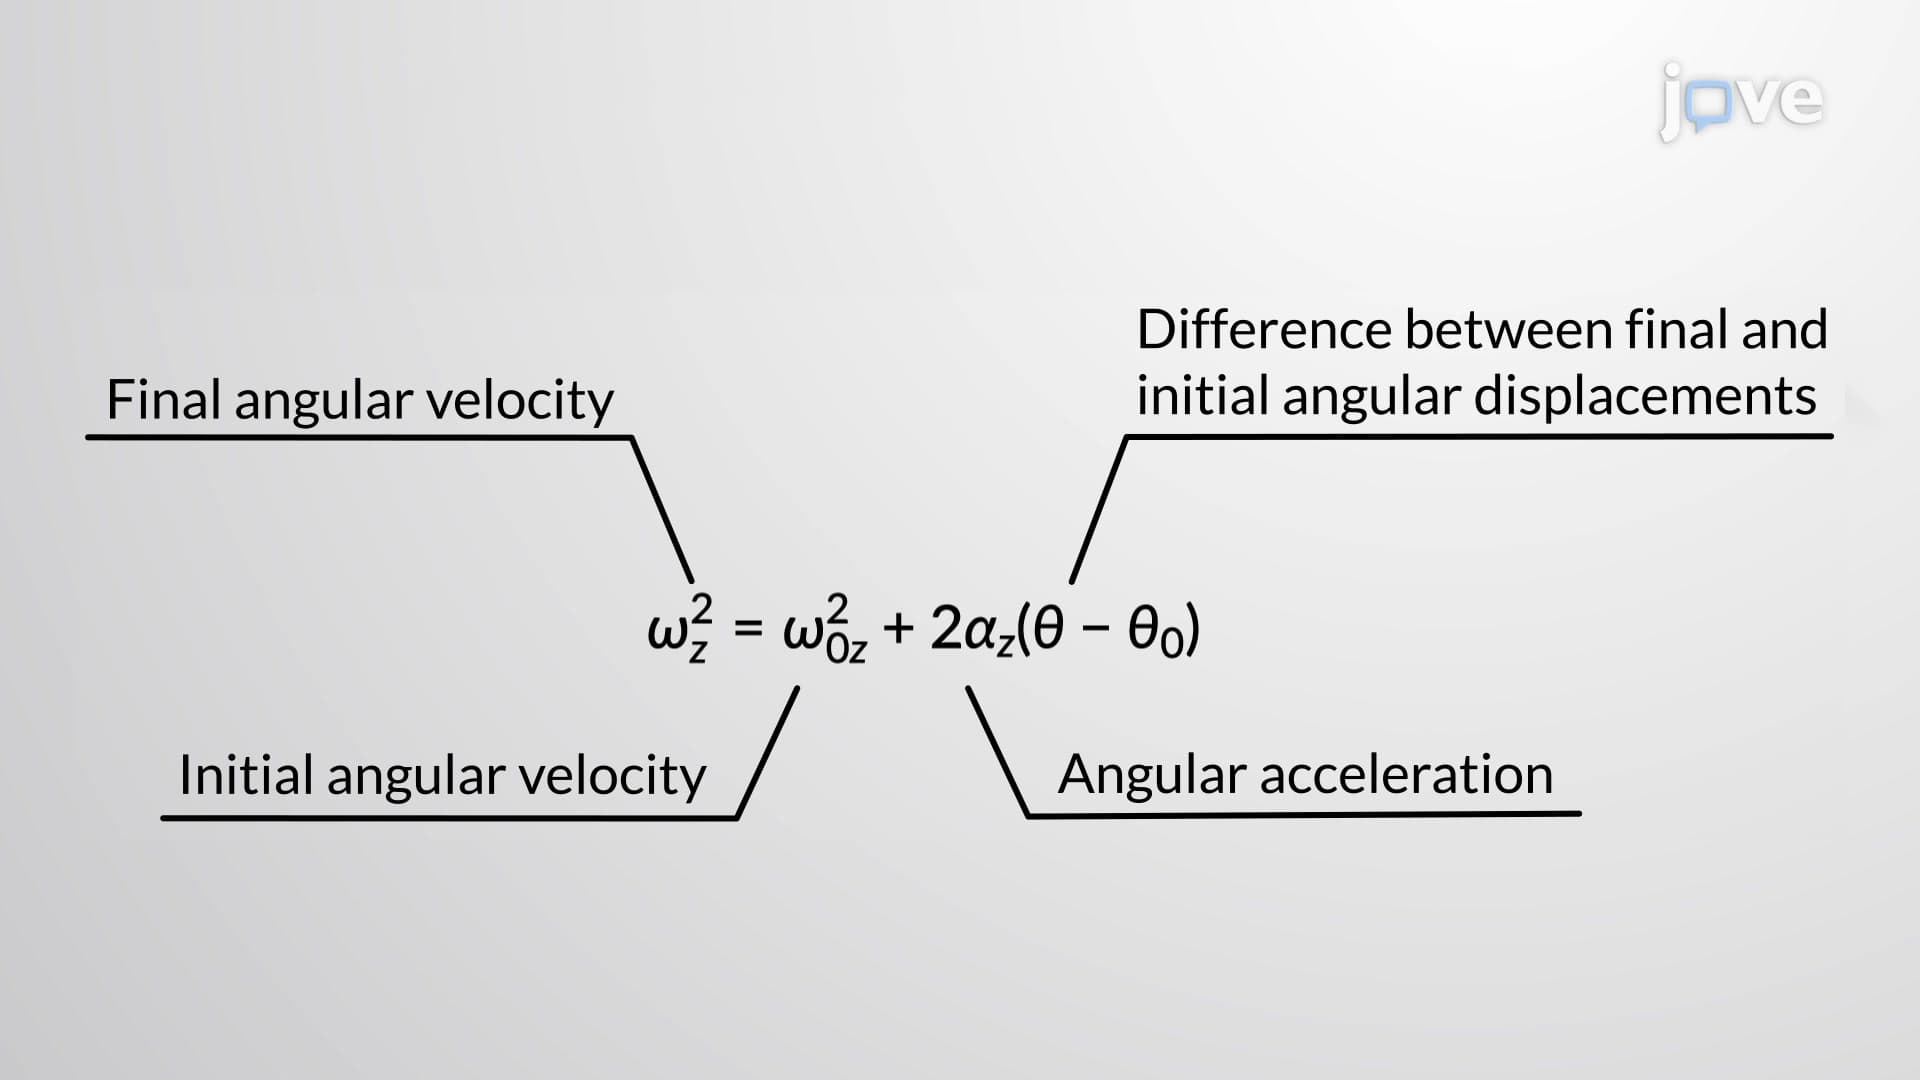
Rotation with Constant Angular Acceleration - II
The first...
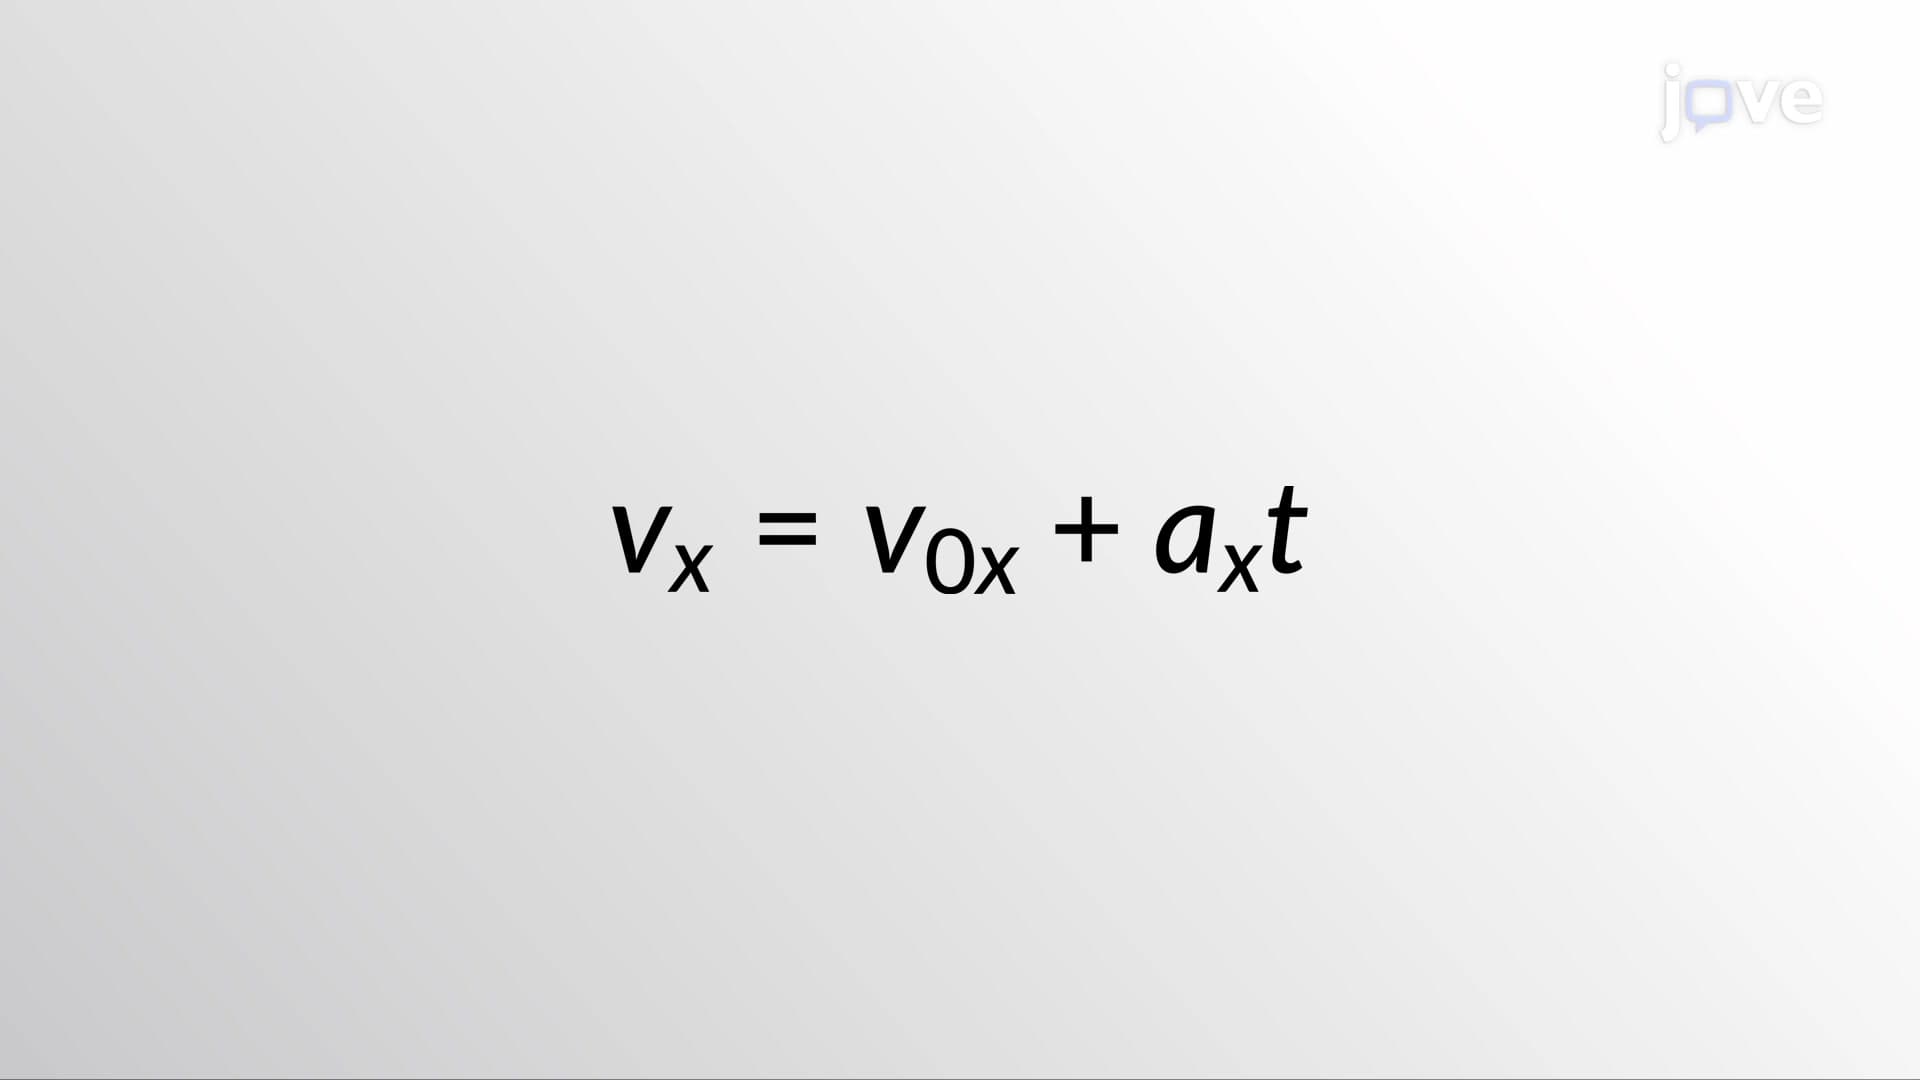 01:26
Kinematic Equations - I