Related Experiment Video
Updated: Jul 15, 2025
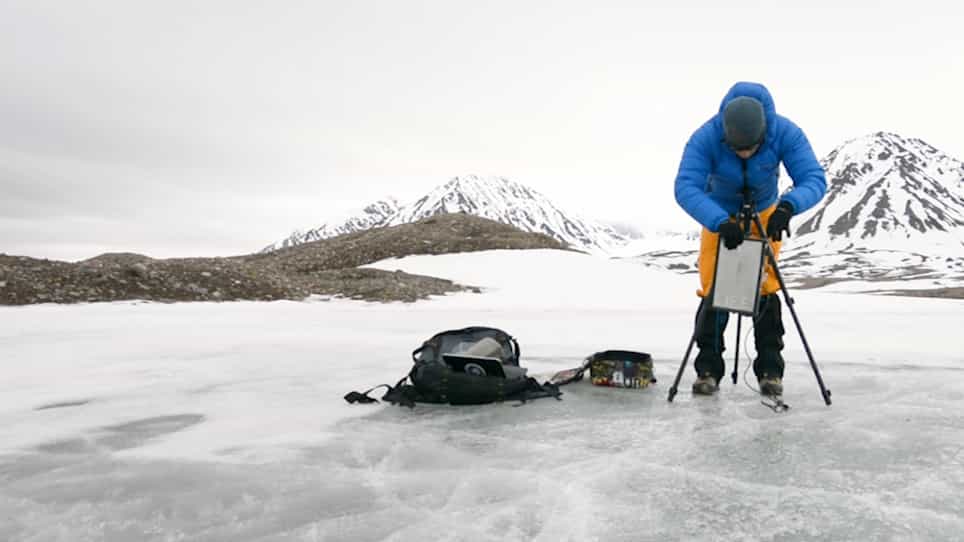
Laser-Induced Fluorescence Emission L.I.F.E. as Novel Non-Invasive Tool for In-Situ Measurements of Biomarkers in Cryospheric Habitats
Published on: October 26, 2019
LFVB-BioSLAM: A Bionic SLAM System with a Light-Weight LiDAR Front End and a Bio-Inspired Visual Back End
Ruilan Gao1, Zeyu Wan1, Sitong Guo1
1State Key Laboratory of Industrial Control Technology, College of Control Science and Engineering, Zhejiang University, Hangzhou 310027, China.

Abstract:
Simultaneous localization and mapping (SLAM) is one of the crucial techniques applied in autonomous robot navigation. The majority of present popular SLAM algorithms are built within probabilistic optimization frameworks, achieving high accuracy performance at the expense of high power consumption and latency. In contrast to robots, animals are born with the capability to efficiently and robustly navigate in nature, and bionic SLAM algorithms have received increasing attention recently. Current bionic SLAM algorithms, including RatSLAM, with relatively low accuracy and robustness, tend to fail in certain challenging environments. In order to design a bionic SLAM system with a novel framework and relatively high practicality, and to facilitate the development of bionic SLAM research, in this paper we present LFVB-BioSLAM, a bionic SLAM system with a light-weight LiDAR-based front end and a bio-inspired vision-based back end. We adopt a range flow-based LiDAR odometry as the front end of the SLAM system, providing the odometry estimation for the back end, and we propose a biologically-inspired back end processing algorithm based on the monocular RGB camera, performing loop closure detection and path integration. Our method is verified through real-world experiments, and the results show that LFVB-BioSLAM outperforms RatSLAM, a vision-based bionic SLAM algorithm, and RF2O, a laser-based horizontal planar odometry algorithm, in terms of accuracy and robustness.
Related Concept Videos
 02:16
Light Acquisition
 01:18
Imaging Biological Samples with Optical Microscopy
In optical microscopy, the specimen to be viewed is placed on a glass slide and clipped on the stage...
 01:16
Confocal Fluorescence Microscopy