Related Experiment Video
Updated: Jul 15, 2025
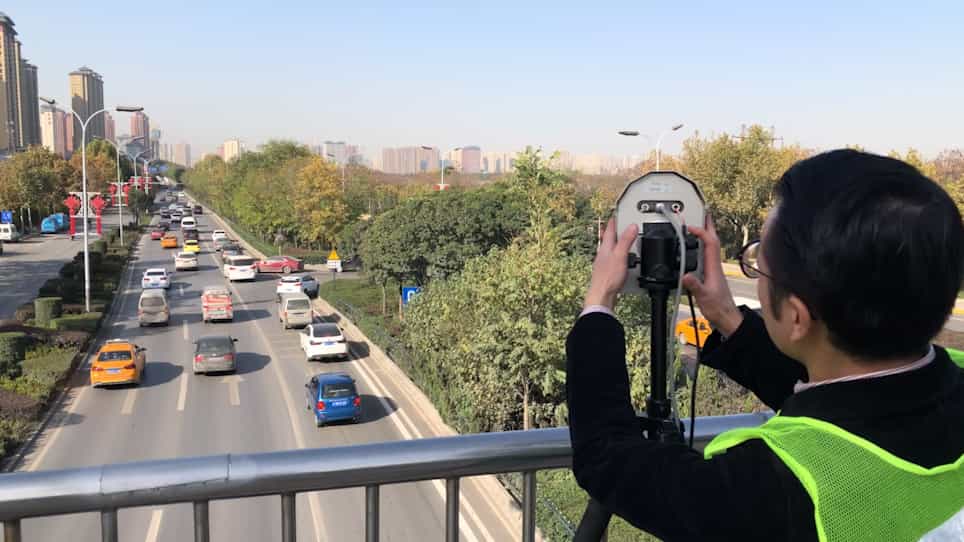
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
A cooperative control method for safer on-ramp merging process in heterogeneous traffic flow
Wenzhang Yang1, Changyin Dong1, Xu Chen1
1Jiangsu Key Laboratory of Urban ITS, Southeast University, Nanjing 211189, China; Jiangsu Province Collaborative Innovation Center of Modern Urban Traffic Technologies, Nanjing 211189, China; School of Transportation, Southeast University, Nanjing 211189, China.

Abstract:
The on-ramp area is a high-risk conflict zone where traffic accidents frequently occur. Connected and automated vehicles (CAVs) have the potential to enhance the safety of the merging process through appropriate cooperative control methods. This paper proposes a cooperative control method for safer on-ramp merging processes in heterogeneous traffic flow. Firstly, the gap selection process of ramp vehicles is described, thus all feasible virtual platoon results can be summarized. Next, the vehicle bond (VB) is used to describe the connection mode between vehicles within the virtual platoon. A two-layered gap selection function is proposed to ensure a safer merging process. The first layer aims to minimize the number of empty VBs, while the second layer considers fairness with respect to delay. To evaluate the control effectiveness, time exposed time-to-collision (TET), cumulative risk (CR), and conflict-potential mergence ratio (CPMR) are selected as the safety evaluation indicators. The simulation results show that the gap selection control moves the merging positions of ramp vehicles forward, resulting less risk of merging. It significantly enhances the safety of on-ramp merging without compromising traffic efficiency. At a flow rate of 650 veh/h for both the mainline and ramp, and a CAV penetration rate of 0.1-0.9, the gap selection control group achieves a decrease rate of about 0.3-0.6 for average TET and CR compared to the non-control group. In the pure CAV environment, the decrease rate can reach about 0.9. Sensitivity analysis indicates that the gap selection control is effective across varying flow rates and steady speeds. The optimal control effect is achieved when the length of the communication area ranges from 100 to 200 m.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:41
Social Traps
 01:17
Rolling Resistance: Problem Solving
 01:24
Laminar Flow: Problem Solving
 01:30
Control of Power Flow
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...