Related Experiment Video
Updated: Jul 13, 2025
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
Graph Reinforcement Learning-Based Decision-Making Technology for Connected and Autonomous Vehicles: Framework,
Qi Liu1, Xueyuan Li1, Yujie Tang2
1School of Mechanical Engineering, Beijing Institute of Technology, Beijing 100811, China.

Abstract:
The proper functioning of connected and autonomous vehicles (CAVs) is crucial for the safety and efficiency of future intelligent transport systems. Meanwhile, transitioning to fully autonomous driving requires a long period of mixed autonomy traffic, including both CAVs and human-driven vehicles. Thus, collaborative decision-making technology for CAVs is essential to generate appropriate driving behaviors to enhance the safety and efficiency of mixed autonomy traffic. In recent years, deep reinforcement learning (DRL) methods have become an efficient way in solving decision-making problems. However, with the development of computing technology, graph reinforcement learning (GRL) methods have gradually demonstrated the large potential to further improve the decision-making performance of CAVs, especially in the area of accurately representing the mutual effects of vehicles and modeling dynamic traffic environments. To facilitate the development of GRL-based methods for autonomous driving, this paper proposes a review of GRL-based methods for the decision-making technologies of CAVs. Firstly, a generic GRL framework is proposed in the beginning to gain an overall understanding of the decision-making technology. Then, the GRL-based decision-making technologies are reviewed from the perspective of the construction methods of mixed autonomy traffic, methods for graph representation of the driving environment, and related works about graph neural networks (GNN) and DRL in the field of decision-making for autonomous driving. Moreover, validation methods are summarized to provide an efficient way to verify the performance of decision-making methods. Finally, challenges and future research directions of GRL-based decision-making methods are summarized.
More Related Videos
Related Concept Videos
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:09
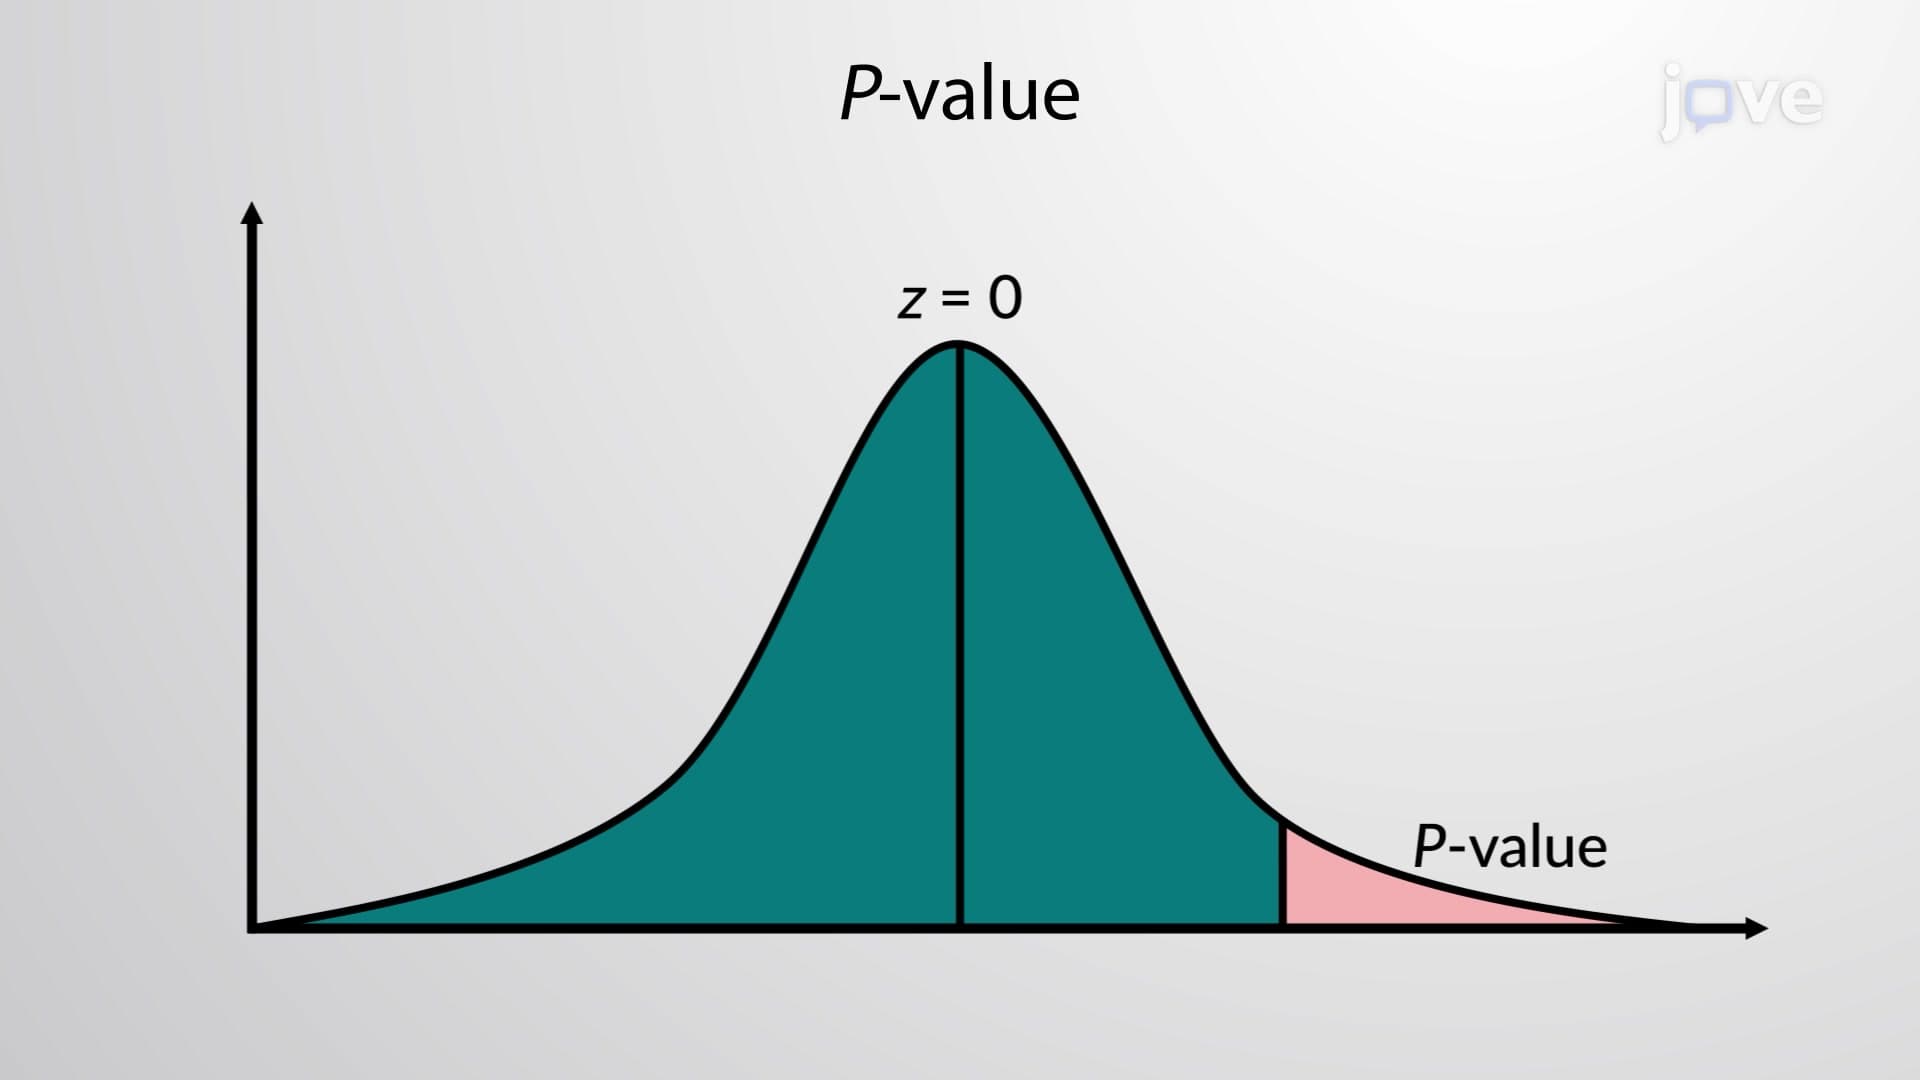
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:27
Associative Learning
Classical conditioning, also known...