Related Experiment Video
Updated: Jul 13, 2025
3D Imaging of PDL Collagen Fibers during Orthodontic Tooth Movement in Mandibular Murine Model
Published on: April 15, 2021
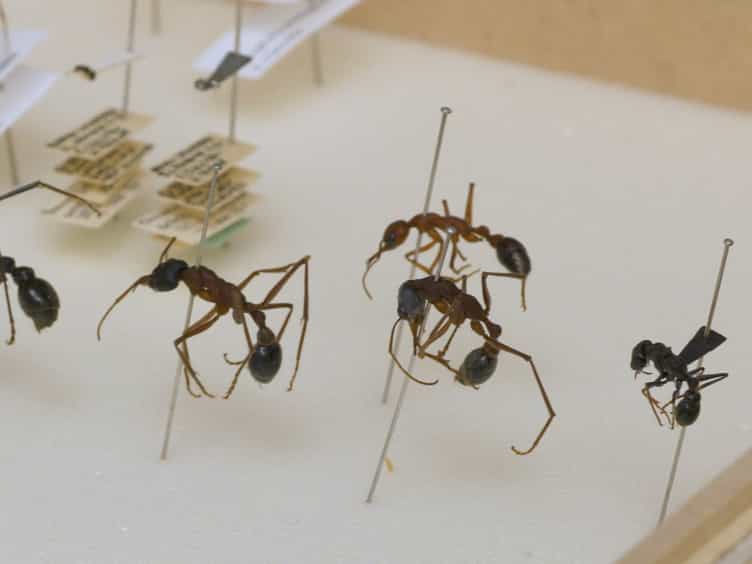
Three-dimensional kinematics of leaf-cutter ant mandibles: not all dicondylic joints are simple hinges
Victor Kang1, Frederik Püffel1, David Labonte1
1Department of Bioengineering, Imperial College London, London SW7 2AZ, UK.

Abstract:
Insects use their mandibles for a variety of tasks, including food processing, material transport, nest building, brood care, and fighting. Despite this functional diversity, mandible motion is typically thought to be constrained to rotation about a single fixed axis. Here, we conduct a direct quantitative test of this 'hinge joint hypothesis' in a species that uses its mandibles for a wide range of tasks: Atta vollenweideri leaf-cutter ants. Mandible movements from live restrained ants were reconstructed in three dimensions using a multi-camera rig. Rigid body kinematic analyses revealed strong evidence that mandible movement occupies a kinematic space that requires more than one rotational degree of freedom: at large opening angles, mandible motion is dominated by yaw. But at small opening angles, mandibles both yaw and pitch. The combination of yaw and pitch allows mandibles to 'criss-cross': either mandible can be on top when mandibles are closed. We observed criss-crossing in freely cutting ants, suggesting that it is functionally important. Combined with recent reports on the diversity of joint articulations in other insects, our results show that insect mandible kinematics are more diverse than traditionally assumed, and thus worthy of further detailed investigation. This article is part of the theme issue 'Food processing and nutritional assimilation in animals'.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:10
Relative Motion Analysis - Acceleration
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:30
Three-Dimensional Force System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...