Control Algorithm Design of a Force-Balance Accelerometer
Related Experiment Video
Updated: Jul 12, 2025
A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Zhiqiang Liu1, Lei Xia1, Bin Wu2
1Key Laboratory of Soft Machines and Smart Devices of Zhejiang Province, Department of Mechanics, Zhejiang University, Hangzhou 310027, China.

Abstract:
The force-balanced accelerometer (FBA), unlike other types of sensors, incorporates a closed-loop control. The efficacy of the system is contingent not solely on the hardware, but more critically on the formulation of the control algorithm. Conventional control strategies are usually designed for the purpose of response minimization of the sensitive elements, which limits the measurement accuracy and applicable frequency bandwidth of FBAs. In this paper, based on the model predictive control (MPC), a control algorithm of a force-balance accelerometer considering time delay is designed. The variable augmentation method is proposed to convert the force-balance control into an easy-handed measurement error minimization control problem. The discretization method is applied to deal with the time delay problem in the closed loop. The control algorithm is integrated into a practical FBA. The effectiveness of the proposed control is demonstrated through experiments conducted in an ultra-quiet chamber, as well as simulations. The results show that the closed loop in the FBA has a time delay 10 times of the control period, and, utilizing the proposed control, the acceleration signals can be accurately measured with a frequency range larger than 500 Hz. Meanwhile, the vibration response of the sensitive element of the controlled FBA is maintained at the level of microns, which guarantees a large measurement range of the FBA.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
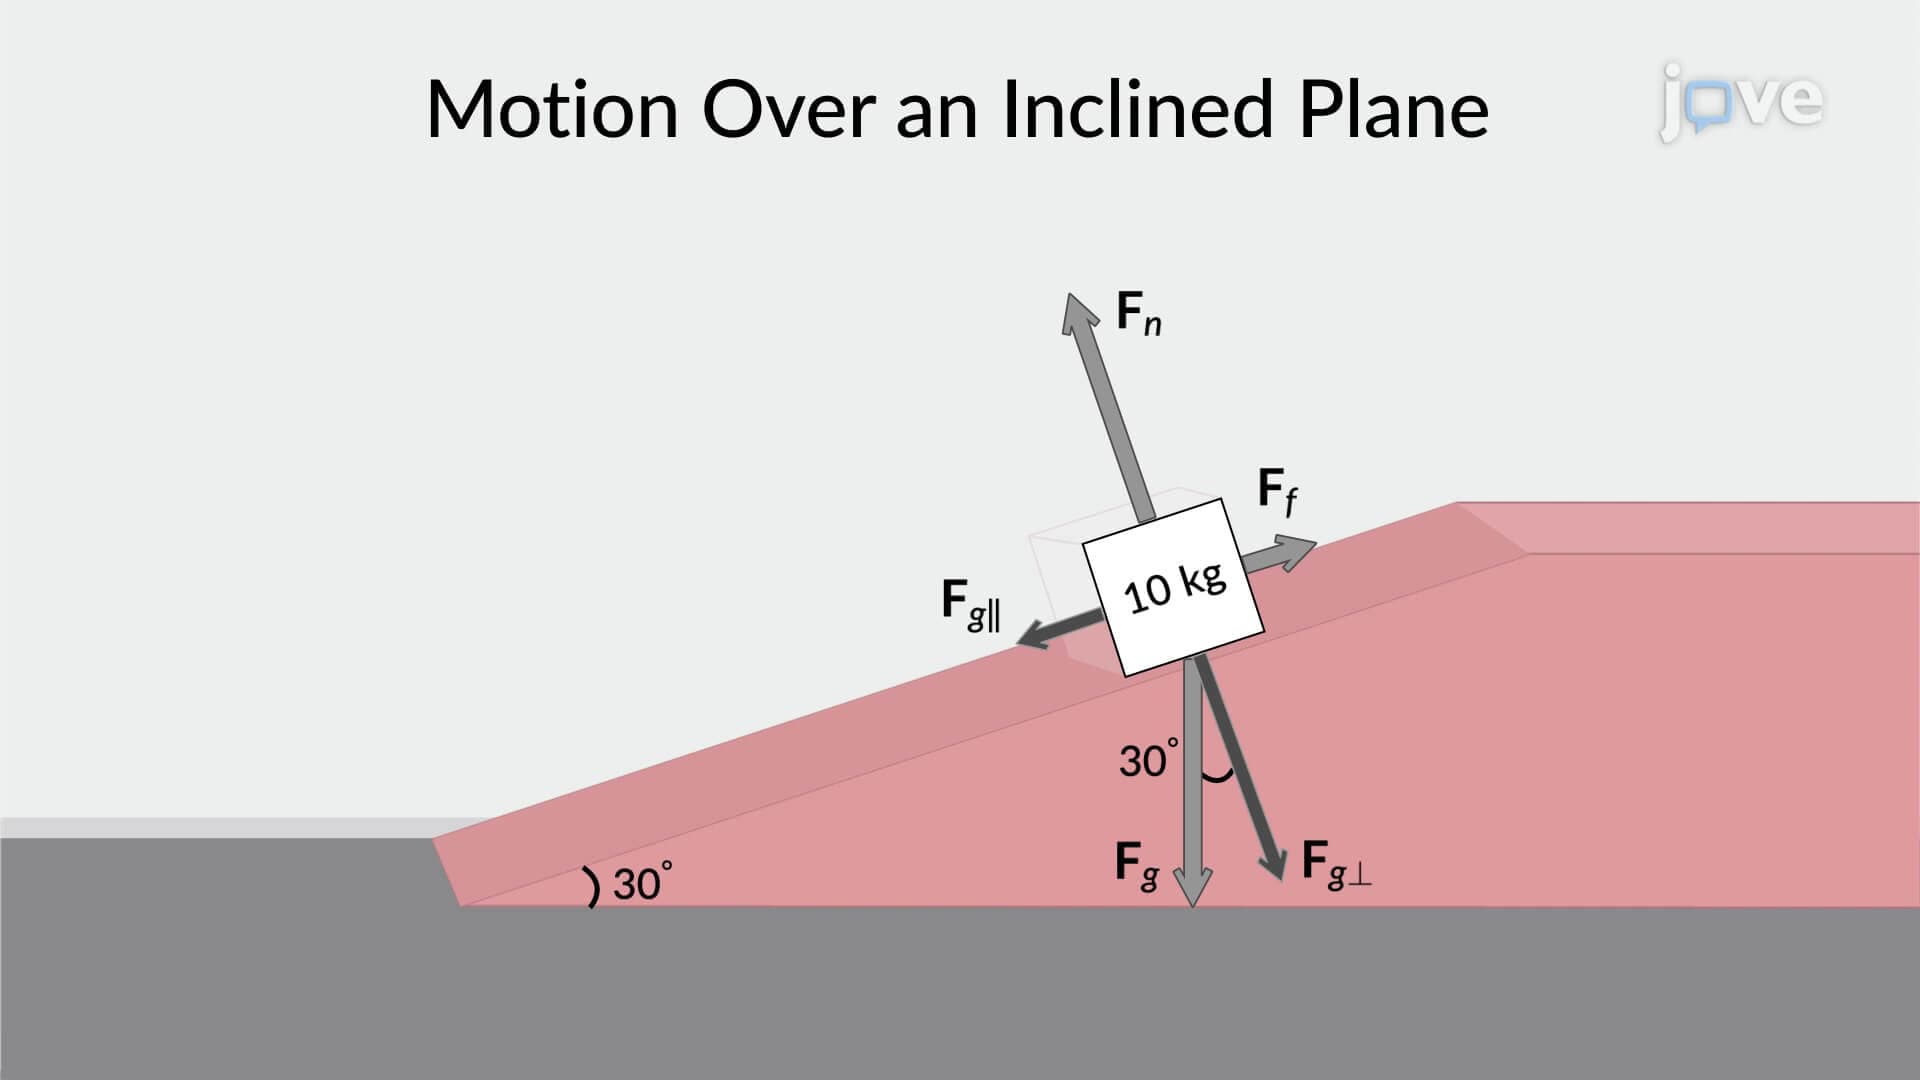
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:37
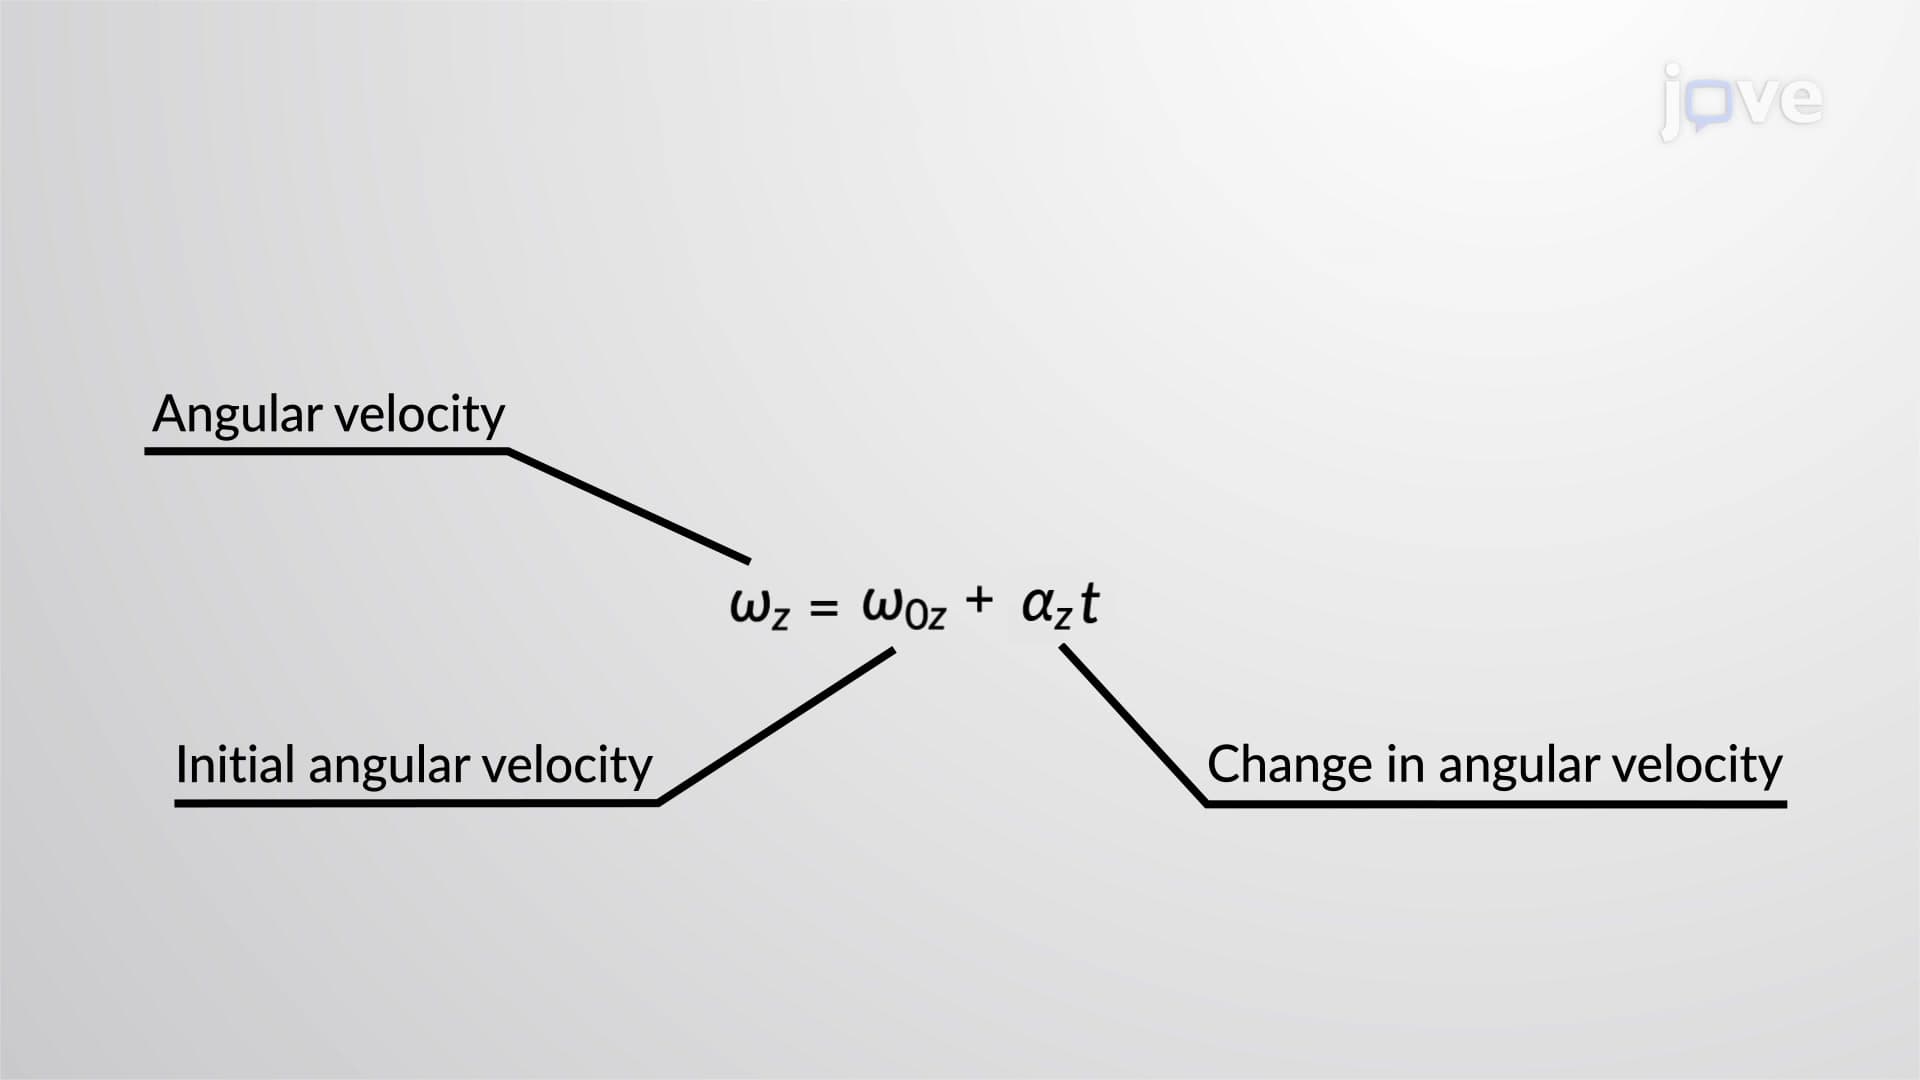
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...