Related Experiment Video
Updated: Jul 12, 2025
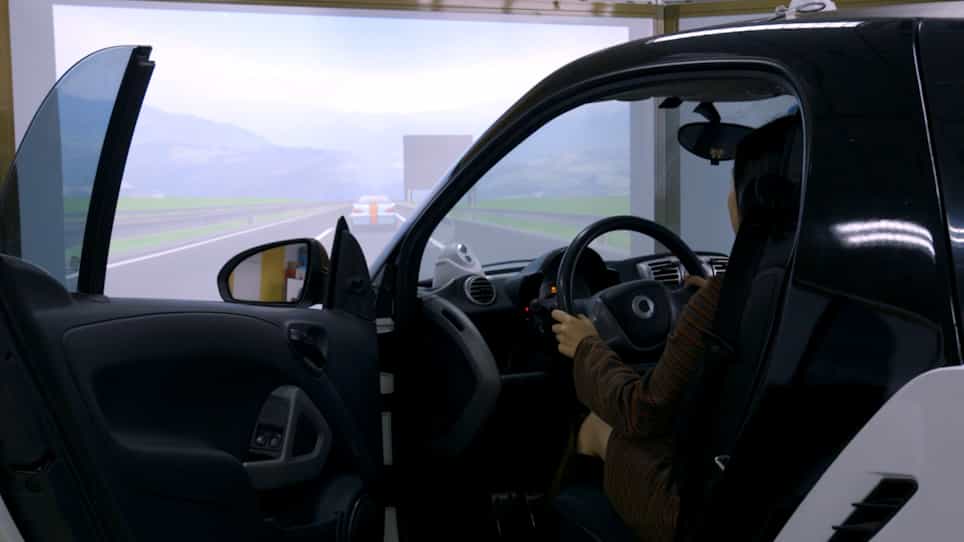
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A dynamic test scenario generation method for autonomous vehicles based on conditional generative adversarial
Lulu Jia1, Dezhen Yang1, Yi Ren1
1The School of Reliability and Systems Engineering, Beihang University, Beijing 100191, China.

Abstract:
Autonomous vehicles must be comprehensively evaluated before deployed in cities and highways. However, most existing evaluation approaches for autonomous vehicles are static and model environmental vehicles with predefined trajectories, which ignore the time-sequential interactions between the ego vehicle and environmental vehicles. In this paper, we propose a dynamic test scenario generation method to evaluate autonomous vehicles by modeling environmental vehicles as agents with human behavior and simulating the interaction process between the autonomous vehicle and environmental vehicles. Considering the multimodal features of traffic scenarios, we cluster the real-word traffic environments, and integrate the scenario class labels into the conditional generative adversarial imitation learning (CGAIL) model to generate different types of traffic scenarios. The proposed method is validated in a typical lane-change scenario that involves frequent interactions between ego vehicle and environmental vehicles. Results show that the proposed method further test autonomous vehicles' ability to cope with dynamic scenarios, and can be used to infer the weaknesses of the tested vehicles.
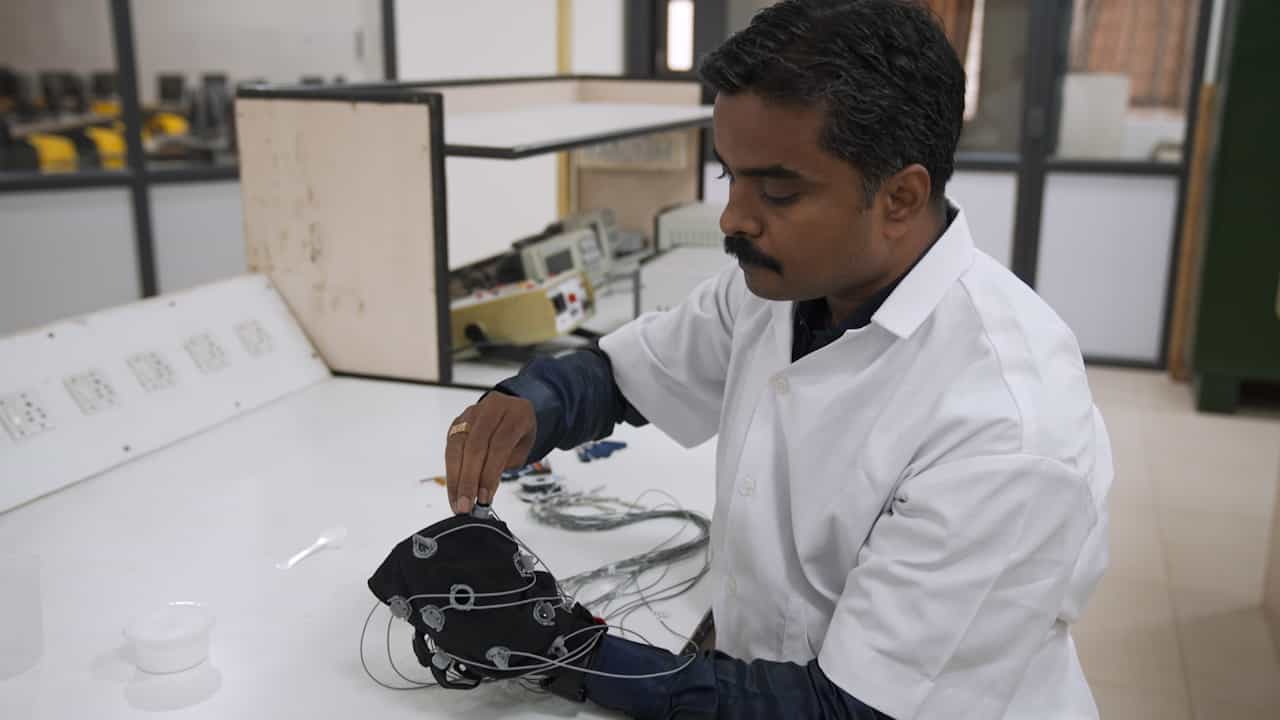

Related Concept Videos
 01:12
Observational Learning
 01:17
Rolling Resistance: Problem Solving
 01:16
Non-equilibrium in the Cell
 01:16
Statically Indeterminate Problem Solving
 01:13
Nonconscious Mimicry
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...